Explore drone components and find options for your aircraft.
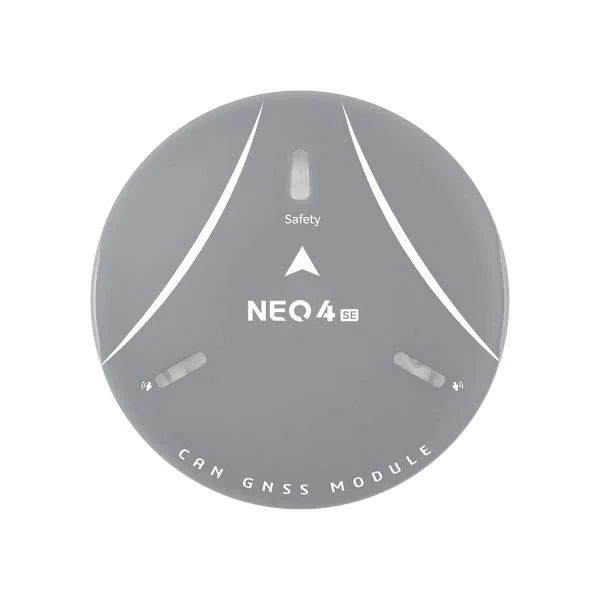
The CUAV NEO 4 SE is a compact GNSS CAN module for UAV positioning and compass integration. It combines a u-blox M10 receiver, STM32H5 processor, integrated antenna, electronic compass and status controls. DroneCAN connectivity supports ArduPilot and PX4 integration within a 60 × 60 × 16.1 mm, 33 g package.
The CUAV NEO 4 SE GNSS Module is a compact satellite navigation component integrating a u‑blox M10 receiver, STM32H5 processor, electronic compass and status controls. Its DroneCAN interface supports ArduPilot and PX4 integration. The 33 g module receives four GNSS concurrently, with update rates dependent on the selected GNSS configuration.
The CUAV Nora is a flight controller with connections for positioning, telemetry and motor or servo control.
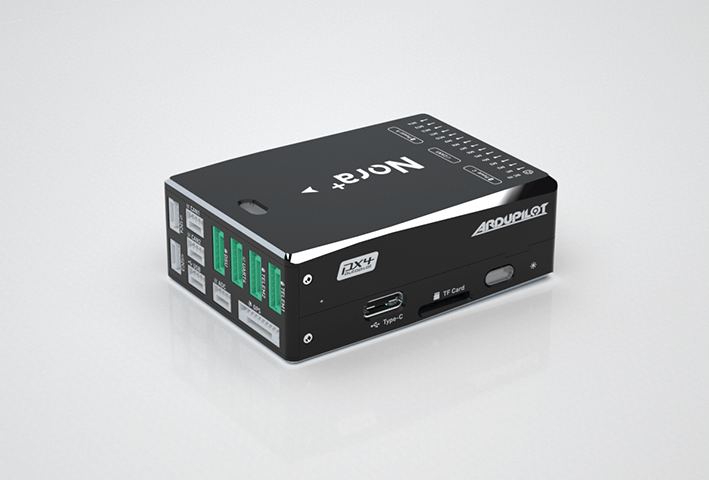
The CUAV Nora+ is a compact UAV flight controller for academic research and commercial systems integration. It combines STM32H7 processing, three IMU sensor sets, internal shock absorption and extensive control and peripheral interfaces. Controller power enters through Power A, Power C or USB; the PWM rail is electrically separate, and RCIN is restricted to receiver power.
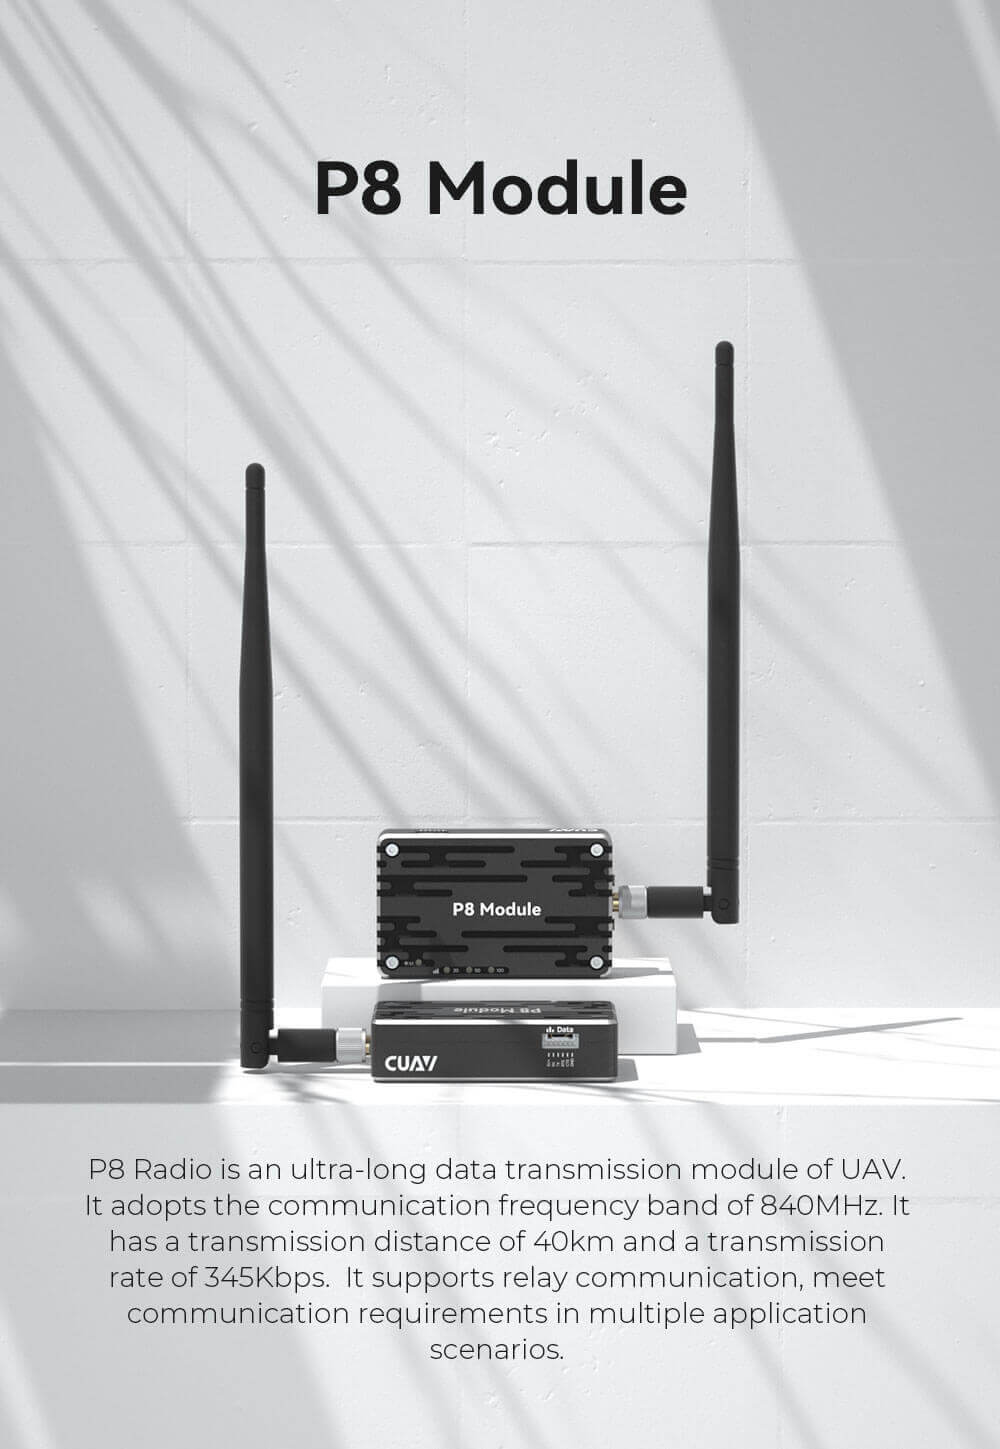
CUAV P8 Radio Telemetry is a compact data-link module for unmanned systems, offered as a radio set or individual air and ground units. It combines interchangeable terminal roles, TTL and USB connectivity, and an aluminum enclosure. Specifications distinguish a 40km limit distance from a 25km reference distance and list a maximum 345kbps over-air rate.
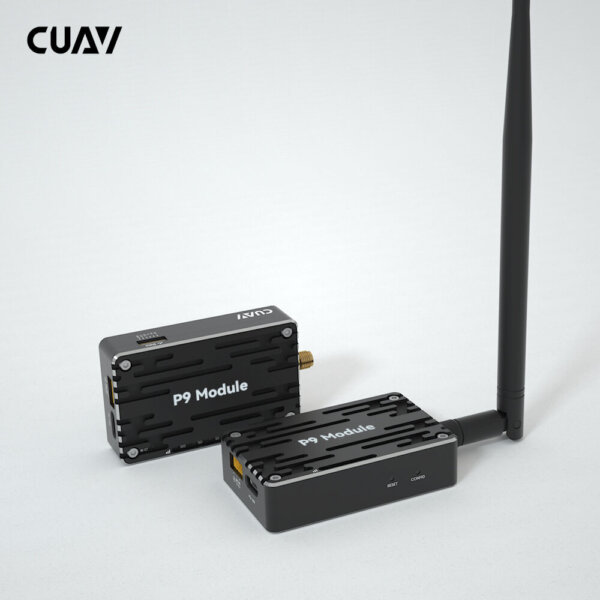
The CUAV P9 Radio Telemetry is an unmanned-system data-link module with switchable air and ground roles, point-to-point and relay networking, and a link rate up to 276kbps. Its reference range is 40km, subject to environment and configuration. An aluminum enclosure, serial and USB interfaces, and stated 3S–12S battery support define its integration.
The Pihack V3X is listed in CUAV’s controller family for civilian drone systems.
Pixhack is listed in CUAV’s controller family for civilian drone systems.
The CUAV Pixhack V3 is an open-source intelligent controller.
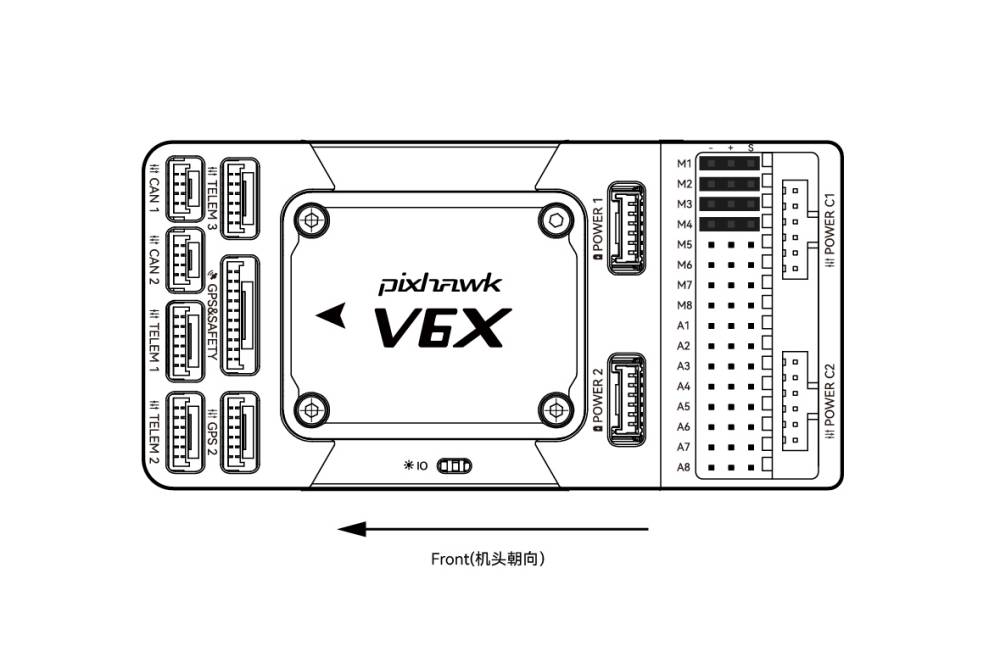
The CUAV Pixhawk V6X Flight Controller provides connections for navigation, telemetry, receivers, actuators and computers. Its wiring guide identifies a supplied power module and factory-installed logging card. Integration requires attention to mounting orientation, GPS placement, firmware-dependent power setup and external servo power, with differing power-module names requiring configuration confirmation.
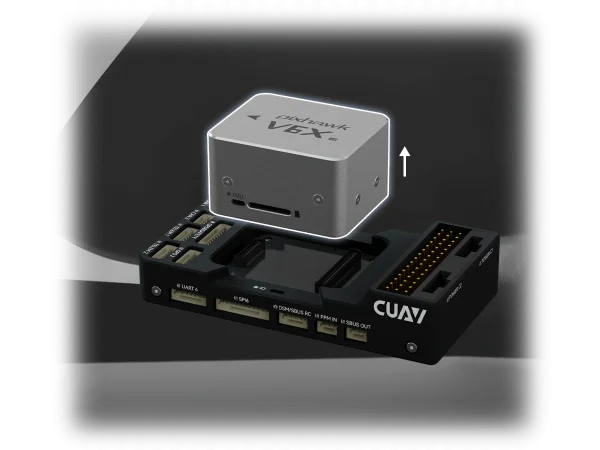
The CUAV Pixhawk V6X V2 is a modular UAV flight controller supporting ArduPilot and PX4. It combines a detachable controller core, triple-redundant inertial sensing, dual barometers and extensive peripheral interfaces. The standard configuration includes a PMU 2 Lite-5V power module, while custom carrier boards and PMU 2S expansion support additional integration requirements.
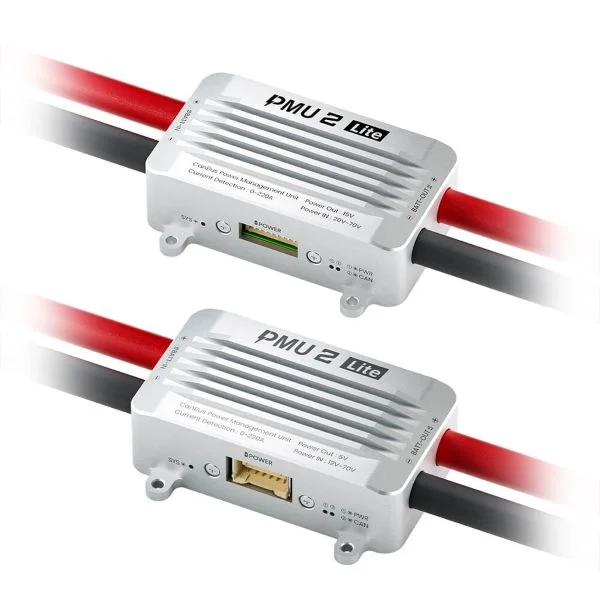
The CUAV PMU 2 Lite Power Manager Unit provides power delivery and voltage/current monitoring for unmanned systems through CAN. It combines non-contact current sensing, an aluminum alloy housing and factory calibration. Two output configurations offer different input ranges and connectors; continuous operation at 130A requires good heat dissipation.
 industry
 industry
 industry
 industry
 industry
 industry
 industry
 industry