Product overview
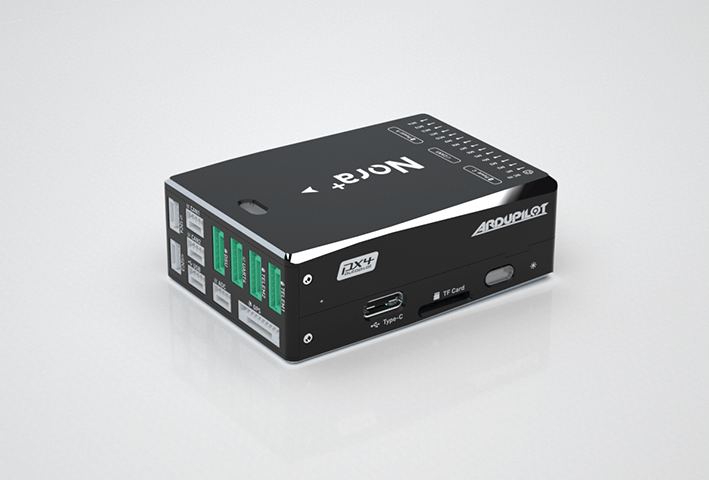
The CUAV Nora+ flight controller is independently designed by CUAV for academic research and commercial systems integration. It uses an STM32H743/STM32H753 FMU processor, with one ICM42688-P and two ICM20689 accelerometer/gyroscope sensor sets, an RM3100 magnetometer and two MS5611 barometers. Its integrated design features internal shock absorption and side-mounted ports, while the sensing system supports IMU heating and temperature compensation. Nora+ weighs 50 g, measures 46 × 64 × 22 mm and supports ArduPilot 4.10 and higher and PX4 V1.12.3 and higher.
For motor, servo and peripheral connections, Nora+ provides 14 PWM outputs, including 12 with DShot support. Receiver interfaces support SBUS, CPPM and DSM, alongside SBUS output and analogue/PWM RSSI input. Other connections comprise two GPS ports through GPS and UART4, four independent I2C interfaces, two CAN ports, two ADC inputs and two USB ports in Type C and GH 1.25 formats. Two of the I2C interfaces are integrated into the GPS and UART4 connections. Power A accepts a power module with analogue voltage and current detection and must not be connected to a digital power module; Power C provides a UAVCAN battery interface.
Nora+ must receive controller power through Power A, Power C or USB. During normal operation, the 4.5–5.4 V Power A and Power C inputs take priority over the 4.75–5.25 V USB input; three-source power redundancy requires all three sources to be supplied. The separate 0–10 V PWM output rail neither powers the controller nor receives power from it, so servos requiring power need an external supply. Nora+ monitors servo port voltage, with a maximum input of 10 V. RCIN is restricted to powering the RC receiver and must not connect to another power source or load. The operating temperature range is −20 to 85 °C.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity | CUAV Nora+ flight controller |
| Intended applications | Academic research and commercial systems integration |
| Firmware support | ArduPilot 4.10 and higher; PX4 V1.12.3 and higherArduPilot 4.10/PX4 V1.12.3 and higher firmware. |
| Main FMU processor | STM32H743/STM32H753 |
| Accelerometers and gyroscopes | One ICM42688-P and two ICM20689 accelerometer/gyroscope sensor setsNora+ configuration. |
| Magnetometer | RM3100 |
| Barometers | 2 × MS5611 |
| PWM and Dshot outputs | 14 PWM outputs; 12 support Dshot |
| RC inputs | SBUS, CPPM and DSM |
| SBUS output | SBUS output |
| RSSI input | Analogue/PWM RSSI input |
| GPS ports | 2 GPS ports: GPS and UART4 |
| I2C buses | 4 I2C buses with 4 independent interfacesTwo interfaces are integrated into the GPS and UART4 interfaces. |
| CAN ports | 2 CAN bus ports |
| Power ports | 2 power ports: Power A uses a common ADC interface; Power C uses a UAVCAN battery interface |
| ADC inputs | 2 ADC inputs |
| USB ports | 2 USB ports: Type C and GH 1.25 |
| Controller supply voltage | 4.5–5.4 VPower A and Power C inputs. |
| USB supply voltage | 4.75–5.25 VUSB input. |
| Servo rail voltage | 0–10 VServo rail input. |
| Weight | 50 g |
| Dimensions | 46 × 64 × 22 mm |
| Temperature range | −20 to 85 °COperating temperature. |
| IMU configuration and heating | 3 IMU sensor sets; IMU heating |
| Mechanical architecture | Internal shock absorption; side-mounted ports |
| Temperature compensation and integrated damping | Temperature compensation; integrated internal shock-absorption design |
| Servo voltage monitoring | Servo port voltage monitoring; maximum input 10 VServo port input must not exceed 10 V. |
| Power integration limitations and redundancy | RCIN may power only the RC receiver. PWM OUT (0–10 V) neither powers the controller nor receives power from it. Power A, Power C and USB support three-source power redundancy when all three sources are supplied.RCIN is restricted to receiver power. Controller power must enter through Power A, Power C or USB. Three-source redundancy requires three supplied power sources. |
| Power source priority | Power A and Power C inputs first; USB input secondNormal operation. |
| Debug interface and listed cable | DSU7 serial console and SWD interface; CUAV FTDI cable included in the product listSerial console and SWD operate through DSU7. |
| Design and processor | CUAV-designed controller with STM32H7 processor and industrial-grade sensorsNora+ |
| Intended use | Academic research and commercial systems integrationNora+ |
| Firmware and servo-port limits | ArduPilot 4.10/PX4 V1.12.3 and higher; servo-port input maximum 10VNora+ supports servo-port voltage monitoring. |
| RCIN restriction | Receiver power onlyDo not connect another power source or load. |
| Controller power | Power A, Power C or USB requiredPWM output rails do not power the board and are not powered by it. |
| Ethernet access | Serial-port connectionUsing PPP, a PPP-to-Ethernet adapter or a custom firmware build |
Request a quote for CUAV Nora+ flight controller
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.