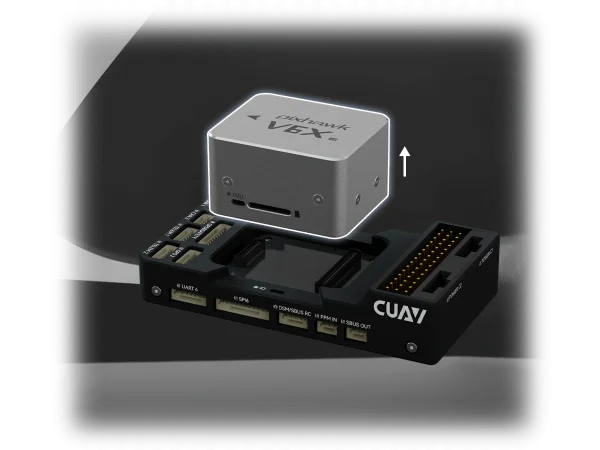
Product overview
The CUAV Pixhawk V6X V2 is a modular flight controller for integration into unmanned systems, with support for ArduPilot and PX4 firmware. Its STM32H753IIK6 processor combines a 480 MHz double-precision floating-point unit with 2M Flash memory and supports secure boot and secure firmware updates. The hardware incorporates three different inertial sensor types, an RM3100 compass and two barometers. Independent IMU buses and power supplies support switching after a single-point failure, while a constant-temperature external clock supports sensor timing and synchronization.
The controller measures 45 × 85.1 × 29.2 mm and weighs 97.9g. Its detachable core contains the controller and all IMUs, allowing integration with custom carrier boards. A shock-absorption assembly uses resilient materials and four tilted, five-axis-CNC-processed supports to address vibration across three axes. Peripheral integration includes 16 PWM I/O, two GPS ports, three telemetry ports, two CAN buses and external sensor expansion. Software-selectable 5V or 3.3V PWM outputs and 100 Mbps Ethernet provide additional electrical and data-interface options.
The supplied power configuration includes a factory-precalibrated PMU 2 Lite-5V module with a 12 ~ 70 V input range and 220A current detection. The controller supports two CAN PMU inputs; expansion with a PMU 2S raises the supported input to up to 140V and current detection to 600A. Those higher limits require the expansion module. Controller power input is specified at 4.85 ~ 5.45 V, USB at 4.75 ~ 5.25 V, and operating temperature at -20 ~ 85 °C.
Specifications
| Specification | Value & conditions |
|---|---|
| PX4 compatibility | V1.17.0 and abovePixhawk V6X v2 |
| ArduPilot release status | Beta firmware requiredPixhawk V6X v2, according to the supplied ArduPilot guide |
| Model | Pixhawk V6X V2Controller |
| Processor and firmware | STM32H753IIK6; ArduPilot and PX4 supportController processor and supported firmware functions |
| IMU redundancy | Independent buses and power supplies with fault switchingSwitching after a single-point fault |
| Modular integration | Removable controller and IMU core; user-designed carrier boardsCarrier boards can be designed to user requirements |
| Standard power module | PMU 2 Lite-5V; 12–70 V inputInput range applies to the included power module |
| Network hardware | Ethernet MACPixhawk V6X v2; marked ETH |
| Network framework | LAN and WAN connectionsArduPilot 4.5 and later |
| Processor | STM32H753IIK6 |
| Version | Pixhawk V6X V2 |
| Accelerometer & Gyroscope | IIM-42652; BMI088; ICM-45686 |
| Electronic Compass | RM3100 |
| Barometer | BMP581; ICP-20100 |
| PWM I/O | 16 |
| Power | 2 [2 CAN power interfaces] |
| GPS Port | 2 [1 GPS interface with I2C and safety switch (GPS1), 1 interface with I2C and GPS (GPS2)] |
| TELEM Port | 3 |
| CAN Bus | 2 |
| PPM RC | 1 dedicated input for PPM receiver |
| SBUS/DSM/RSSI | 2 [1 SBUS/DSM/Spektrum input, 1 analog (3.3V)/PWM input] |
| SBUS outs | 1 |
| FMU Debug | 1 |
| IO Debug | 1 |
| Ethernet | 1 |
| SPI External 1 | 1 [SP16 interface for external sensor expansion] |
| ADIO | 1 [AD3.3/ADC6.6] |
| UART4 | 1 |
| USB Port | 2 [1 Type-C interface, 1 GH interface for USB external connection] |
| TF Card | 1 |
| Power Module | Standard PMU 2 Lite-5V version (Input Voltage: 12 ~ 70 V)Standard supplied power module. |
| Operating Voltage |
|
| Operating Temperature | -20 ~ 85 °C |
| Size | 45 × 85.1 × 29.2 mm |
| Weight |
|
| Processor Resources | 480 MHz double-precision floating-point unit; 2M Flash memory |
| PWM Output Levels | 5V / 3.3VPWM output level selected through software. |
| Ethernet Data Rate | 100 Mbps |
| Power Monitoring and Expansion | Standard PMU 2 Lite: 70V input and 220A current detection, factory pre-calibrated; PMU 2S expansion: up to 140V input and 600A current detectionPMU 2 Lite supplied as standard; higher limits require expansion with a PMU 2S. |
Request a quote for CUAV Pixhawk V6X v2 Flight Controller
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.