Product overview
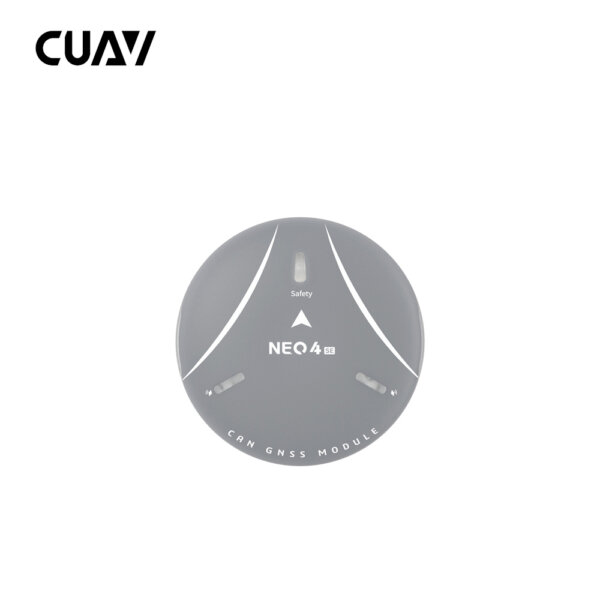
The CUAV NEO 4 SE GNSS Module provides satellite navigation and electronic compass functions for integration with a flight controller. Its architecture combines a u‑blox MIA‑M10Q receiver, a 250 MHz STM32H5 Arm Cortex‑M33 processor and CUAV M4C GNSS firmware. The reception hardware incorporates a TCXO, dual LNA architecture and an active receiving antenna with RF filtering. An integrated ST IIS2MDC compass adds temperature offset compensation and a magnetic field dynamic range of up to ±50 Gs.
The 60 × 60 × 16.1 mm module weighs 33 g, defining the physical space and mass needed for installation. It communicates through DroneCAN using a GHR‑04V‑S data interface and supports the ArduPilot and PX4 protocol stacks. Installation must provide a 4.7–5.2 V input supply and keep operation within −10 °C to +80 °C. Integrated equipment includes a physical safety button, passive buzzer and RGB status lighting. Offered configurations comprise a two-module option or a module paired with either a Pixhawk V6X V2 or 7-Nano V2 controller.
Navigation supports BeiDou, Galileo, GLONASS and GPS/QZSS, with four GNSS received concurrently. Update rate depends on configuration: up to 10 Hz with four concurrent GNSS or up to 25 Hz with a single GNSS; the default rate is 5 Hz. Horizontal position accuracy is 1.5 m CEP, and speed accuracy is 0.05 m/s. Acquisition takes 27 seconds for a cold start and one second for a hot or aided start. Firmware upgrades are supported, while the supplied hardware remains a navigation module for controller integration.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity and purpose | CUAV NEO 4 SE GNSS Module; standard-size satellite navigation receiver module. |
| Receiver type | U‑blox MIA‑M10Q |
| Processor | STM32H5 Arm Cortex‑M33, 250 MHz |
| Concurrent GNSS | Four concurrent GNSS: BeiDou, Galileo, GLONASS, GPS/QZSS. |
| Frequency bands |
|
| Oscillator | TCXO |
| Cold-start acquisition | 27 sCold start. |
| Hot-start acquisition | 1 sHot start. |
| Aided-start acquisition | 1 sAided start. |
| Navigation update rate with concurrent GNSS | Up to 10 HzFour concurrent GNSS. |
| Navigation update rate with single GNSS | Up to 25 HzSingle GNSS. |
| Default navigation update rate | 5 Hz defaultDefault setting. |
| Horizontal position accuracy | 1.5 m CEPCEP. |
| Speed accuracy | 0.05 m/s |
| Communication protocol | DroneCAN |
| Firmware upgrade support | Supported |
| Firmware | CUAV M4C GNSS |
| Data interface | GHR‑04V‑S |
| Module dimensions | 60 × 60 × 16.1 mm |
| Module weight | 33 g |
| Input voltage | 4.7–5.2 V |
| Operating temperature | −10 °C to +80 °C |
| RGB driver | MCU direct drive |
| Buzzer | Passive buzzer |
| Safety switch | Physical button |
| Electronic compass | Built-in ST IIS2MDC electronic compass |
| Compass magnetic field range and compensation | Magnetic field dynamic range up to ±50 Gs; temperature offset compensation. |
| Reception architecture | TCXO, dual LNA architecture and active receiving antenna with RF filtering. |
| Platform integration | DroneCAN compatibility with ArduPilot and PX4 protocol stacks.ArduPilot and PX4 protocol stacks. |
| Offered configurations | Two NEO 4 SE GPS modules; NEO 4 SE with Pixhawk V6X V2 Controller; or NEO 4 SE with 7-Nano V2 Controller.Selected product option. |
Request a quote for CUAV NEO 4 SE GNSS Module
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.