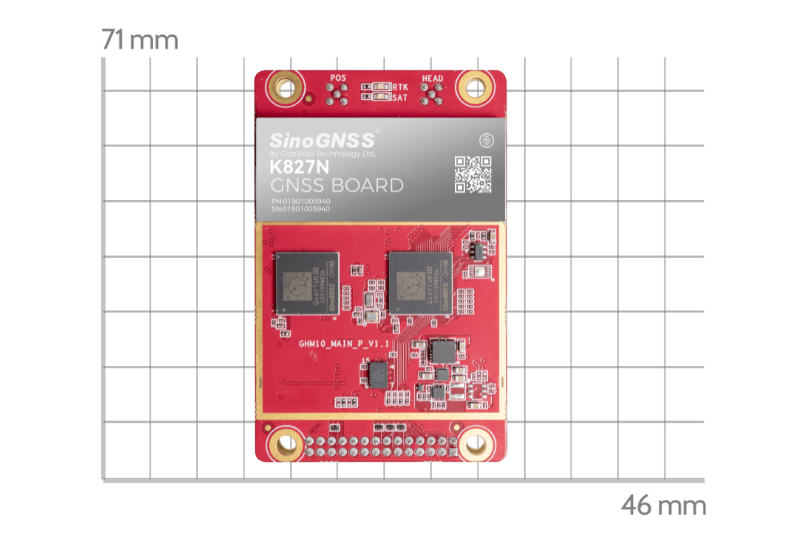
| Product and applications | ComNav K827N GNSS Module; GNSS board for land surveying, autonomous driving, precision agriculture, machine control, robotics and UAVs; centimeter-accuracy positioning and high-precision heading in static and dynamic environments. |
|---|
| Dual-Resolving RTK | Two processors independently compute RTK using observations from the primary and secondary antennas.Observations from primary and secondary antennas. |
|---|
| Integrated IMU | Integrated GNSS and IMU; maintains centimeter-level positioning for 3s and meter-level positioning for 10s during GNSS signal loss.During GNSS signal loss. |
|---|
| Board compatibility and CAN | CAN protocol support; standard I/O and pin definitions with physical and data-format compatibility for mainstream GNSS boards using standard 20-pin to 28-pin connections. |
|---|
| Positioning signals | GPS: L1C/A, L1C, L2P, L2C, L5; BDS-2: B1, B2I, B3I; BDS-3: B1I, B3I, B1C, B2a, B2b; GLONASS: G1, G2, G3; Galileo: E1, E5b, E5a, E5 AltBoC, E6c; QZSS: L1C/A, L2C, L5, L1C; SBAS: L1C/A; NavIC: L5, S Band; L-Band.Positioning. |
|---|
| Heading and secondary positioning signals | - GPS: L1C/A, L1C, L2P, L2C, L5;
- BDS-2: B1, B2I, B3I;
- BDS-3: B1I, B3I, B1C, B2a, B2b;
- GLONASS: G1, G2, G3;
- Galileo: E1, E5b, E5a, E5 AltBoC, E6c;
- QZSS: L1C/A, L2C, L5, L1C.
Heading and Positioning 2. |
|---|
| Cold start | Less than 20sWith Acceleration Capture Module added. |
|---|
| Hot start | Less than 10sWith RTC; typical. |
|---|
| Reacquisition | Less than 1s |
|---|
| RTK initialization | Initialization time: less than 5s with baseline less than 10km; initialization reliability: greater than 99.9 %.Baseline less than 10km for RTK initialization time. |
|---|
| Velocity accuracy | ≤ 0.02 m/sPDOP ≤4. |
|---|
| Acceleration and overload | Acceleration: 4 g; overload: 15g. |
|---|
| Time accuracy | 20ns |
|---|
| Attitude | Azimuth: 0.15°/R; roll or pitch: 0.25°/R. |
|---|
| Post-processing positioning | Horizontal: 2.5 mm + 1 ppm; vertical: 5 mm + 1 ppm.Post processing. |
|---|
| RTK positioning | Horizontal: 8 mm + 1 ppm; vertical: 15 mm + 1 ppm.Single Baseline RTK. |
|---|
| Other positioning modes | - DGPS: less than 0.4 m RMS;
- SBAS: 1 m 3D RMS;
- standalone: 1.5m 3D RMS.
DGPS, SBAS or standalone positioning, respectively. |
|---|
| Dimensions and weight | 46mm×71mm×10mm (L × W × H); 15.0 g. |
|---|
| Hardware interface | 2 x 14 pin |
|---|
| Power consumption | 1.8 W with anti-interference off; enabling anti-interference consumes about 0.2W more.1.8 W with anti-interference off; about 0.2W additional consumption with anti-interference on. |
|---|
| Temperature ranges | Operating: -40 °C to + 85 °C; storage: -55 °C to + 95 °C.Operating and storage temperatures, respectively. |
|---|
| LNA power | +3.3V ~ +5V ± 5%VDC @ 0-100mALNA power. |
|---|
| LNA gain | 20 ~ 35dBExternal LNA. |
|---|
| Impedance matching | 50 Ohm |
|---|
| Communication ports | 3 LVTTL ports; 2 SPI. |
|---|
| Event marker and PPS connections | 2 event marker inputs; 1 Pulse Per Second (PPS) output. |
|---|
| Status indicator pins | 3 working-status indicator pins. |
|---|
| Correction data input/output | RTCM 2.X, 3.X; CMR (GPS only); CMR+ (GPS only).CMR and CMR+ support GPS only. |
|---|
| Position data formats | ASCII: NMEA-0183 GGA, GSA, GSV, RMC, HDT, VHD, ZDA, VTG, GST, GLL; PTNL, PJK; PTNL, AVR; PTNL, GGK. ComNav Binary. BINEX: 0x00, 0x01-01, 0x01-02, 0x01-05, 0x7d-00, 0x7e-00, 0x7f-05. |
|---|
| Position data output rates | 1 Hz, 2 Hz, 5 Hz, 10 Hz, 20Hz (optional), 50Hz.20Hz is optional. |
|---|