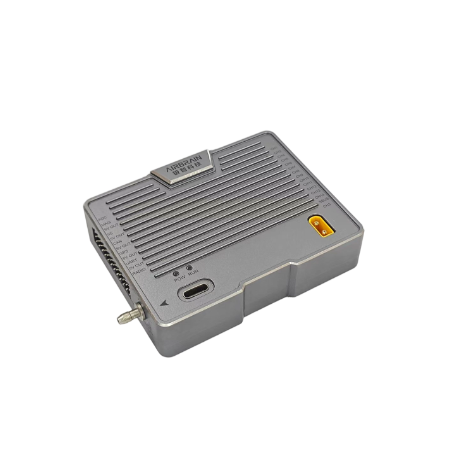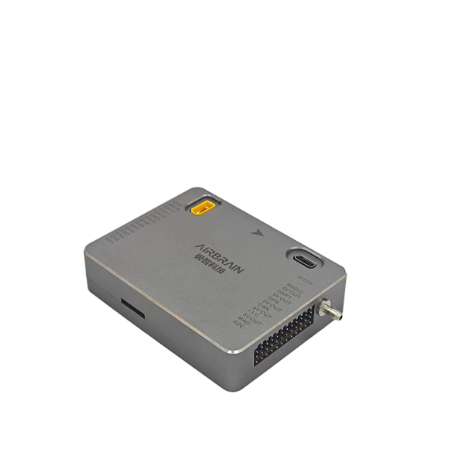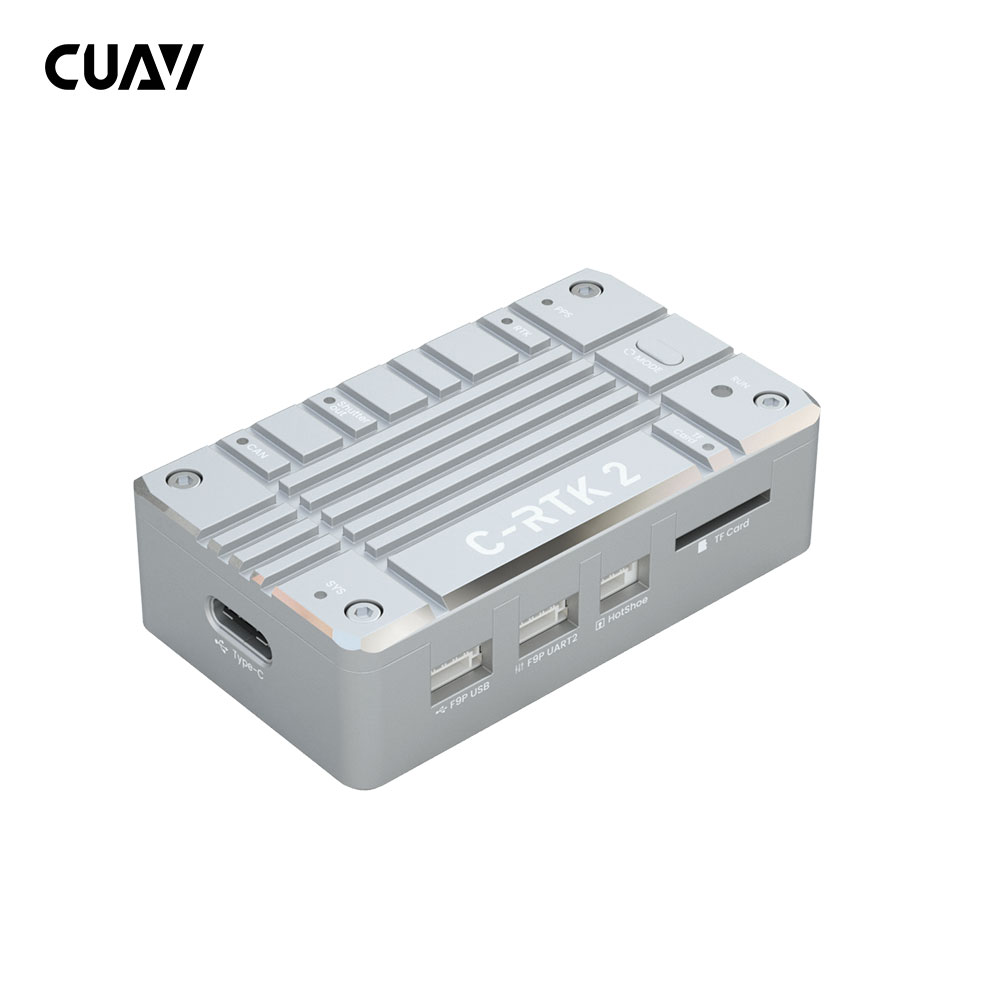
Product overview
The CUAV C-RTK 2 PPK Module is a positioning component for drone aerial surveying and mapping, designed for multirotors, VTOL aircraft and helicopters. It supports real-time kinematic positioning while simultaneously recording raw data for post-processed kinematic workflows. Its hardware combines a 184-channel ZED-F9P receiver, an STM32H743VIH6 processor, an RM3100 magnetometer and an ICP10111 barometer. The receiver supports multiple frequencies and concurrent reception from four GNSS constellations: GPS, GLONASS, Galileo and BeiDou.
RTK updates reach up to 20 Hz, while raw-data updates reach up to 25 Hz; the default update rate is 5 Hz. Specified RTK position accuracy, expressed as RMS, is 0.01 m + 1 ppm horizontally and 0.02 m + 1 ppm vertically, with RTK convergence specified at less than 10 seconds. GPS horizontal accuracy is specified as 1.5 m RMS. The module supports base-station and rover modes, along with TF card expansion to a maximum of 32G for recording.
C-RTK 2 supports UAVCAN/DroneCAN and flight controllers running ArduPilot or PX4 firmware, with plug-and-play operation specified for X7 series flight controllers. Camera connections comprise one hotshoe interface, one shutter input and one shutter output. Additional connections include F9P USB, F9P UART and an MMCX antenna connector, alongside support for high-speed USB and USB mass-storage mode. The module measures 56 × 33 × 16.5 mm, weighs 39 g, requires a 4.5–6 V supply and operates from −20 to 85 °C.
Specifications
| Specification | Value & conditions |
|---|---|
| Positioning and recording | Simultaneous RTK and raw-data recording for PPKC-RTK 2 module |
| Flight controller compatibility | ArduPilot/PX4Plug-and-play operation is specified with X7 series flight controllers |
| RTK receiver | ZED-F9P; 184 receiving channels |
| Main processor | STM32H743VIH6; 2M flash, 1M RAM |
| Onboard sensors | Industrial-grade IMU |
| Magnetometer and barometer | RM3100 magnetometer; ICP10111 barometer |
| TF card capacity | 32G maximum |
| Positioning modes | RTK positioning and simultaneous raw data recording for PPK |
| GNSS bands |
|
| Augmentation signals | QZSS: L1C/A, L2C, L1S; SBAS: L1C/A |
| Concurrent GNSS constellations | 4: GPS, GLONASS, Galileo, BeiDou |
| Update rates |
|
| Convergence time | Less than 10 secRTK |
| RTK position accuracy | Horizontal: 0.01 m + 1 ppm; vertical: 0.02 m + 1 ppmRMS; RTK positioning |
| GPS position accuracy | 1.5 mRMS; GPS positioning; horizontal |
| Acquisition times |
|
| Receiver sensitivity |
|
| Anti-spoofing | Advanced anti-spoofing algorithms |
| GNSS protocols | NMEA; UBX binary; RTCM 3.x |
| Time pulse frequency | 0.25 Hz–10 MHzConfigurable |
| Anti-jamming | Active CW detection and removal; onboard band-pass filter |
| CAN protocols | UAVCAN; DroneCAN |
| Flight controller support | CompatibleFlight controllers running ArduPilot/PX4 firmware |
| USB modes | HS_USB; USB mass storage mode |
| Camera interfaces | 1 hotshoe; 1 shutter input; 1 shutter output |
| USB, serial and antenna interfaces | 1 Type (HS_USB); 1 F9P USB; 1 F9P UART; 1 MMCX antenna connector |
| Supply voltage | 4.5–6 V |
| Operating temperature | −20–85 °C |
| Dimensions | 56 × 33 × 16.5 mm |
| Weight | 39 g |
| Operating modes | Base station; rover |
| Mode switching | Press and hold the button for 3 seconds to switch modesNot connected to a computer |
| PPK processing | RTKPOST processing with base-station observationsBase-station observations saved in RINEX format require no format conversion. |
| Base-station supply | Purchased separatelyWhen using a dedicated PPK base station. |
| Observation recording | Continuous static recording during flightThe PPK base station must remain in static acquisition mode throughout the aircraft's flight. |
| Combined PPK and RTK operation | CORS/NTRIP base-station service recommendedUse a data link to establish communication between the ground station and aircraft. |
| Configuration changes | Edit the configuration file stored on the TF cardConnect the module to a computer, save the edited file and restart the device for changes to take effect. |
| Firmware maintenance | System and F9P receiver firmware updates are documentedFollow the separate update procedures for the module system and receiver. |
| Camera integration | POS recording with PWM camera triggeringRequires configuration for PWM shutter control. |
| Navigation integration | RTK and navigation data through UAVCANEnable UAVCAN for flight-controller navigation; this step is unnecessary for PPK-only use. |
Request a quote for CUAV C-RTK 2 PPK Module
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.