Product overview
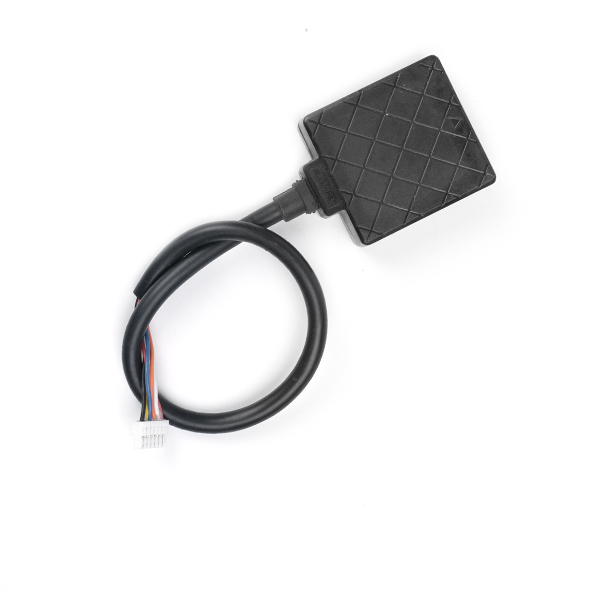
The BWSENSING BW-MINS100 provides inertial sensing for unmanned aircraft and other mobile or stabilized equipment. Its packaged architecture combines gyroscope and accelerometer functions within a 60 × 59 × 29 mm envelope, giving integrators a defined space requirement for installation. It is an instrumentation component for integration into a host system. Intended uses also include unmanned boats, underwater vehicles, robotics, platform stabilization, large vessels, automated guided vehicles and special-purpose vehicles.
Electrical integration requires a 9–36V DC supply, with RS232, RS485 or TTL available as selectable output interfaces. The system incorporates Kalman filtering, dedicated bias tracking and temperature compensation across −40℃ to +85℃. Attitude specifications distinguish 1° dynamic accuracy from 0.01° static accuracy, with pitch coverage of ±90º and roll coverage of ±180º. Heading retention is specified as 0.5°/60s, while accelerometer bias-stability figures depend on the stated temperature, observation interval and statistical qualification.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity and type | BWSENSING BW-MINS100 micro inertial navigation system |
| Packaged dimensions | L60 × W59 × H29 mm |
| Dynamic attitude accuracy | 1° |
| Static attitude accuracy | 0.01° |
| Attitude measurement range | Pitch ±90º; roll ±180º |
| Heading retention accuracy | 0.5°/60s |
| Gyroscope resolution | 0.01°/sec |
| Gyroscope bias stability | 30°/hFull temperature range; 10s, 1σ. |
| Angular random walk coefficient | Less than 0.1 °/√h |
| Accelerometer range | ±1.8 gX, Y and Z axes. |
| Accelerometer bias stability at 100 seconds | 0.001mg25℃, 100s, 1σ. |
| Accelerometer bias stability at 10 seconds | 0.01mg25℃, 10s, 1σ. |
| Power supply | 9–36V DC |
| Interface options | RS232, RS485 or TTLSelectable output interface. |
| Temperature range | -40℃ to +85℃Temperature compensated. |
| Bias tracking | Dedicated bias-tracking algorithm for drift elimination |
| Filtering | Kalman filtering algorithm |
| Intended applications | Unmanned boats, underwater vehicles, robots, platform stabilization, large vessels, automated guided vehicles, automated and driverless operation, special-purpose vehicles, and unmanned aircraft |
Request a quote for BW-MINS100
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.