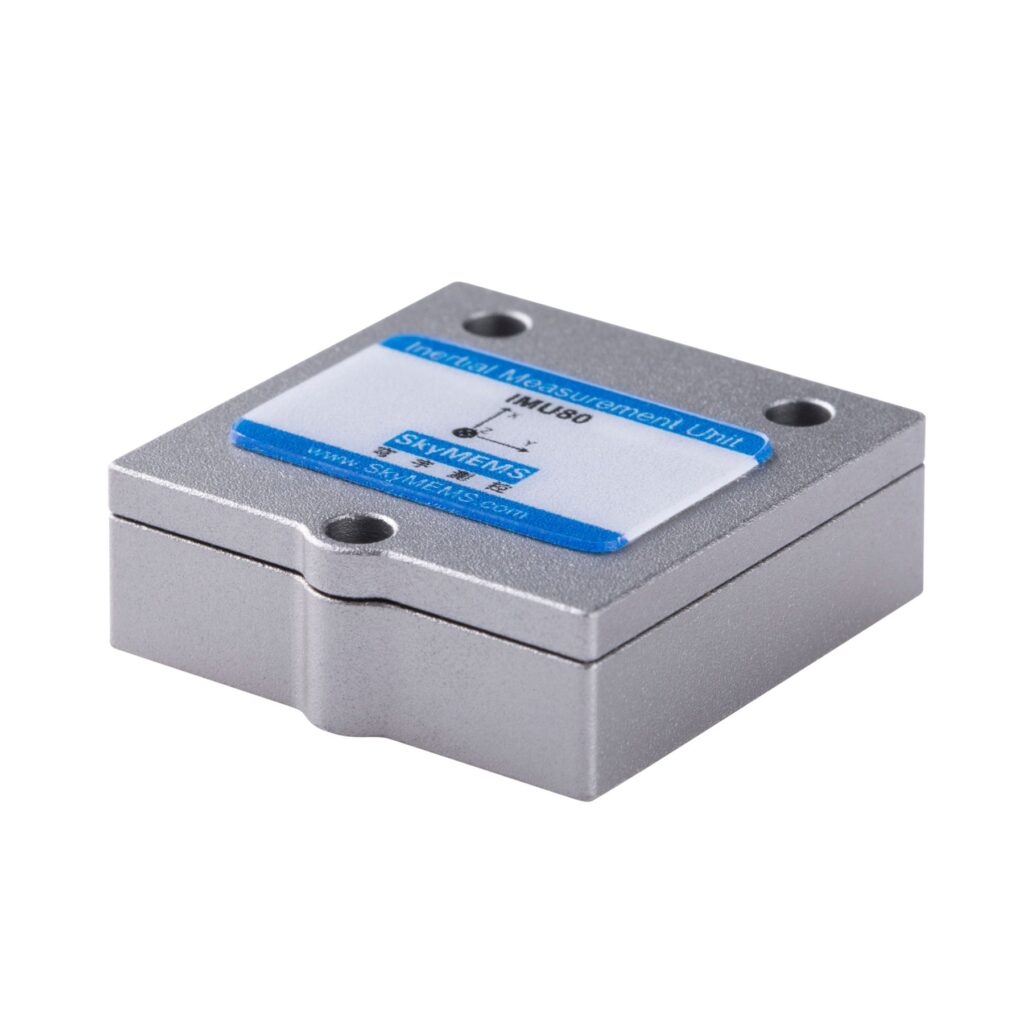
| Product | SkyMEMS IMU80 6DoF Mini IMU |
|---|
| Construction and processing | MEMS-based inertial sensors, extended Kalman filter algorithm and compact aluminum housing |
|---|
| Measurement outputs | Yaw, pitch, roll and six-axis angular rate and acceleration |
|---|
| Applications | Dynamic control and attitude systems for AGVs, smart agriculture, unmanned aircraft, ROVs, robotics, machine control and platform stabilization |
|---|
| Measurement ranges | Gyroscope: ±400°/s; accelerometer: ±8gTypical ranges; gyroscope and accelerometer ranges can be configured at the factory. |
|---|
| Bias instability | Gyroscope minimum/typical/maximum: 2 / 3 / 4 °/h; accelerometer minimum/typical/maximum: 40 / 50 / 60 ugAllan variance. |
|---|
| Initial bias error | Gyroscope minimum/typical/maximum: 0.05 / 0.08 / 0.1 °/s; accelerometer minimum/typical/maximum: 3 / 4 / 5 mg |
|---|
| Random walk | Gyroscope minimum/typical/maximum: 0.1 / 0.2 / 0.3 °/√h; accelerometer minimum/typical/maximum: 0.03 / 0.05 / 0.07 m/s/√h |
|---|
| Scale factor accuracy | Gyroscope and accelerometer: 0.1 % |
|---|
| Non-linearity | Gyroscope and accelerometer: 0.01 %FSFull scale (FS). |
|---|
| Resolution | Gyroscope: 0.01 °/s; accelerometer: 0.1 mg |
|---|
| Bandwidth | Gyroscope and accelerometer: 50 Hz |
|---|
| UART communication | Baud rate: 115200 bps; output rate: 200 HzUART interface. |
|---|
| SPI communication | Serial clock frequency: 10 MHz; output rate: 2000 HzSPI interface. |
|---|
| Supply voltage | 3.3 V |
|---|
| Power consumption | Less than 0.1 W |
|---|
| Temperature range | -40°C ~ 85°COperating. |
|---|
| Storage temperature | -55°C ~ 100°CStorage. |
|---|
| Dimensions | 23.3 × 22.4 × 7.5 mm |
|---|
| Weight | Less than 15 grams |
|---|
| Connector | 7×2 pins; matching SAMTEC CLM-107-02 socket |
|---|
| Calibration and encapsulation | Glue encapsulation and full calibration |
|---|
| G-sensitivity | 0.1 dps/g |
|---|
| Shock resistance | 2000gShock duration less than 1ms; powered or unpowered. |
|---|
| Sampling frequency | 1KhzRaw inertial measurements. |
|---|
| Raw output limitation | Direct 1k frequency raw data output is not supported; raw data requires processingDirect raw data output. |
|---|
| Output frequency with fusion disabled | 400Hz achieved; 500Hz theoretically possibleFusion algorithm turned off; 500Hz is theoretical. |
|---|
| Internal filter | Third-order low-pass filter with configurable cutoff frequencyCutoff frequency configured through IMU80 management software. |
|---|
| Temperature test conditions | -40 to 85 °; one hour at both -40° and 85°; actual temperature may exceed 85 ° during high-temperature testingTemperature test; one-hour dwell at each endpoint. |
|---|
| Recalibration | MEMS sensor performance may change slightly after 10 months or a year; factory recalibration is available for high-accuracy requirementsAfter 10 months or a year; applications requiring high accuracy. |
|---|