Product overview
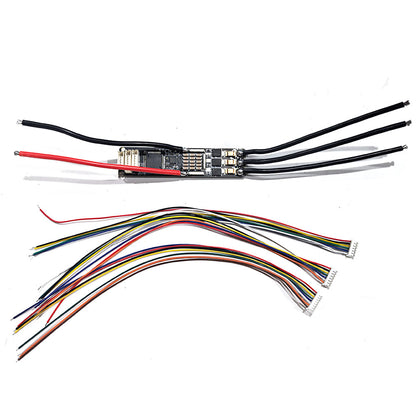
The Maytech MTSPF6.0M is a miniature motor speed controller for integration into drones, RC aircraft, robotic arms and other compact motorized equipment. Its V6.0-based hardware occupies 79*18.5*7.5 (mm) and weighs 22g per unit, providing a small installation envelope for equipment with limited space. Continuous current is 30A and burst current is 50A. It supports sensored and sensorless brushless motors as well as brushed motors, with square-wave and FOC control modes.
Integration uses PWM, analog-voltage, UART or USB speed signals, with ABI, Hall, AS5047 and other encoders supported. VESCTOOL provides the software interface, firmware is updatable, and version 7.0 is the default and recommended firmware. Factory firmware enables UART by default; UART wiring is recommended to use stranded conductors no longer than 0.5m. Cable and cable-free configurations are offered. A 6S lithium battery paired with an MTO2830 Hall-sensored brushless motor is the recommended matching configuration.
Battery limits are inconsistent: the table specifies 3-12S LiPo (12-50.4V), the descriptive specification states Max 50V (12S LiPo), and the function overview states up to 10S. Protection covers over-current, over-temperature and over-voltage. Switching power supplies are prohibited because connection transients can damage the controller. Recommended electrical speeds are 30000-40000 ERPM in FOC and 50000-60000 ERPM in BLDC. Controller arrays require CAN L/CAN H connections only, without interconnected GND or 5V pins; shared-receiver Y-PPM wiring risks permanent damage.
Specifications
| Specification | Value & conditions |
|---|---|
| Manufacturer and model | Maytech MTSPF6.0M |
| Product type | Miniature motor speed controller / SUPERFOC ESC |
| Continuous current | 30A |
| Burst current | 50A |
| Input voltage | 3-12S Lipo (12-50.4V) in the table; Max 50V (12S Lipo) in the descriptive specification; up to 10S in the function overview3-12S Lipo (12-50.4V); the descriptive specification gives Max 50V (12S Lipo), while the function overview states up to 10S. |
| Input voltage table and function-overview limits | Table: 3-12S Lipo (12-50.4V) |
| Function-overview battery limit | Up to 10S lithium battery |
| Hardware | Based on V6.0 |
| Firmware | Updatable |
| Default and recommended firmware | 7.0 |
| Software | VESCTOOL Compatible |
| FOC | Yes, can work |
| Size | 79*18.5*7.5 (mm) |
| Net weight | 22g/pcs |
| Compatible motor | Sensored / Sensorless Motor |
| Motor types and control modes | Sensored and sensorless brushless motors and brushed motors; square wave and FOC modes |
| Supported sensors | ABI, Hall, AS5047 and other encoders |
| Application | Robot arm, lab testing |
| Aircraft applications | Drones, RC drones and RC airplanes |
| Speed signal inputs | PWM, analog voltage, UART and USB |
| Default communication configuration | UART enabled by defaultFactory firmware. |
| Cable configuration options | With cable or without cable |
| Protection functions | Over-current, over-temperature and over-voltage protection |
| Battery and motor pairing | 6S lithium battery plus MTO2830 Hall-sensored brushless motorRecommended matching configuration. |
| Array wiring restriction | Do not share one receiver through Y-PPM wiring; connect only CAN L and CAN H between controllers, without GND or 5V connectionsV6/V75-based SUPERFOC ESC or VESC arrays. |
| Power supply restriction | Do not use a switching power supply; connection voltage transients can damage the controller |
| Recommended FOC electrical speed | 30000-40000 ERPMFOC mode. |
| Recommended BLDC electrical speed | 50000-60000 ERPM; exceeding the recommendation risks driver IC damageBLDC mode. |
| UART wiring recommendation | Prefer stranded wire no longer than 0.5m, or shorterUART connection. |
| Commissioning requirement | Check computer connectivity without load and with the motor disconnected before connecting the motorInitial connection check. |