ChinaDroneRequest a quote →
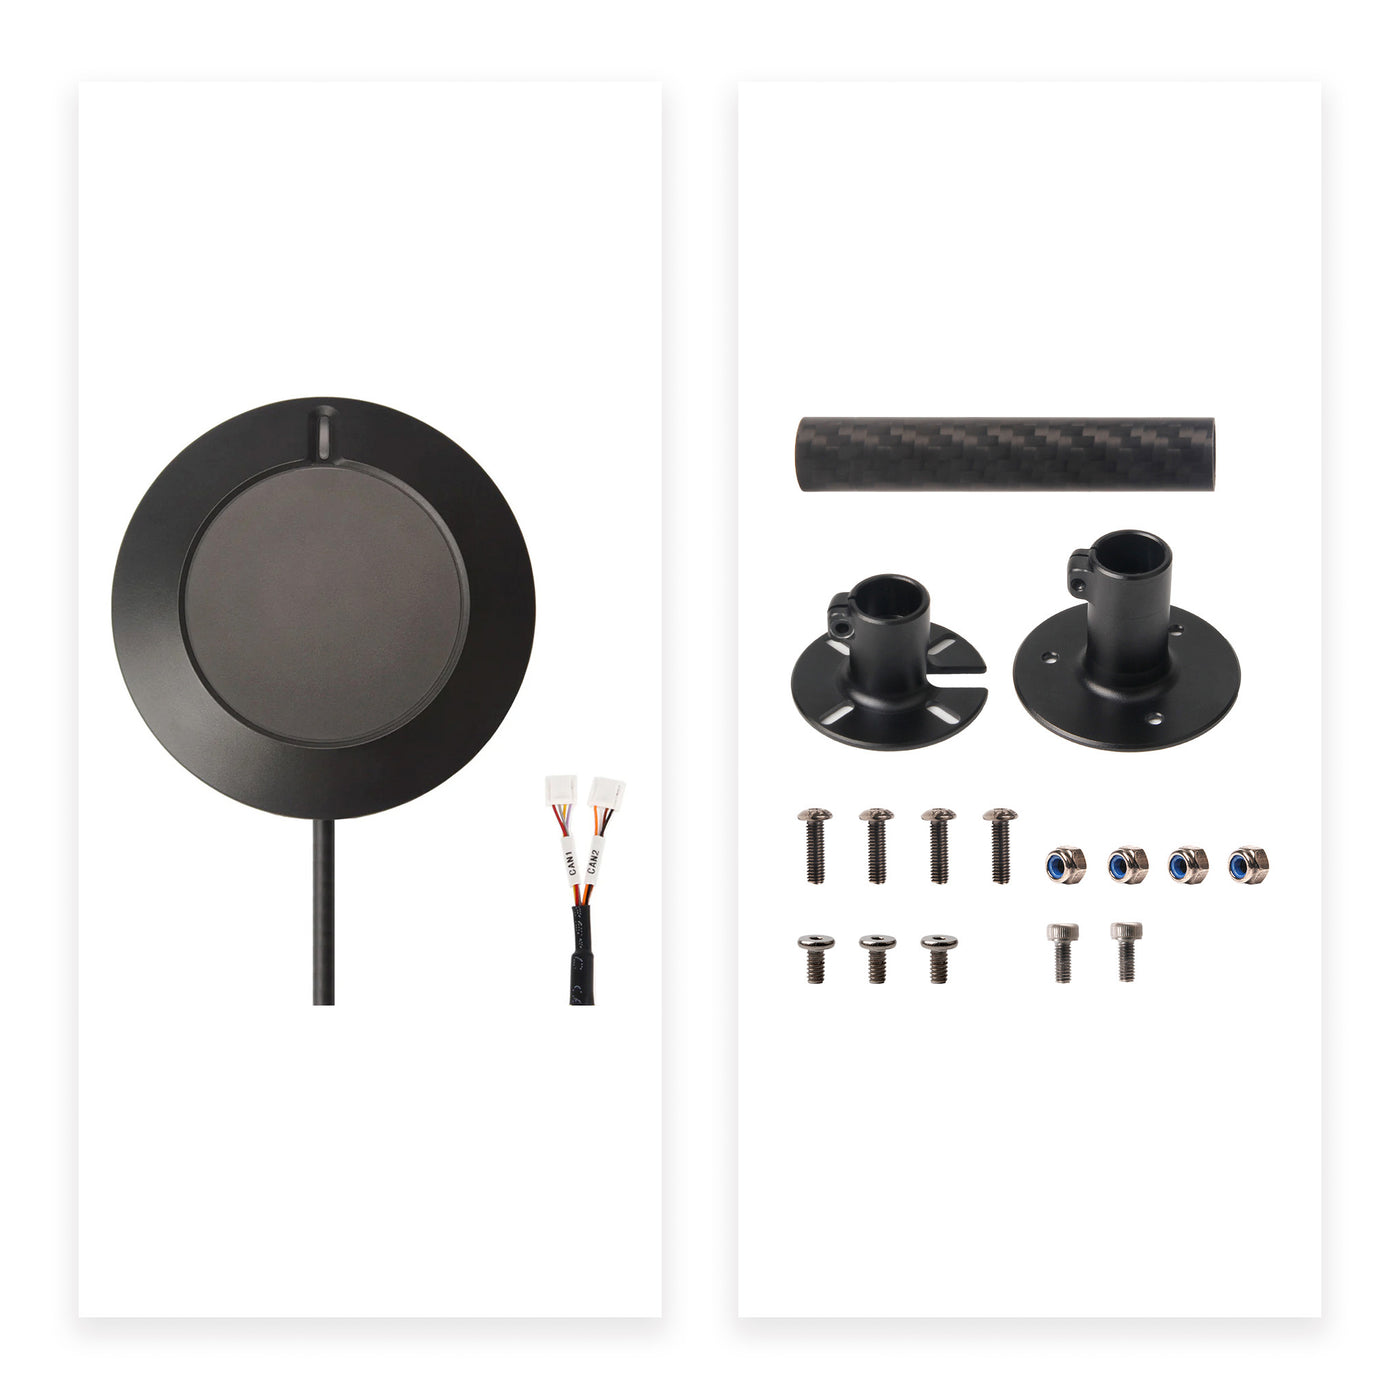
Holybro H-RTK ZED-F9P Rover DroneCAN 4-Pin module with cable and mounting hardwareHolybro H-RTK ZED-F9P Rover DroneCAN 4-Pin module with cable and mounting hardware

Holybro H-RTK ZED-F9P Rover (IP66, RM3100 Compass)

The Holybro H-RTK ZED-F9P Rover (IP66, RM3100 Compass) is a positioning peripheral for UAVs and other moving platforms. It combines multi-band RTK GNSS, an RM3100 compass and an integrated antenna. Three UART or DroneCAN configurations provide specific controller connections; the package includes a fixed carbon-fiber GPS mount.

HolybroDrone GPS
Positioning accuracy
0.01m +1ppm CEP.
Weight
117g.
Dimensions
Diameter: 78 mm; height: 22 mm.
Ingress protection
IP66-rated protection against dust and water.

Get a free quote

Product overview

The Holybro H-RTK ZED-F9P Rover (IP66, RM3100 Compass) supplies positioning and orientation data for moving aircraft, ground vehicles and marine vehicles. It combines a u-blox ZED-F9P GNSS receiver, RM3100 compass and tri-colored LED indicator with an integrated dual-band stacked ceramic patch antenna. Signal processing includes triple SAW filtering, an LNA and double hybrid coupler. Its IP66 housing measures 78mm in diameter and 22mm high, with a weight of 117g. Flat-surface and elevated mounting are supported, and a fixed carbon-fiber GPS mount is supplied.

Three configurations provide distinct integration connections: SKU12054 uses a GH1.25 10-pin UART cable for Holybro GPS1, SKU12058 uses a GH1.25 6-pin UART cable for Holybro or Cubepilot GPS2, and SKU12059 uses a GH1.25 4-pin DroneCAN cable for a Pixhawk CAN port. The DroneCAN configuration adds an STM32G4 MCU, ICM42688 IMU and ICP20100 barometer, with software-selectable CAN termination resistance. The supplied cable is 40cm long. Both UART configurations include a GPS UART to USB converter. Working voltage is 4.75V~5.25V, current consumption is approximately 250mA, and working temperature spans -40 °C to +85 °C.

The receiver supports four concurrent GNSS systems, with listed signal bands for GPS, GLONASS, Galileo, BeiDou and QZSS. Horizontal and vertical RTK positioning accuracy is 0.01m +1ppm CEP, while heading accuracy is 0.4 degrees. Maximum output rates depend on mode: RAW reaches 20Hz, RTK reaches 8Hz and moving-base RTK reaches 5Hz. Acquisition times are 2s for hot and aided starts and 25s for cold starts. Integration options include NMEA, UBX binary and RTCM 3.3 protocols, plus a configurable timepulse from 0.25hz to 10mhz.
Flight control & navigation

Specifications

SpecificationValue & conditions
ProductHolybro H-RTK ZED-F9P Rover (IP66, RM3100 Compass)
Configurations, connectors, ports and communication
  • SKU12054: GH1.25 10pin cable, Holybro GPS1 Port, UART;
  • SKU12058: GH1.25 6pin cable, Holybro or Cubepilot GPS2 Port, UART;
  • SKU12059: GH1.25 4pin cable, Pixhawk CAN Port, DroneCAN.
MCU, IMU and barometerSTM32G4 MCU, ICM42688 IMU and ICP20100 barometer.DroneCAN configuration; N/A for both UART configurations.
Compass and applicationHigh-precision, low-noise RM3100 compass; moving-station applications including aircraft, ground vehicles and marine vehicles.
GNSS receiverU-blox ZED-F9P high-precision GNSS receiver.
GNSS bands and concurrent reception
  • GPS: L1C/A and L2C;
  • GLONASS: L1OF and L2OF;
  • Galileo: E1-B/C and E5b;
  • BeiDou: B1I and B2I;
  • QZSS: L1C/A and L2C. Concurrent GNSS: 4.
Heading accuracy0.4 degrees.
Positioning accuracy0.01m +1ppm CEP.RTK; horizontal and vertical positioning.
Antenna and LNA gainDual-band stacked ceramic patch antenna, 47.5*47.5*4mm; LNA gain: 20.5±1dB typical.
Maximum antenna peak gainL1: 4.0dBi; L2: 1.0 dBi.
Acquisition times
  • Hot start: 2s;
  • aided starts: 2s;
  • cold starts: 25s.
Maximum data and update rates
  • RAW: 20Hz Max;
  • RTK: 8Hz Max;
  • moving-base RTK: 5Hz Max.
Receiver sensitivity
  • Tracking and navigation: –167 dBm;
  • cold starts: –148 dBm;
  • hot starts: –157 dBm;
  • reacquisition: –160 dBm.
TimepulseConfigurable from 0.25hz to 10mhz.
ProtocolsNMEA, UBX binary and RTCM 3.3.
Filtering and amplificationTriple SAW + LNA filtering and signal amplification; double hybrid coupler for signal coupling.
Anti-jamming and anti-spoofingActive CW detection and removal, onboard band-pass filter and advanced anti-spoofing algorithms.
Cable length40cm.
Baud rate and default update rateBaud rate: 115200; update rate: 5Hz by default, configurable.
Working temperature-40 °C to +85 °C.
Working voltage4.75V~5.25V.
Current consumption~250mA.
DimensionsDiameter: 78mm; height: 22mm.
Ingress protectionIP66-rated protection against dust and water.
Weight117g.
Mounting optionsFlat-surface or elevated mounting.
CAN terminationSoftware toggle for CAN termination resistance.DroneCAN configuration.
Package contents1x H-RTK ZED-F9P Rover; 1x fixed carbon-fiber GPS mount; 1x GPS UART to USB converter for SKU12054 and SKU12058.GPS UART to USB converter supplied for SKU12054 and SKU12058.
Setup guidesSetup and getting-started guides for ArduPilot and PX4.

Related guides