Product overview
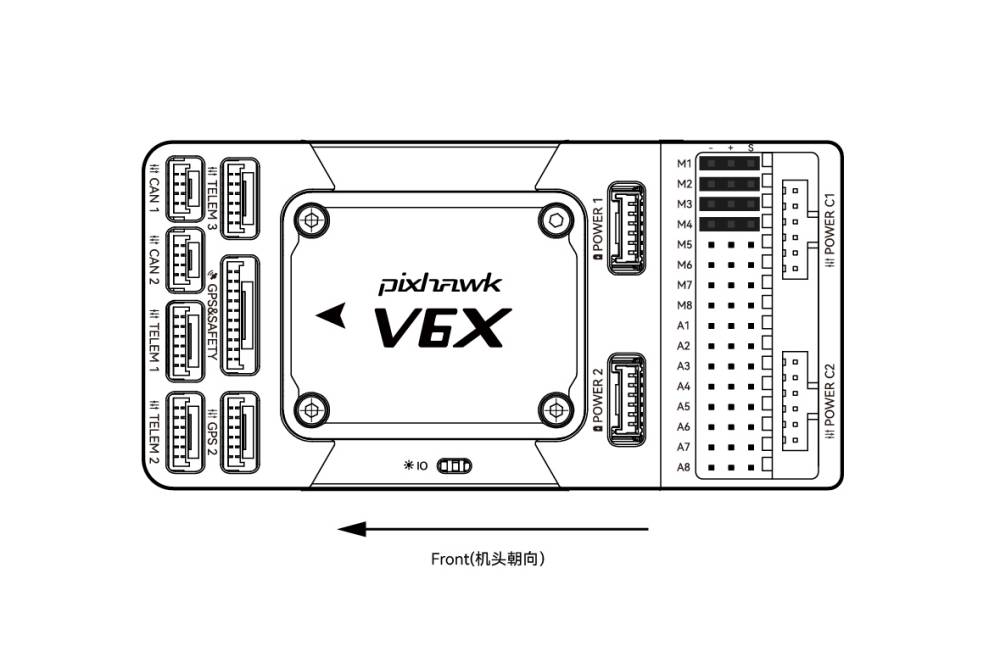
The CUAV X7 is a flight controller covered by a shared X7/X7+ wiring guide. Its interface overview identifies connections for navigation sensors, telemetry systems, remote control receivers, and motor or servo outputs. GPS&SAFETY connects Neo series GPS or C-RTK 9P, while UART 4 can connect a second GPS. CAN1/CAN2 connect DroneCAN devices such as CAN GPS. M1–M14 provide PWM outputs for motors or servos, and M1–M12 also support DShot. The guide introduces its detailed peripheral wiring instructions for X7+, so its ground-station monitoring and control guidance should not be treated as an explicit X7 capability statement.
If the X7 cannot be mounted in the recommended or default orientation, its software orientation must be configured to match the actual installation. The shared interface overview specifies POWER A for a power module with analog voltage and current detection and prohibits connecting a digital power module there. POWER C is designated for CAN PMU SE. USB Type-C provides computer communication, including firmware loading; I2C1, I2C2 and I2C4 connect devices such as an external compass. RC IN includes DSM, SBUS and RSSI signal inputs, with connections for DSM satellite and SBUS remote control receivers.
Specifications
| Specification | Value & conditions |
|---|---|
| Installation orientation | Software configuration required for a nondefault mounting orientationWhen the controller cannot be mounted in the recommended or default orientation |
Request a quote for CUAV X7 flight controller
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.