Product overview
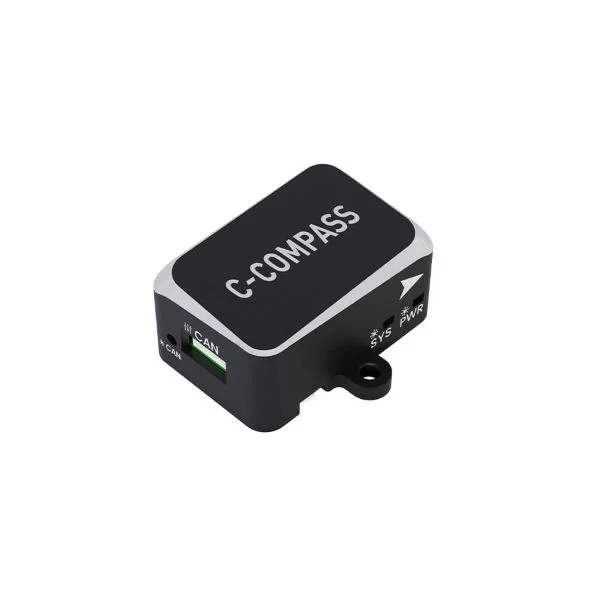
The CUAV C-Compass CAN Electronic Compass provides external heading sensing for unmanned systems using ArduPilot or PX4. Its hardware combines an STM32F4 processor with an RM3100 magnetic sensor inside an aluminum-alloy casing weighing 13g. CUAV’s M4C software architecture supports customized development, while DroneCAN handles communication with the controller. Magnetic filtering addresses interference from onboard cables, batteries and motors, making the compass relevant to installations where those components can affect heading measurement.
Integration uses a GHR-04V-S interface and requires a supply within 4.75 ~ 5.3V. Supported controller types include PX4/ArduPilot systems such as CUAV and Pixhawk. The compass specifies a 2Mb communication rate and an 80Hz refresh rate, with a magnetic measurement range of -800 μT to +800 μT. Operating limits are -20 ~ +80℃ and 5% ~ 95% non-condensing humidity. Heading specifications include 0.25° accuracy as an effective value, 0.05° repetition accuracy and 0.01° resolution.
Specifications
| Specification | Value & conditions |
|---|---|
| Product | CUAV C-Compass CAN Electronic Compass |
| Purpose | External electronic compass for heading measurement, with magnetic filtering intended to reduce interference from cables, batteries and motors.Used as an external sensor. |
| MCU | STM32F4 |
| Protocol | DroneCAN |
| Sensor | RM3100 |
| Software architecture | CUAV M4C |
| Communication rate | 2Mb |
| Refresh rate | 80Hz |
| Noise | 15nT |
| Accuracy | 0.25° (effective value)Effective value. |
| Repetition accuracy | 0.05° |
| Resolution | 0.01° |
| Sensitivity | 13nT |
| Range | -800 μT to +800 μT |
| Controller type | PX4/ArduPilot (CUAV/Pixhawk e.g.) |
| Interface | GHR-04V-S |
| Operating voltage | 4.75 ~ 5.3V |
| Operating temperature | -20 ~ +80℃ |
| Operating humidity | 5% ~ 95% (non-condensing)Non-condensing. |
| Casing material | Aluminum alloy |
| Weight | 13g |
| Customized development | CUAV M4C software architecture supports customized development. |
Request a quote for CUAV C-Compass CAN Electronic Compass
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.