ChinaDroneRequest a quote →
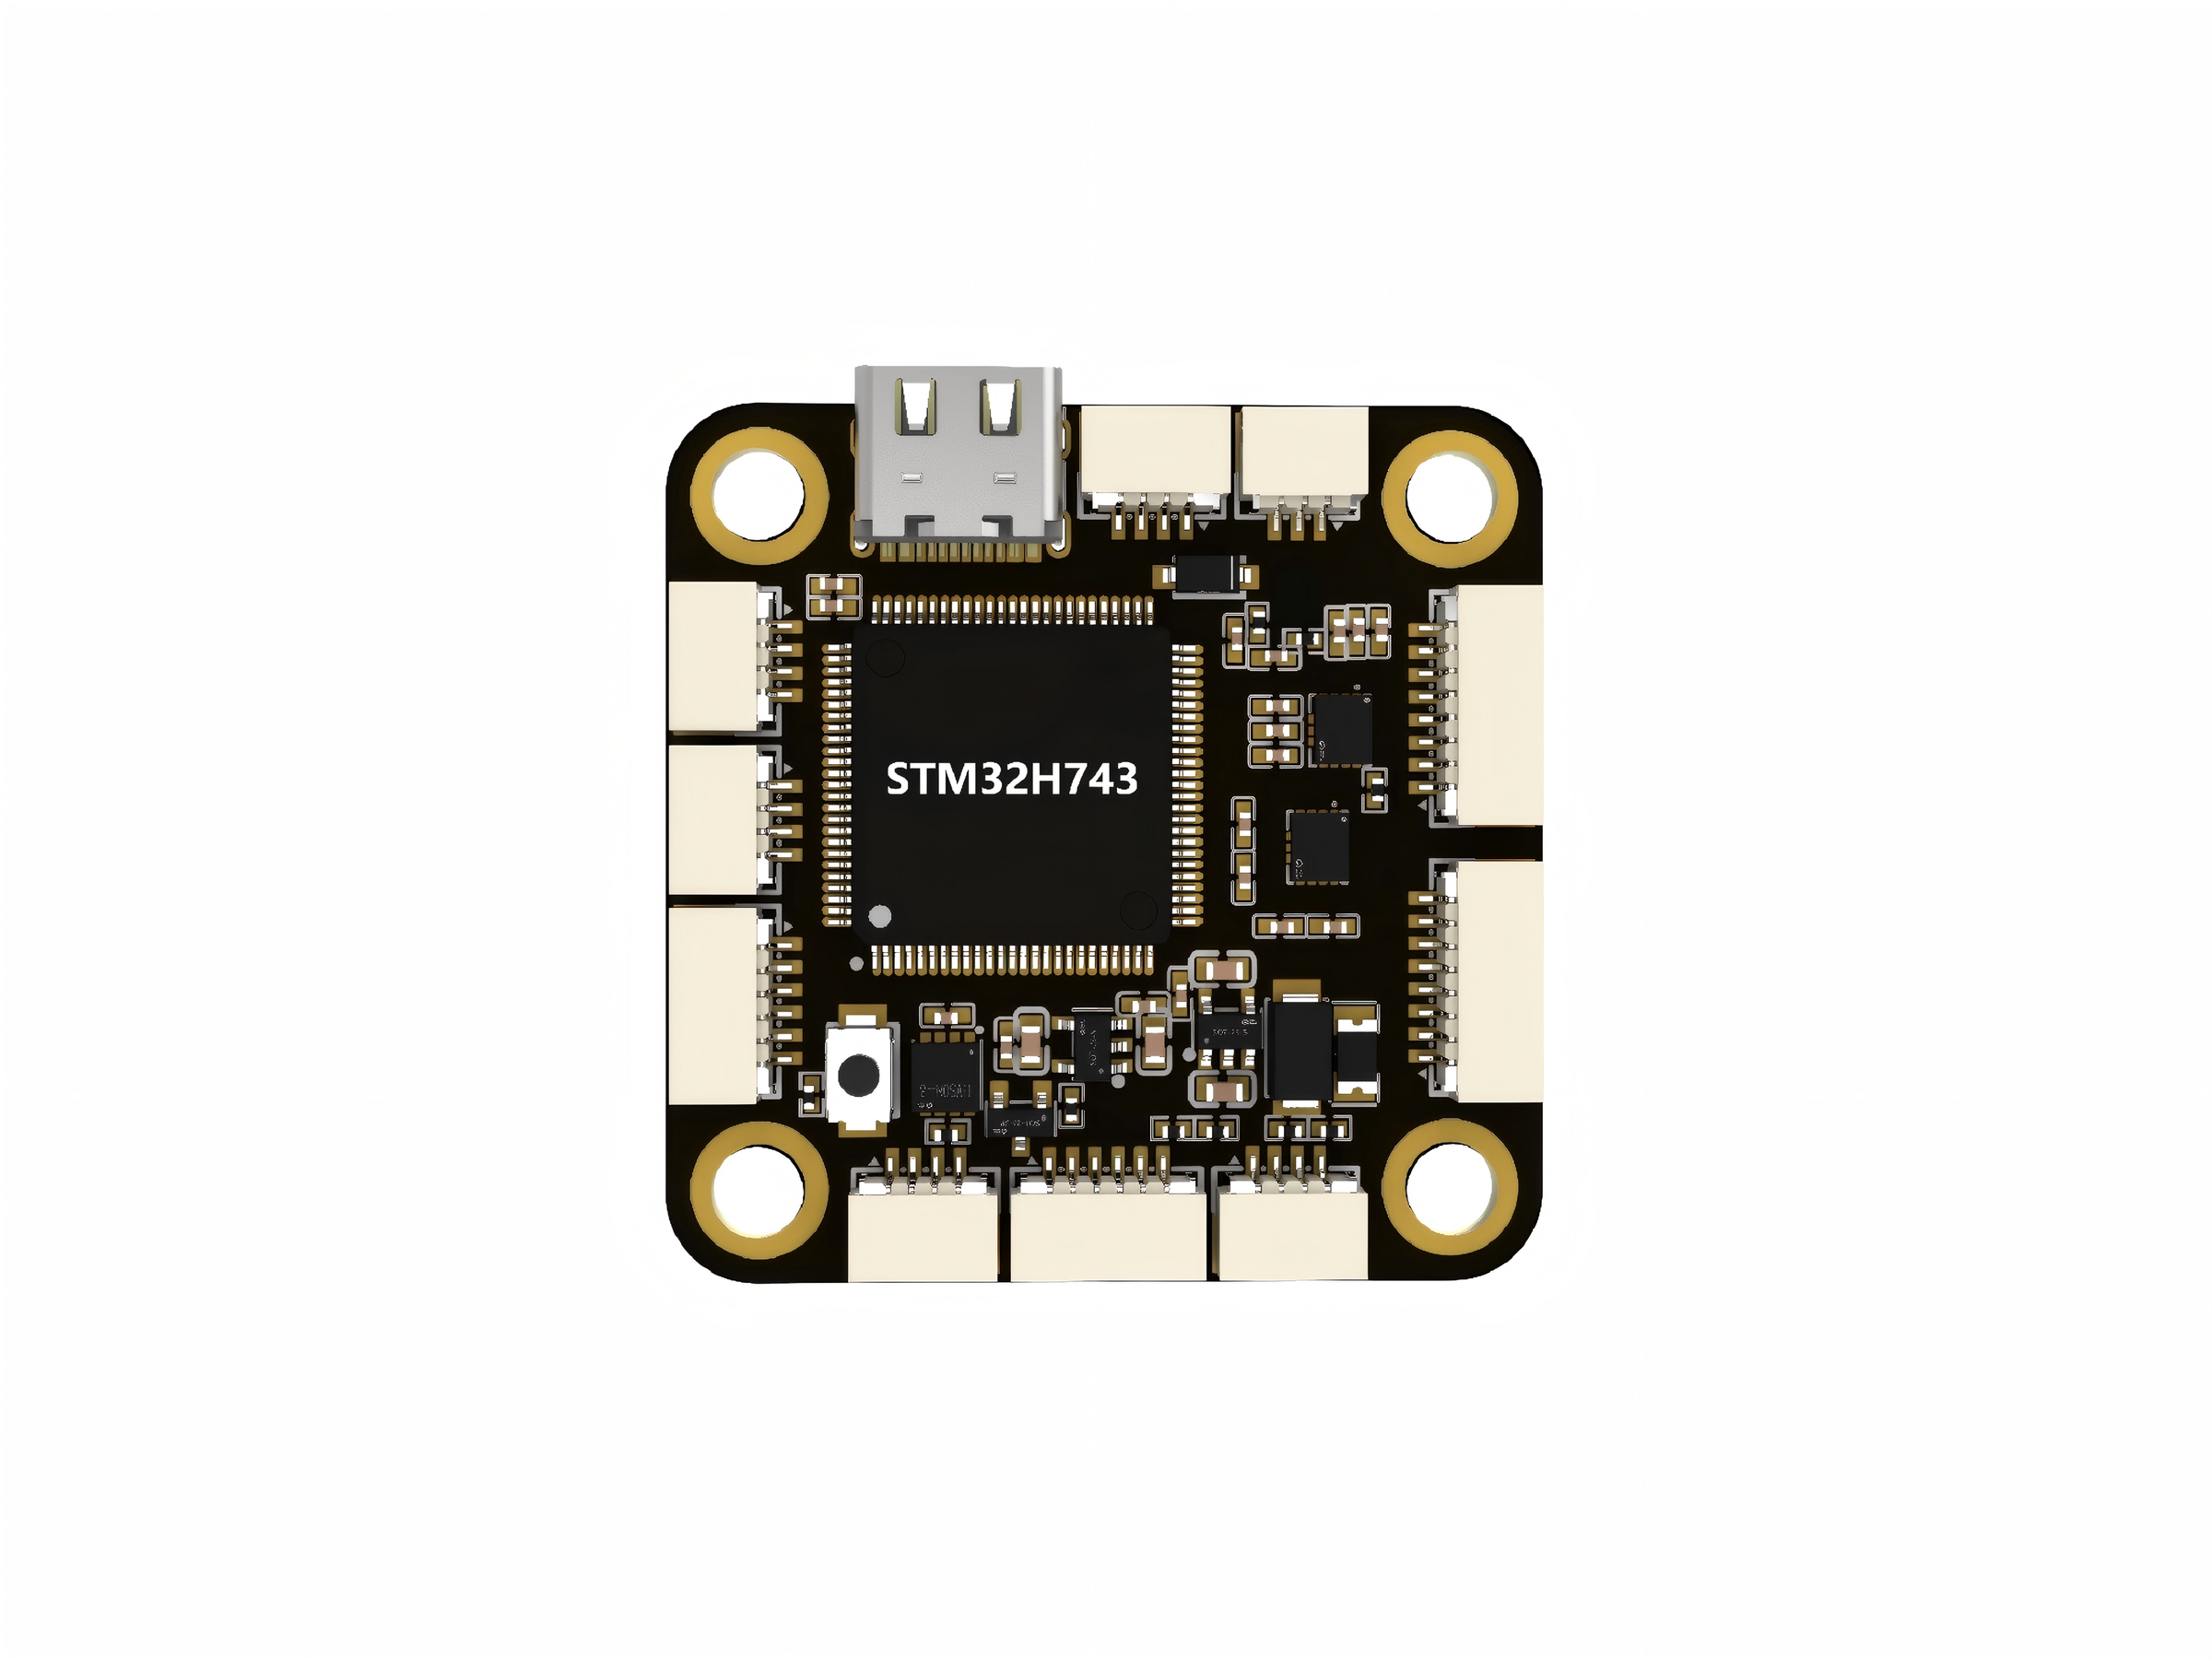
Wuwei WFG100A flight controller board with peripheral connectors and four mounting holesWuwei WFG100A flight controller board with peripheral connectors and four mounting holes

Wuwei WFG100A

The Wuwei WFG100A is an open-source flight controller for UAV prototype validation, research and learning. It combines an STM32H743 processor, redundant dual IMUs and onboard navigation sensors with extensive peripheral connections. Fully open hardware and software design resources, four supported firmware platforms and supplied pin configuration files support development and customization.

WuweiDrone flight controller

Get a free quote

Product overview

The Wuwei WFG100A supports UAV control research, teaching experiments and rapid prototype iteration, alongside customized UAV assembly and debugging. Its hardware and software design resources are fully open source for flight-control learning, source-code study and further development. Compatibility spans ArduPilot, PX4, Betaflight and INAV, with pin configuration files provided. The controller uses an STM32H743VIT6 processor running at 480MHz with 2MB Flash, a redundant dual-IMU architecture, an SPL06 barometer, a QMC5883P magnetic compass and an AT7456E analog OSD chip.

The board combines 30.5mm X 30.5mm mounting hole spacing with SH1.0 peripheral connectors and solder pads. It accepts 3S-6S battery input and provides two onboard BEC outputs, 5V@3A and 10V@3A. Ten ESC/servo signal outputs include bidirectional Dshot support on S1-S8, while two direct-plug ESC interfaces serve MOTO1~MOTO4 and MOTO5~MOTO8. Seven serial ports, CAN, IIC and a reserved SPI interface support peripheral expansion. Analog camera and video transmission interfaces accompany a direct-plug DJI O3/O4 HD video interface; black-box data recording uses a TF card.


Flight control & navigation

Specifications

Wuwei WFG100A specifications
SpecificationValue & conditions
Product type and purposeWuwei WFG100A open-source flight controller for UAV prototype validation, research and learning, with fully open-source hardware and software.
Supported firmware and configuration filesCompatible with ArduPilot / PX4 / Betaflight / INAV; pin configuration files are provided.
BEC outputsTwo onboard BEC outputs: 5V@3A and 10V@3A.
Battery input3S-6S battery input.
Main controllerSTM32H743VIT6, 480MHz, 2MB Flash.
Accelerometer and gyroscope architectureRedundant dual-IMU design supporting multiple model combinations; customization is supported for volume orders.
IMU optionsAdapted for ICM42688P, ICM42605, BMI270 and various Chinese-made IMU models.Supported IMU options; multiple model combinations are supported.
Onboard barometerSPL06.
Onboard magnetic compassQMC5883P.
Onboard OSD chipAT7456E.
ESC and servo signal outputs10 channels, S1-S10; S1-S8 support bidirectional Dshot communication.Bidirectional Dshot communication is supported on S1-S8.
Direct-plug ESC interface 11 interface integrating battery positive input BAT, power GND, MOTO1~MOTO4, current sensing and serial RX.
Direct-plug ESC interface 21 interface integrating battery positive input BAT, power GND, MOTO5~MOTO8, current sensing and serial RX.
Reserved IO pins4 pins, PIN_IO1 ~ PIN_IO4.
Serial ports7.
CAN ports1.
IIC ports1.
Analog camera interfaces1.
Analog video transmission interfaces1.
HD video transmission interface1 interface with direct-plug support for DJI O3/O4 HD video transmission.Supports direct connection of DJI O3/O4 HD video transmission equipment.
SPI sensor expansionReserved SPI interface supports additional high-precision SPI peripheral sensors, including barometers, IMUs and magnetic compasses.
Mounting hole spacing30.5mm X 30.5mm.
Peripheral connection methodsSH1.0 peripheral connectors and solder-pad connections.
STLINK debugging connectionSolder points on the reverse side.
Buzzer connectionSolder points on the reverse side.
LED strip connectionSolder points on the reverse side.
Black-box data recording mediumTF card.
Open design resourcesAll hardware and software design resources are open source.

Related guides

