Product overview
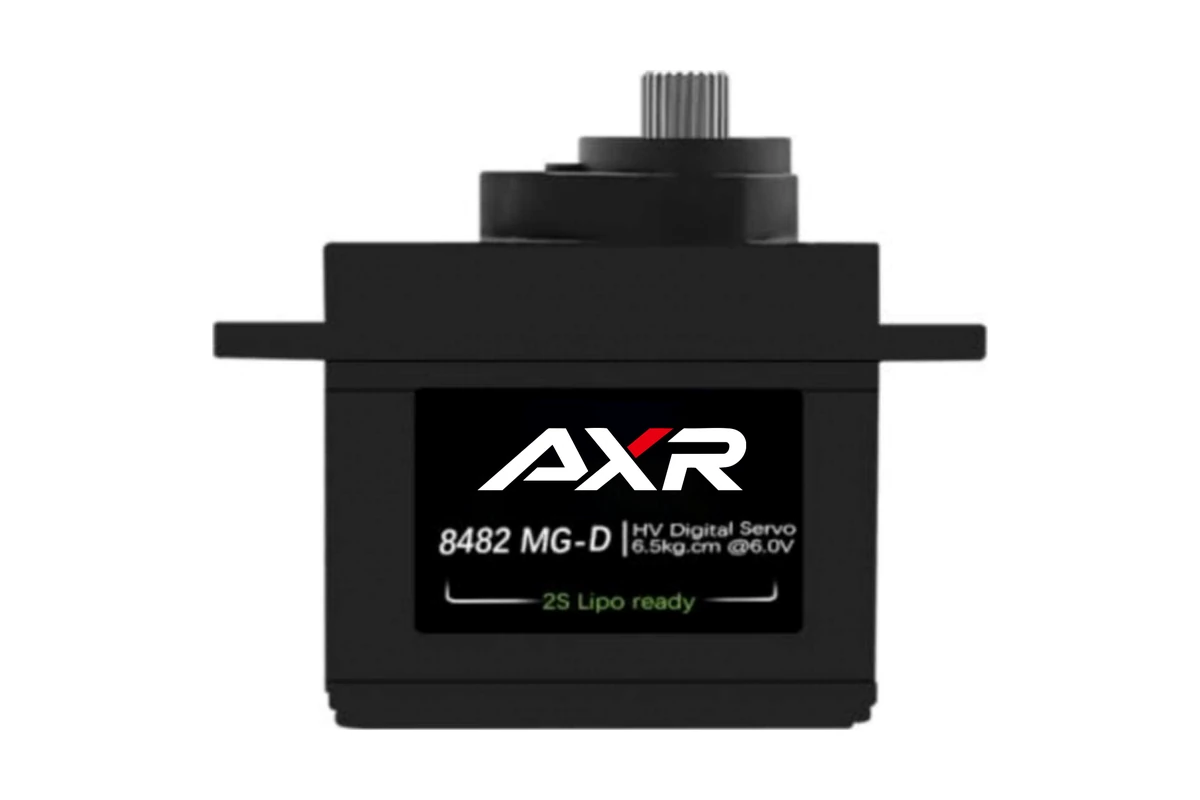
The AXR 8482 MG-D is a mini servo for fixed-wing control surfaces and mechanisms with restricted installation space. Its physical configuration combines an iron-core motor, metal gears and two bearings in a 30 × 11.9 × 26.3 mm body weighing 18.3 g, with a 250 mm cable. Installation planning must account for output-shaft location, mounting-hole spacing and connector clearance as well as the external envelope. Servo-arm length also affects selection because increasing the arm length reduces the force available at its end.
The servo accepts 4.8–8.4 V power and PWM control at 333 Hz. At 7.4 V, its rated torque is 2.4 kg·cm, while stall torque is 7.3 kg·cm and no-load speed is 0.059 s/60°. Stall torque cannot serve as a continuous-load rating; duty cycle also matters. The specified 1520 µs reference pulse differs from the 1500 µs position midpoint, so center and usable travel require adjustment to the controller and delivered version. Initial setup calls for unloaded or limited-load movement checks and supply headroom for transient current.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity | AXR 8482 MG-D mini servo |
| Intended application | Fixed-wing control surfaces and actuators with limited installation space |
| Operating voltage | 4.8–8.4 V |
| Stall torque | 4.4 kg·cmTest voltage: 4.8 V. |
| Speed | 0.101 s/60°Test voltage: 4.8 V; no load. |
| Running current | 0.23 ATest voltage: 4.8 V. |
| Stall current | 0.9 ATest voltage: 4.8 V; stalled. |
| Stall torque | 6.5 kg·cmTest voltage: 6 V. |
| Speed | 0.078 s/60°Test voltage: 6 V; no load. |
| Running current | 0.35 ATest voltage: 6 V. |
| Stall current | 1.05 ATest voltage: 6 V; stalled. |
| Stall torque | 7.3 kg·cmTest voltage: 7.4 V. |
| Speed | 0.059 s/60°Test voltage: 7.4 V; no load. |
| Running current | 0.4 ATest voltage: 7.4 V. |
| Stall current | 1.2 ATest voltage: 7.4 V; stalled. |
| Rated torque | 2.4 kg·cm @ 7.4 V7.4 V. |
| External dimensions | 30 × 11.9 × 26.3 mm |
| Weight | 18.3 g |
| Motor type | Iron-core motor |
| Gear material | Metal gears |
| Bearing count | 2 |
| Cable length | 250 mm |
| Control signal | PWM |
| Operating frequency | 333 Hz |
| Reference pulse width | 1520 µs |
| Pulse width and corresponding angle | 500 / 1500 / 2500 µs → -90 / 0 / 90° |
| Load limitation | Stall torque is not a continuous-load rating; continuous-duty selection requires consideration of rated torque and duty cycle. |
| Center position and travel | The 1520 µs reference pulse and 1500 µs position midpoint are both specified; center position and usable travel must be established for the controller and delivered version.Controller and delivered servo version. |
| Mechanical integration constraints | Integration requires allowance for output-shaft position, mounting-hole spacing and connector clearance; longer servo arms reduce available output force. |