Product overview
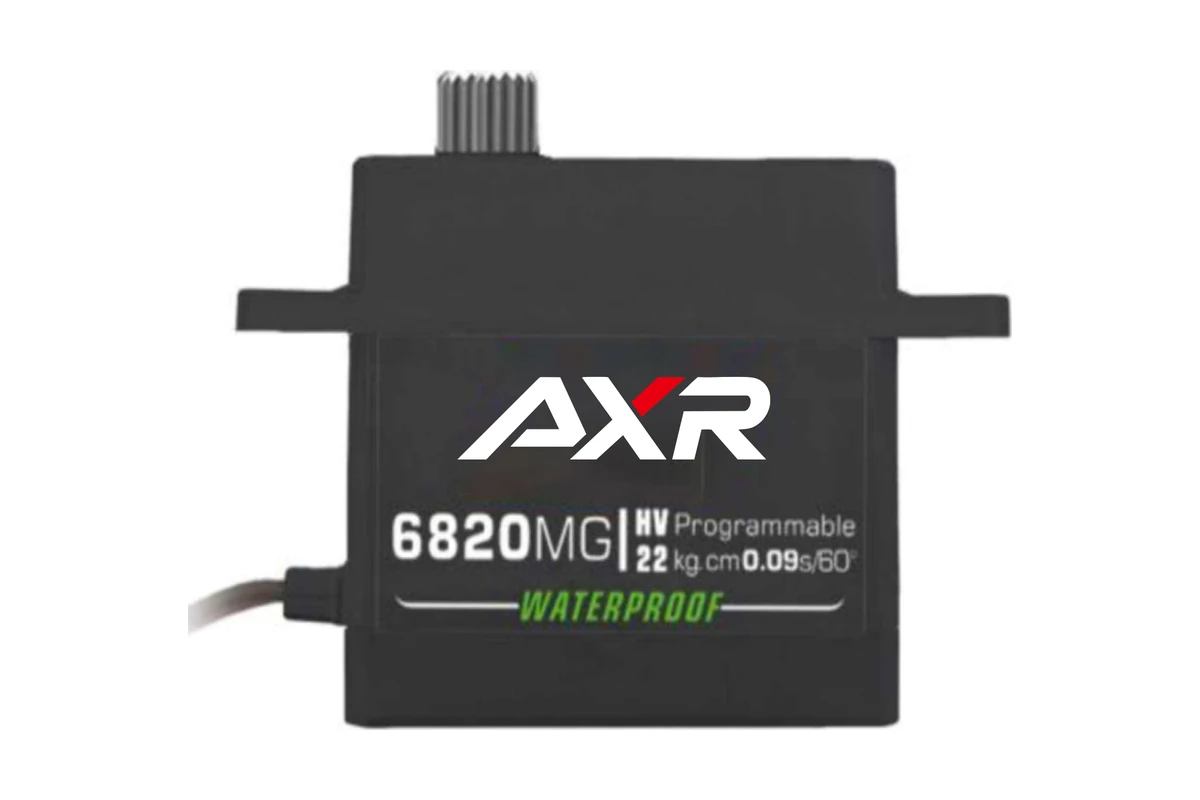
The Zhuhai SV Tech Co., Ltd. AXR 6820 MG-D is a standard servo for model steering, control-surface movement and mechanical actuation. Its physical configuration combines an iron-core motor, metal gears and two bearings in a 40 × 20 × 35.5 mm body weighing 53 g. A 300 mm cable supports installation within the mechanism. Electrical integration uses PWM control at 333 Hz with a 4.8–8.4 V supply, while mechanical integration requires matching the mounting holes and servo-arm connection.
At 8.4 V, the servo has a stall torque of 27 kg·cm and a no-load speed of 0.087 s/60°, with running and stall currents of 0.35 A and 3.2 A. Continuous-load selection must instead account for its 6 kg·cm rated torque at 7.4 V and the duty cycle. The 1520 µs reference pulse and 1500 µs positional midpoint require attention to the controller and delivered version when establishing neutral and usable travel. Mounting-part fabrication also requires the final installation drawing and interface version.
Specifications
| Specification | Value & conditions |
|---|---|
| Model and product type | AXR 6820 MG-D standard servo for model steering, control surfaces and mechanical actuators. |
| Operating voltage | 4.8–8.4 V |
| Rated torque | 6 kg·cm @ 7.4 V7.4 V supply. |
| External dimensions | 40 × 20 × 35.5 mm |
| Weight | 53 g |
| Motor type | Iron-core motor |
| Gear material | Metal gears |
| Bearing count | 2 |
| Cable length | 300 mm |
| Control signal | PWM |
| Operating frequency | 333 Hz |
| Reference pulse width | 1520 µs |
| Pulse width and corresponding angle | 500 / 1500 / 2500 µs → -90 / 0 / 90° |
| Performance at 5 V |
|
| Performance at 6 V |
|
| Performance at 7.4 V |
|
| Performance at 8.4 V |
|
| Stall-torque limitation | Stall torque cannot be used as a continuous-load rating; continuous-duty selection must consider rated torque and duty cycle.Continuous-load selection. |
| Neutral position and travel | The 1520 µs reference pulse differs from the 1500 µs positional midpoint; neutral position and usable travel depend on the controller and delivered version.Controller and delivered servo version. |
| Mounting dimensions and interface | Drawing and specification dimensions may use different reference points; mounting parts require the final installation drawing and interface version.Mounting-part fabrication. |
| Mechanical integration | Integration requires matching the power supply, signal pulse width, mounting holes and servo-arm connection; initial setup should establish neutral, direction and mechanical travel before increasing load.Initial setup with the load removed or limited. |
| Power and travel constraints | Provide supply headroom for transient current and avoid cable voltage drop, reversed connections and sustained loading against mechanical stops.Transient current demand and mechanical end stops. |