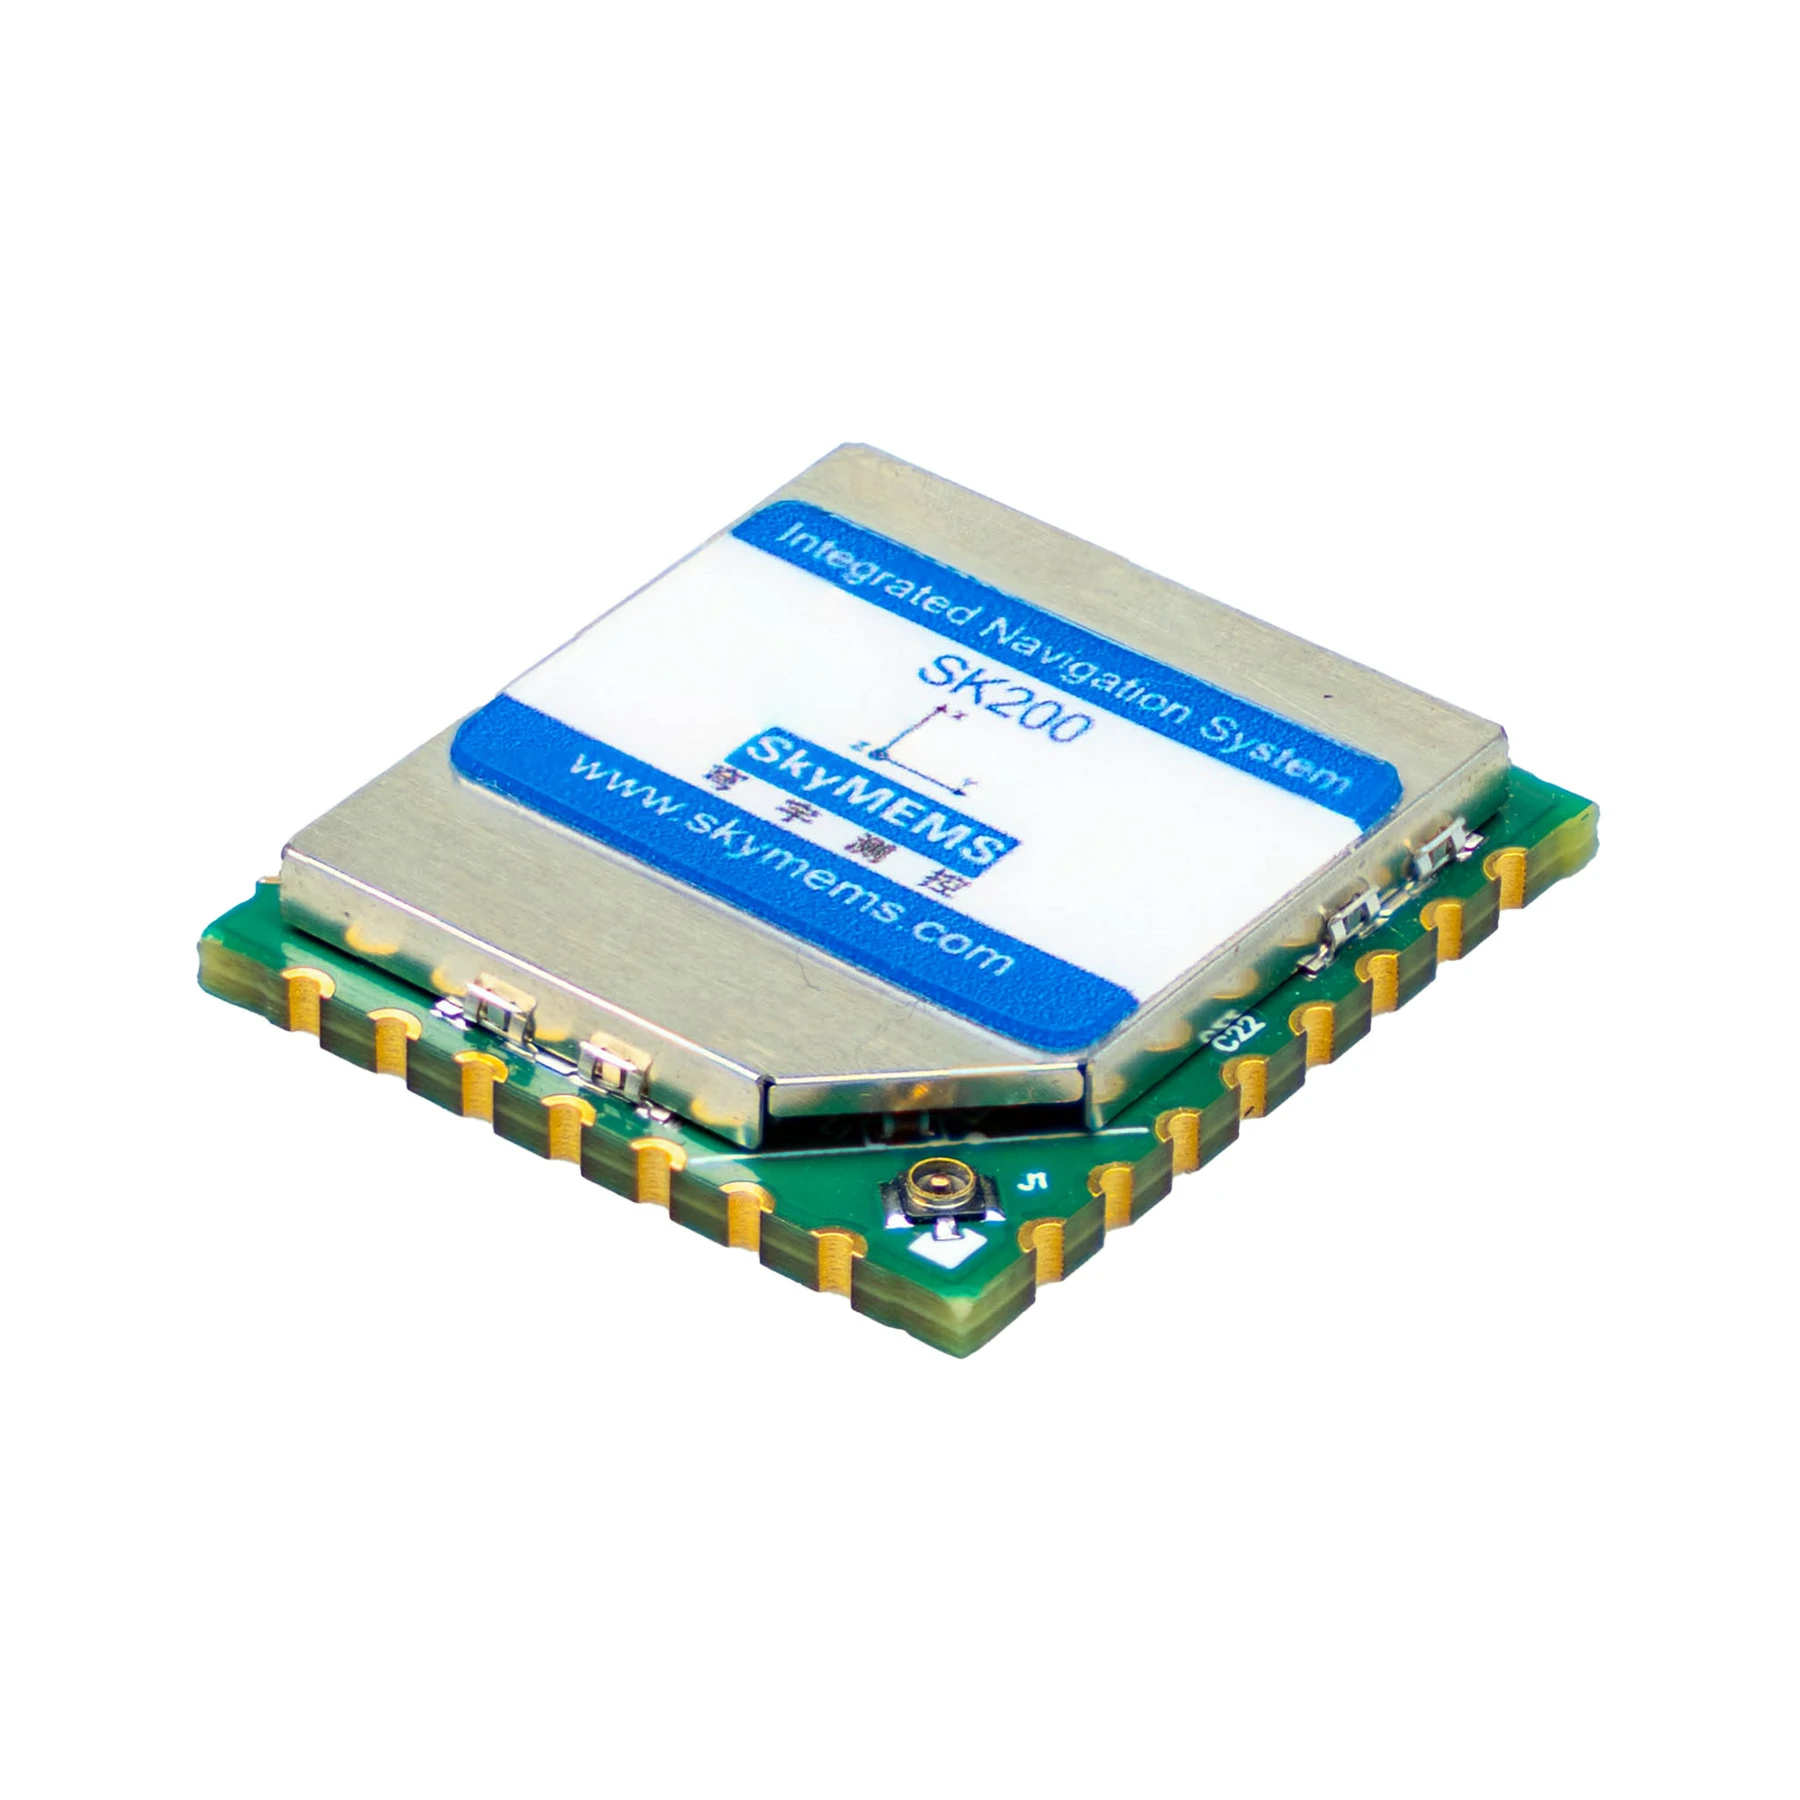
| Product | SkyMEMS SK200 High Performance GNSS-Aided Integrated Navigation System |
|---|
| Construction | Surface-mount GNSS/INS integrating a 3-axis gyroscope, 3-axis accelerometer, 3-axis magnetometer, barometer, high-sensitivity GNSS receiver and microprocessor. |
|---|
| Navigation processing | Extended Kalman Filter loosely couples GNSS position and velocity with MEMS inertial acceleration and angular data. |
|---|
| Applications and limitation | Integrated navigation for ground vehicles and fixed-wing aircraft; not recommended for rotary-wing UAVs. |
|---|
| Package contents | Integrated SIM card and supporting circuitry.Included equipment. |
|---|
| Bias instability | Gyro 3°/h; accelerometer 80ug.Allan variance. |
|---|
| Bias compensation and calibration | Real-time gyro and accelerometer bias tracking and compensation; full temperature range sensor calibration. |
|---|
| IMU data output rate | Up to 800 Hz.IMU output. |
|---|
| Dimensions and weight | 24×22×3.8 mm; less than 4g. |
|---|
| Operating and storage temperature | Operating: -40°C ~ 85°C; storage: -40°C ~ 85°C. |
|---|
| Coordinate conventions | Right-Forward-Up body frame; Roll-Pitch-Yaw attitude output order; North-East-Up (NEU) navigation frame. |
|---|
| Initialization | Remain stationary for at least 3 seconds after startup; ideally obtain a valid GNSS fix before straight-line movement above 3 m/s.After startup; straight-line initialization movement following a valid GNSS fix. |
|---|
| GNSS reacquisition time | A few seconds to 30 seconds.A recent valid fix; timing depends on the previous fix, device movement and GNSS signal quality. |
|---|
| 2D positioning | Latitude and longitude available; altitude may be unreliable.Fix Type = 2. |
|---|
| 3D positioning and GNSS validity | Position and altitude available; GNSS data considered valid only with Fix Type = 3.Fix Type = 3. |
|---|
| Navigation during GNSS outage | Navigation continues using IMU data, with positioning errors gradually accumulating over time.Complete GNSS signal loss; error accumulation depends on outage duration and motion conditions. |
|---|
| Euler angle dynamic range | Heading and roll: ±180°; pitch: ±90°. |
|---|
| Static attitude accuracy | Pitch and roll: 0.01°; magnetic heading: 1°.Static; 1σ; heading uses magnetic reference. |
|---|
| Dynamic heading accuracy | 0.2°.Dynamic; 1σ. |
|---|
| Angular resolution | 0.001°. |
|---|
| Gyroscope range | ±2000°/s. |
|---|
| Gyroscope noise, cross-axis sensitivity and bandwidth | - Noise density: 0.003°/s/√Hz;
- cross-axis sensitivity: 0.05°;
- bandwidth: 200 Hz.
Gyroscopes. |
|---|
| Accelerometer range | ±16 g. |
|---|
| Accelerometer noise, cross-axis sensitivity and bandwidth | - Noise density: 0.14 mg/√Hz;
- cross-axis sensitivity: ±0.05°;
- bandwidth: 200 Hz.
Accelerometers. |
|---|
| GNSS receiver | 72 Channel; L1 C/A, B1I, E1 B/C, L10F; GPS, BeiDou, Galileo, GLONASS and QZSS. |
|---|
| Time to first fix | 3 s.Hot start. |
|---|
| Interface | UART. |
|---|
| Supply voltage | 3.2 ~ 5.5 V.SMD. |
|---|
| Vibration and shock resistance | Vibration resistance: 20 grms at 20-2000Hz; shock resistance: 2000g for 0.5ms.Vibration: 20-2000Hz; shock: 0.5ms. |
|---|
| Warranty and MTBF | Warranty: usually one year; MTBF: more than 100000hours.Warranty usually one year. |
|---|