ChinaDroneRequest a quote →
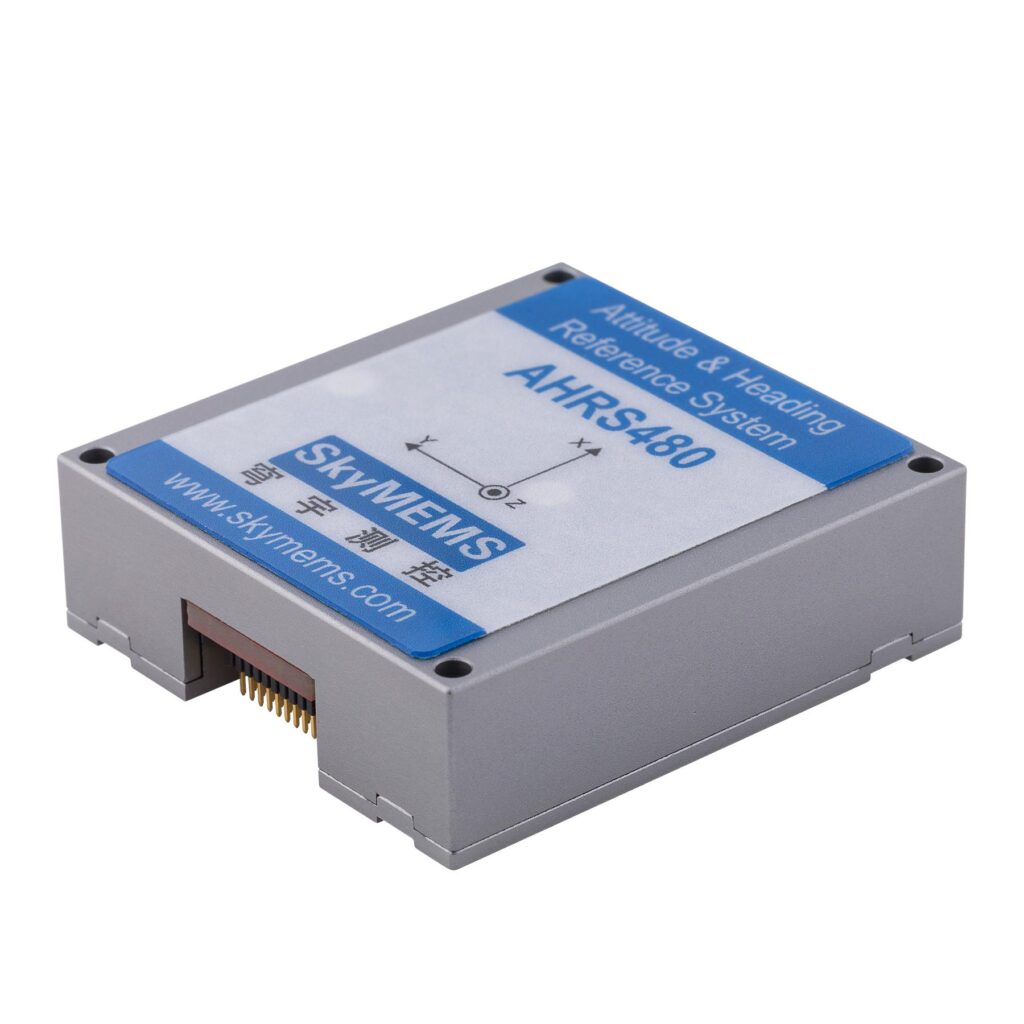
SkyMEMS AHRS480 Attitude and Heading Reference System in a gray housing with a blue-and-white label and connector pins.SkyMEMS AHRS480 Attitude and Heading Reference System in a gray housing with a blue-and-white label and connector pins.

AHRS480 Attitude and Heading Reference System

The SkyMEMS AHRS480 Attitude and Heading Reference System is a compact navigation sensor for aviation, maritime, robotics and unmanned systems. It combines accelerometers, gyroscopes and magnetometers with sensor fusion to deliver real-time attitude, heading and angular velocity measurements, with UART or SPI communication.

SkyMEMSIMU sensors
Applications
Aviation, maritime, robotics and unmanned systems.

Get a free quote

Product overview

The SkyMEMS AHRS480 Attitude and Heading Reference System combines accelerometers, gyroscopes and magnetometers with sensor fusion algorithms to provide real-time attitude, heading and angular velocity measurements. Designed for orientation and motion sensing in dynamic environments, it serves aviation, maritime, robotics and unmanned systems. Its compact design supports integration into existing commercial and industrial systems, while disturbance compensation addresses external influences such as magnetic interference.

Yaw accuracy is 0.3° under static conditions and 0.5° under dynamic conditions; pitch and roll accuracy is 0.1° static and 0.3° dynamic. Attitude ranges are ±180° for yaw and roll and ±90° for pitch. Sensor ranges are ±450°/s for the gyroscope, ±16g for the accelerometer and ±2.5gauss for magnetic measurement. The AHRS480 offers UART or SPI communication, with SPI output rates up to 2000Hz, and operates from -40°C to +85°C.


Flight control & navigation

Specifications

AHRS480 Attitude and Heading Reference System specifications
SpecificationValue & conditions
Product identitySkyMEMS AHRS480 Attitude and Heading Reference System
Sensor architecture and measurementsCombines accelerometers, gyroscopes and magnetometers using sensor fusion algorithms to deliver real-time attitude, heading and angular velocity measurements.
ApplicationsAviation, maritime, robotics and unmanned systems.
Yaw attitude angle accuracyStatic 0.3°, dynamic 0.5°Static: 0.3°; dynamic: 0.5°.
Pitch and roll attitude angle accuracyStatic 0.1°, dynamic 0.3°Static: 0.1°; dynamic: 0.3°.
Attitude angle rangeYaw ±180°, Pitch ±90°, Roll ±180°
Sensor measurement rangesGyro ±450°/s, accelerometer ±16g, magnetic ±2.5gauss
Interfaces and output rateUART or SPI; SPI output rate up to 2000HzThe output rate of up to 2000Hz applies to SPI.
Working temperature-40°C to +85°C
Disturbance compensationCompensates for external disturbances, including magnetic interference, and offers temperature stability.
Design and integrationCompact design for integration into existing commercial and industrial systems.

Related guides

