ChinaDroneRequest a quote →
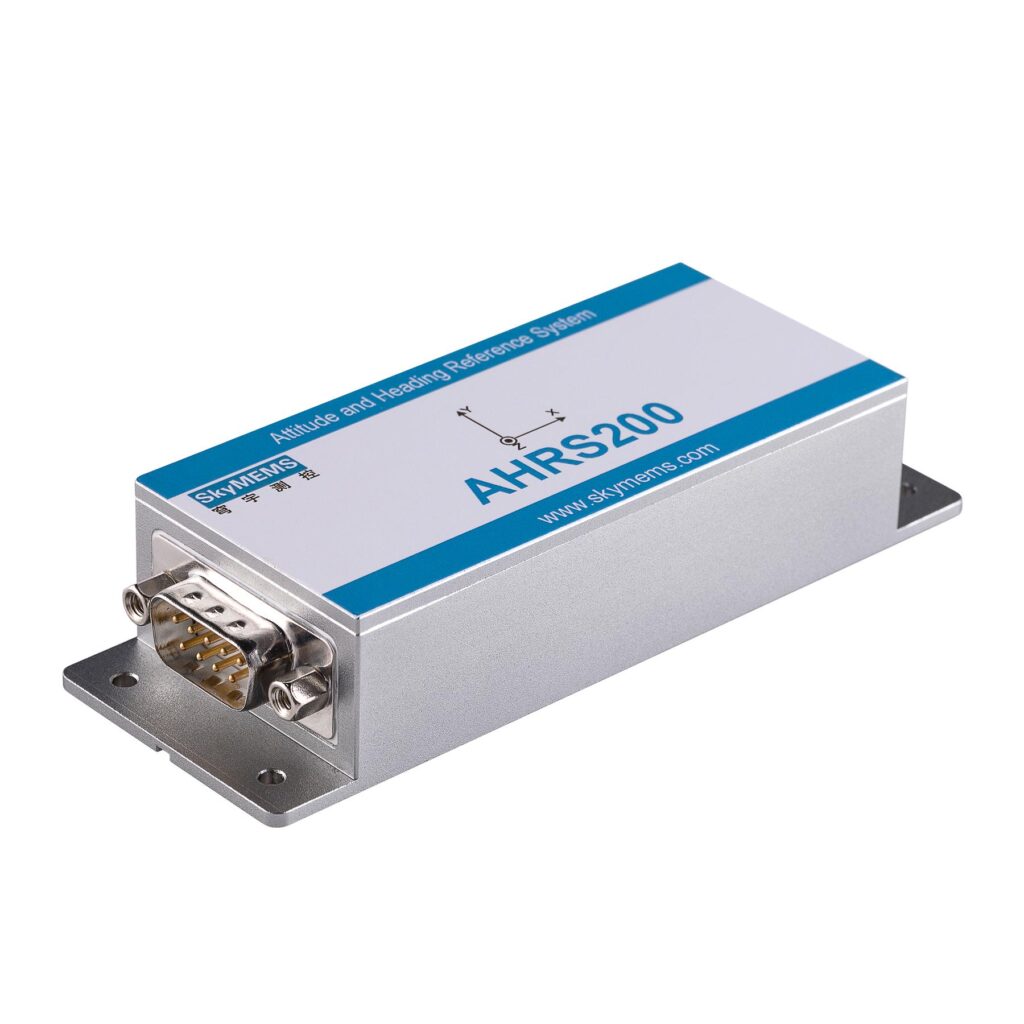
SkyMEMS AHRS200 attitude and heading reference system in a silver enclosure with a D9 connectorSkyMEMS AHRS200 attitude and heading reference system in a silver enclosure with a D9 connector

SkyMEMS AHRS200

The SkyMEMS AHRS200 is a compact, standalone attitude and heading reference system for UAV flight control, unmanned vehicles, ROVs and stabilization applications. It uses calibrated MEMS inertial sensors to deliver attitude and auxiliary sensing outputs, with RS485 communication, an IP67 enclosure and low power consumption.

SkyMEMSIMU sensors
Applications
UAV flight control, unmanned vehicle control, ROV, platform stabilization, robotics control and antenna stabilization
Input voltage
6 ~ 15 VDC
Weight
Around 100grams
Dimensions
106.7 × 38.1 × 22.3 mm

Get a free quote

Product overview

The AHRS200 uses MEMS inertial sensors with temperature calibration and nonorthogonal error compensation to generate pitch, roll and yaw, together with acceleration, angular rate, magnetic field intensity and temperature signals. Its applications include UAV flight control, unmanned vehicle control, ROV navigation, robotics control, platform stabilization and antenna stabilization. Euler angle output covers ±180° in heading and roll and ±90° in pitch, with 0.01° resolution. The RS485 interface operates at 230400 bps and provides a 100Hz output rate.

The compact module combines glue encapsulation with an IP67 protection level. Its body measures 106.7 × 38.1 × 22.3 mm and weighs around 100 grams, with a D9 connector and four mounting holes. It accepts a 6 ~ 15 VDC supply and consumes less than 0.2 W. The working temperature range is -40~+85°C, with storage rated at -55~+105°C. Gyroscope, accelerometer and magnetometer bandwidths are each 200 Hz; the magnetometer provides a ±2 Gauss dynamic range and 120 uGauss resolution.


Flight control & navigation

Specifications

SkyMEMS AHRS200 specifications
SpecificationValue & conditions
Product typeSkyMEMS AHRS200 standalone attitude and heading reference system using MEMS-based inertial sensors
ApplicationsUAV flight control, unmanned vehicle control, ROV, platform stabilization, robotics control and antenna stabilization
Sensor calibrationTemperature calibration and nonorthogonal error compensation
OutputsPitch, roll, yaw, acceleration, angular rate, magnetic field intensity and temperature
ConstructionGlue encapsulation and full calibration
Euler angle dynamic range±180° (heading, roll); ±90° (pitch)
Angle resolution0.01°
Gyroscope bias instability3 °/hAllan.
Gyroscope bias repeatability20 °/h
Gyroscope bandwidth200 Hz
Accelerometer bias instability100 ugAllan.
Accelerometer bias repeatability200 ug
Accelerometer bandwidth200 Hz
Accelerometer non-linearity100 ppm
Magnetometer dynamic range±2 Gauss
Magnetometer resolution120 uGauss
Magnetometer RMS noise50 uGauss10Hz.
Magnetometer bandwidth200 Hz
Working temperature-40~+85°C
Storage temperature-55~+105°C
Protection levelIP67
Input voltage6 ~ 15 VDC
Power consumptionLess than 0.2 W
InterfaceRS485
Baud rate230400 bpsRS485 interface.
Output rate100HzRS485 interface.
Dimensions106.7 × 38.1 × 22.3 mm
WeightAround 100grams
ConnectorD9 connector
Mounting holes4 holes

Related guides

