ChinaDroneRequest a quote →
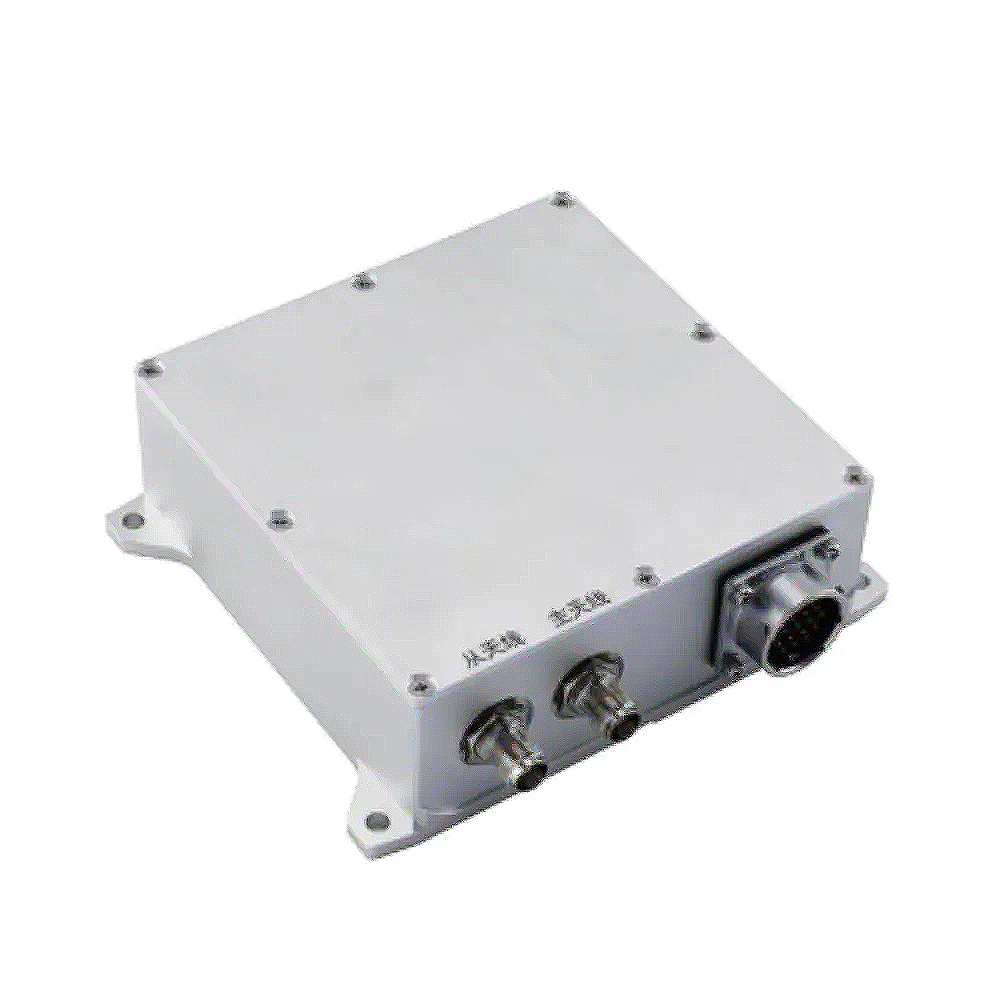
Moneypro MOPKT-EX8-3D Dual-Antenna Integrated Navigation System in a silver enclosure with front connectorsMoneypro MOPKT-EX8-3D Dual-Antenna Integrated Navigation System in a silver enclosure with front connectors

Moneypro MOPKT-EX8-3D Dual-Antenna Integrated Navigation System

The Moneypro MOPKT-EX8-3D Dual-Antenna Integrated Navigation System combines a MEMS IMU and satellite positioning receiver for UAVs, autonomous vehicles, robotics and marine navigation. Tightly coupled INS/GNSS processing and dual-antenna heading fusion provide real-time angular rate, acceleration, heading, attitude, velocity and position outputs, with support for external vehicle odometer integration.

MoneyProDrone antennas
Applications
UAVs; autonomous driving and intelligent vehicles; robotics and UGVs; marine navigation and ship positioning; agricultural automation; industrial automation and mobile platforms; surveying and mapping; defense and security.
Weight
≤ 1200 g
Dimensions
143.8 × 154 × 49 mm

Get a free quote

Product overview

The Moneypro MOPKT-EX8-3D Dual-Antenna Integrated Navigation System combines a MEMS inertial measurement unit with a built-in satellite positioning receiver. It uses temperature error compensation, system-level self-calibration and real-time IMU non-orthogonal compensation alongside tightly coupled INS/GNSS navigation. Dual-antenna heading fusion supports its heading functions, while angular rate, acceleration, heading, attitude, velocity and position are delivered in real time. External vehicle odometer integration supports enhanced navigation accuracy in challenging environments. Applications include UAVs, autonomous vehicles, robotics, marine navigation, agricultural automation, industrial automation, and surveying and mapping.

The system operates from a 9~36 V supply, with power dissipation of ≤ 8 W and an operating temperature range of -45~80°C. It measures 143.8 × 154 × 49 mm and weighs ≤ 1200 g. Navigation connections comprise two RS-422/RS-232 channels, accompanied by one RS-232 channel for differential output, one PPS output and one CAN output. Cold boot takes 20 s, and the data update rate is 100 Hz with customization supported. Horizontal position accuracy is 1.5 m RMS for single-point positioning and 0.8 cm + 1 ppm RMS with RTK.


Flight control & navigation

Specifications

Moneypro MOPKT-EX8-3D Dual-Antenna Integrated Navigation System specifications
SpecificationValue & conditions
Construction and navigation functionsIntegrated MEMS IMU and satellite positioning receiver; temperature error compensation, system-level self-calibration, dual-antenna heading fusion, tightly coupled INS/GNSS navigation and real-time IMU non-orthogonal compensation. Real-time angular rate, acceleration, heading, attitude, velocity and position outputs; external vehicle odometer integration supported.
ApplicationsUAVs; autonomous driving and intelligent vehicles; robotics and UGVs; marine navigation and ship positioning; agricultural automation; industrial automation and mobile platforms; surveying and mapping; defense and security.
Path angle accuracy0.1°RMS; 2m baseline.
Pitch / roll angle accuracy0.2°; 0.1°; 0.08°; 0.05°RMS; Type 1, Type 2, Type 3 and Type 4, respectively.
Horizontal position accuracy1.5 m (single point); 0.8 cm + 1 ppm (RTK)RMS; single-point and RTK positioning, respectively.
Altitude accuracy3 m (single point); 1.5 cm + 1 ppm (RTK)RMS; single-point and RTK positioning, respectively.
Speed accuracy0.1 m/sRMS.
Gyroscope measuring range±400°/s
Gyroscope zero-offset stability10°/h; 3°/h; 1°/h; 0.4°/h10-second smoothing, 1σ, room temperature; Type 1, Type 2, Type 3 and Type 4, respectively.
Gyroscope full-temperature zero-drift variation60°/h; 20°/h; 10°/h; 2°/h10-second smoothing, RMS, variable temperature; Type 1, Type 2, Type 3 and Type 4, respectively.
Gyroscope zero-bias repeatability20°/h; 3°/h; 1°/h; 0.3°/hType 1, Type 2, Type 3 and Type 4, respectively.
Gyroscope random walk0.5°/√h; 0.15°/√h; 0.05°/√h; 0.02°/√hType 1, Type 2, Type 3 and Type 4, respectively.
Gyroscope scale-factor nonlinearity100 ppm
Gyroscope scale-factor repeatability100 ppm
Accelerometer measuring range±10 g
Accelerometer zero-offset stability0.05 mg10-second smoothing, 1σ, room temperature.
Accelerometer full-temperature zero-drift variation2 mg10-second smoothing, RMS, variable temperature.
Accelerometer zero-bias repeatability0.2 mg
Accelerometer scale-factor repeatability500 ppm
Accelerometer cross coupling0.1%
GLONASSL1L2
GalileoE1 E5a E5b
QZSSL1 L2 L5
Startup time20 sCold boot.
Data update rate100 Hz (customizable)
Supply voltage and power dissipation9~36 V; ≤ 8 W
Operating temperature-45~80°C
Dimensions143.8 × 154 × 49 mm
Weight≤ 1200 g
Interfaces2 RS-422/RS-232 channels (navigation output); 1 RS-232 channel (differential output); 1-channel PPS output; 1 CAN output

Related guides

