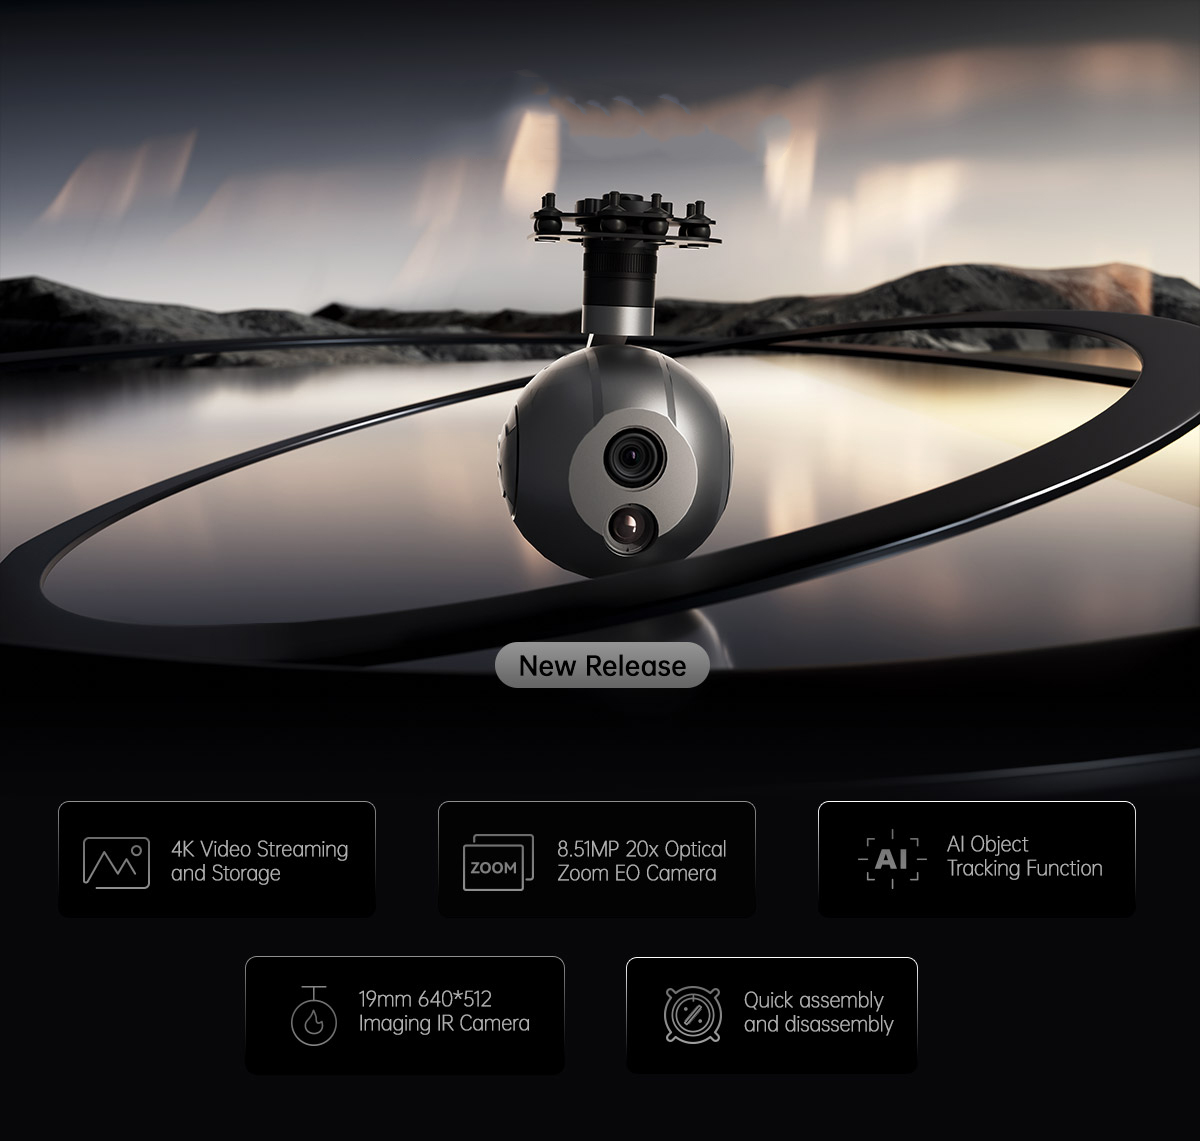
| Product and supplied equipment | 1 gimbal camera device, screws, aluminum cylinders, damping balls, damping boards and a plastic box with foam cushion |
|---|
| Voltage | - Working voltage: 16V;
- input voltage: 4S ~ 6S (14.8V~25.2V);
- output voltage: 5V (connect with PWM)
5V output with PWM connection. |
|---|
| Current and power consumption | Dynamic current: 1000~1500mA @ 16V; power consumption: Average 16W, Max 24WDynamic current at 16V. |
|---|
| Working environment temperature | -20 °C ~ +50 °C |
|---|
| Video output | Micro HDMI(1080P 30fps/60fps) / IP (RTSP/UDP 4K/1080P/720P 30fps H264/H265) |
|---|
| Local storage and recording formats | TF card (Up to 256G,class 10, FAT32); pictures: JPG(4K:3840*2160); video: MP4(4K 30fps)TF card storage. |
|---|
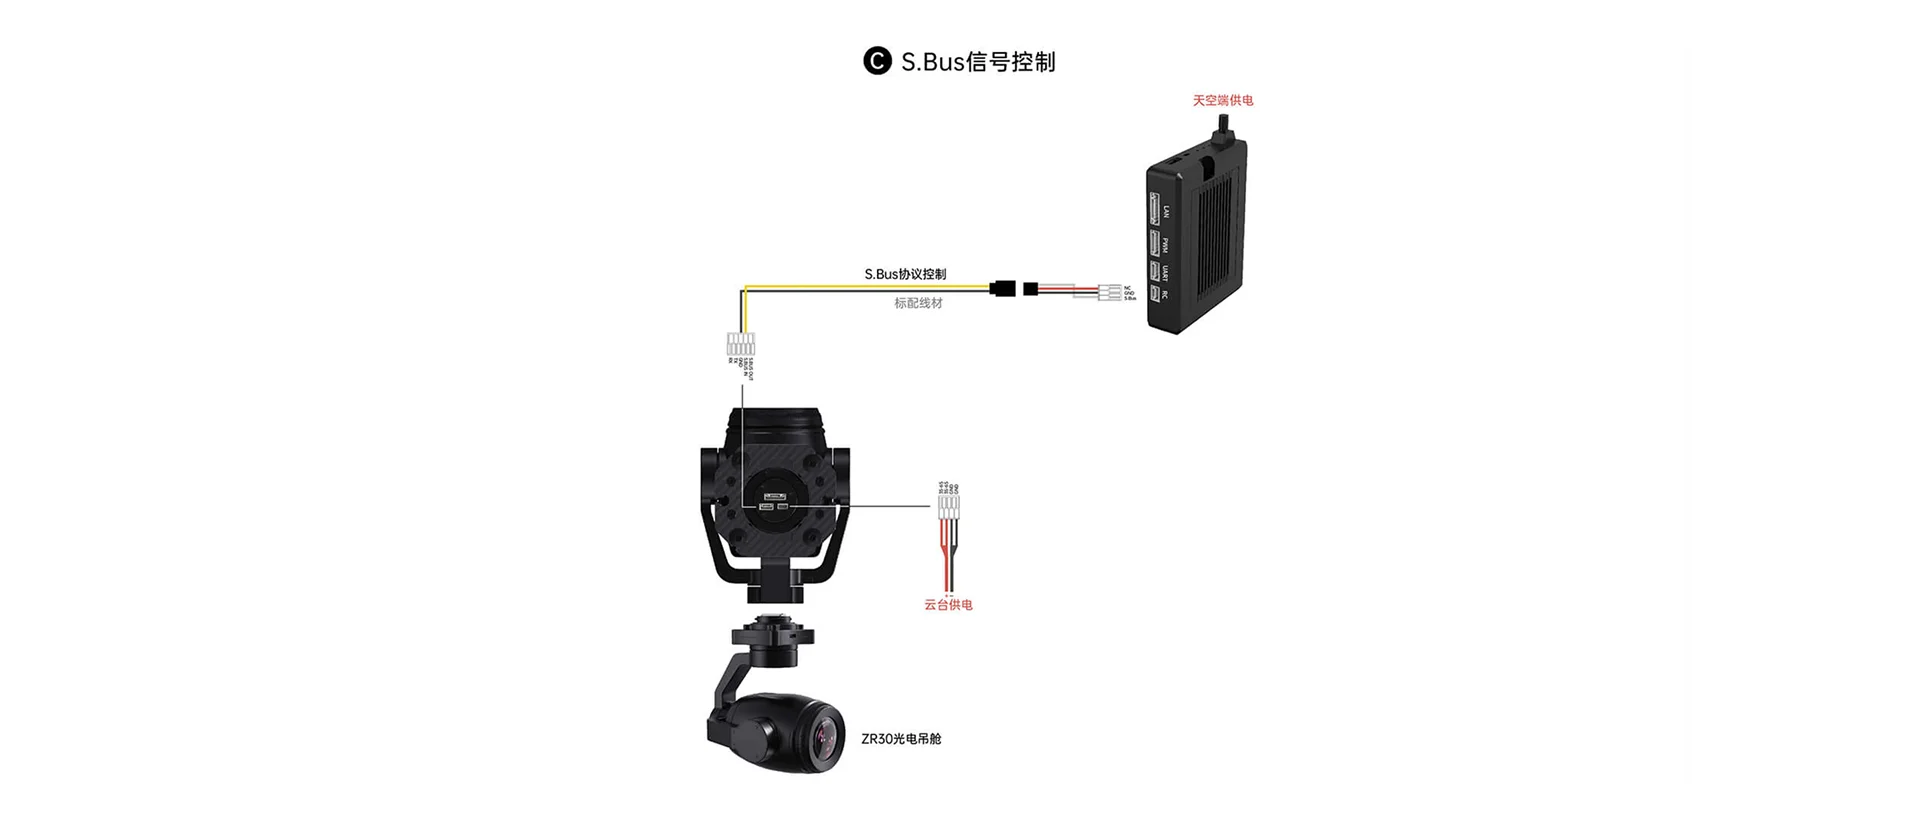
| Control methods | PWM / TTL / S.BUS / TCP / UDP |
|---|
| Gimbal vibration angle and centering | Pitch/Roll/Yaw vibration angle: ±0.02°; one-key centering supported |
|---|
| Imaging sensor | SONY 1/2.5″ “Exmor R” CMOS; total pixels: 8.51MPEO camera. |
|---|
| Optical zoom and lens | 20x, F2.0 to F3.8,f = 4.4 mm (Wide), 88.4 mm (Tele), up to 30x with Super ResolutionEO camera; Wide and Tele focal lengths; Super Resolution for up to 30x. |
|---|
| Digital zoom | 12x (240x with optical zoom)EO camera; combined with optical zoom for 240x. |
|---|
| Minimum working distance | 80 mm (Wide end), 800 mm (Tele end)EO camera; Wide and Tele ends respectively. |
|---|
| Angle of view | H: 70.2°(Wide end) ~ 4.1°(Tele end); V: 43.1°(Wide end) ~ 2.3°(Tele end)EO camera; Wide to Tele ends. |
|---|
| Focus | Auto/ManualEO camera. |
|---|
| Signal-to-noise ratio | 50dBEO camera. |
|---|
| Recommended illumination | 100 to 100000 luxEO camera. |
|---|
| Minimum illumination | 1.6 lux (1/30 sec, 50%, ICR off, High Sensitivity mode Off); 0.4 lux (1/30 sec, 50%, ICR Off, High Sensitivity mode On); 0.21 lux (50%, ICR off, Slow Shutter 1/4s, High sensitivity off); 0.06 lux (50%, ICR off, Slow shutter 1/4s, High sensitivity on)EO camera; 50%, ICR off, with shutter and sensitivity settings attached to each value. |
|---|
| Gain and white balance | Gain: Auto; white balance: Auto/ManualEO camera. |
|---|
| Electronic shutter speed | 1/1 to 1/10000 secEO camera. |
|---|
| Selectable image functions | - Back light compensation: On/Off;
- noise reduction: On/Off;
- image stabilization: On/Off;
- defog: On/Off
EO camera. |
|---|
| Thermal lens and coating | Focal length: 19mm; coating film: DLCIR thermal imager. |
|---|
| Thermal field of view | - Horizontal: 22.9°;
- vertical: 18.4°;
- diagonal: 29.0°
IR thermal imager. |
|---|
| Human detection, recognition and verification distances | - Detection: 792 meters;
- recognition: 198 meters;
- verification: 99 meters
Human target: 1.8×0.5m. |
|---|
| Car detection, recognition and verification distances | - Detection: 2428 meters;
- recognition: 607 meters;
- verification: 303 meters
Car target: 4.2×1.8m. |
|---|
| Thermal detector construction | Uncooled VOx long wave (8μm~14μm) thermal imager; detector: 640*512; pixel size: 12μm; athermal prime lensIR thermal imager. |
|---|
| NETD | ≤50mK@F1.0 @25 °CIR thermal imager; F1.0 at 25 °C. |
|---|
| Thermal palettes and digital zoom | White hot, black hot, pseudo color; digital zoom: 1x ~ 8xIR thermal imager. |
|---|
| AI target detection | - Targets: car and human;
- simultaneous detection: ≥ 10 targets;
- minimum contrast ratio: 5%;
- minimum target size: 5×5 pixel;
- car detection rate: ≥85%;
- false alarm rate: ≤10%
EO camera AI detection; minimum contrast ratio 5%, minimum target size 5×5 pixel. |
|---|
| Dual video stream output | Optional EO and IR dual stream output; recording is unavailable while dual video stream output is activatedOptional EO and IR dual video stream output activated. |
|---|
| Video switching and flight-controller support | ArduPilot / PX4 support through Mavlink protocol; optional Ardupilot Follow me feature; video switching: EO+IR /IR+EO /EO /IROptional Ardupilot Follow me feature. |
|---|