Product overview
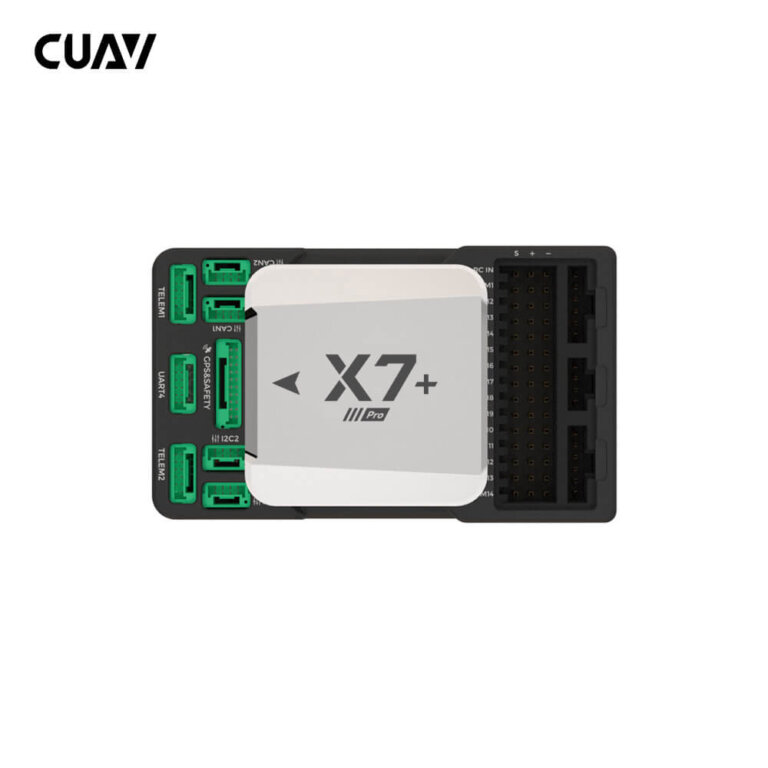
The CUAV X7+ Pro Flight Controller is an industrial unmanned-system controller from CUAV Tech Inc., Ltd. It combines an STM32H743 processor running at up to 480 MHz with an ADIS16470 inertial sensor and an RM3100 industrial magnetometer for attitude estimation and magnetic heading sensing. Three IMU groups support automatic switching following a sensor fault, complemented by temperature compensation and vibration damping. Its modular design supports customized carrier boards for integration into civilian unmanned aircraft, ground vehicles and boats.
The X7+ Pro supports ArduPilot and PX4 firmware. Under PX4, supported platforms include multicopters, airplanes, rovers and boats controllable with normal RC servos or Futaba S-Bus servos. Connections include five UART ports, two CAN buses and 14 PWM outputs, with 12 supporting DShot. Power A provides an analog power-monitoring connection, while Power C connects a CAN current monitor. Ethernet access is available through a serial-port connection using PPP, a PPP-to-Ethernet adapter or a custom firmware build.
The controller weighs 103 g and operates at temperatures from -20 to 85°C and humidity from 5% to 95% under non-condensing conditions. Its PM supply input requires 4.5–5.5 V, while USB power requires 4.75–5.25 V. Wiring follows the Pixhawk pin standard, with pin definitions that differ from those of the Pixhack series. Original wiring is recommended, with the green connector attached to the controller, making the pin-standard distinction relevant when installing it in an existing vehicle.
Specifications
| Specification | Value & conditions |
|---|---|
| Firmware | PX4Support for the CUAV X7 series. |
| Supported platforms | Multicopter, airplane, rover or boatMust be controllable with normal RC servos or Futaba S-Bus servos. |
| Product identity and application | CUAV X7+ Pro industrial controllerDeveloped for industry and industrial applications. |
| Attitude estimation hardware | STM32H7 processor, ADIS16470 inertial sensor and RM3100 magnetometerDescribed in the X7+ Pro introduction. |
| IMU redundancy | Three IMU groups with intelligent fault switchingListed controller feature. |
| Carrier board design | Modular design supporting customized carrier boardsCustomization applies to the carrier board. |
| Wiring requirement | Pixhawk pin standard; original wiring recommendedPin definitions differ from the Pixhack series. The green connector connects to the controller. |
| Operating temperature | -20 ~ 85°cSpecified operating environment. |
| Operating humidity | 5%~95%Non-condensing. |
| Ethernet access | Serial-port connectionUsing PPP, a PPP-to-Ethernet adapter or a custom firmware build |
Request a quote for CUAV X7+ Pro Flight Controller
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.