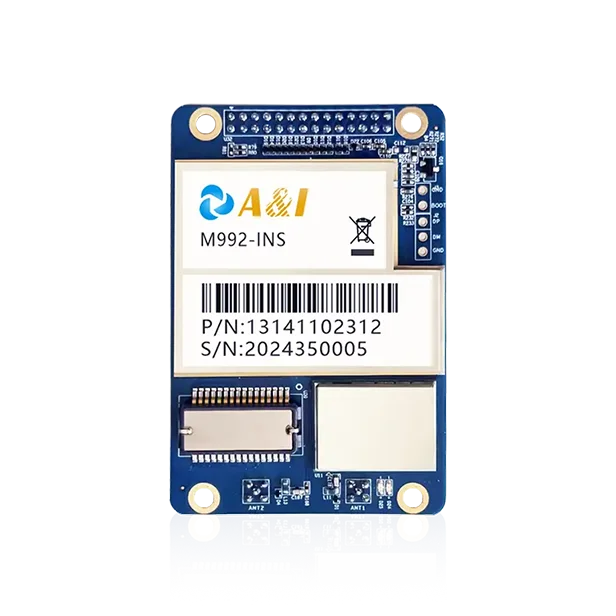
| Product | Archimedes Innovation A&I M992-INS dual-antenna tightly coupled GNSS/INS positioning board. |
|---|
| Applications | Autonomous driving vehicles, port and mining automation, hydrographic surveying, marine robotics, and aerial mapping and inspection. |
|---|
| Calibration and configuration | An internally developed algorithm engine eliminates complex lever arm measurements for plug-and-play calibration. |
|---|
| External support and web interface | Supports external high-performance IMU devices and L-band satellite-based augmentation signals; an embedded web interface provides module querying and configuration. |
|---|
| GPS | L1 C/A, L5, L2C |
|---|
| Galileo | E1, E5a, E5b |
|---|
| GLONASS | G1* |
|---|
| QZSS | L1 C/A, L2C, L5 |
|---|
| NavIC | L5* |
|---|
| SBAS | L1* |
|---|
| DGPS positioning accuracy | Vertical 0.4m; Elevation 0.8mPositioning accuracy (1ρ). |
|---|
| RTK positioning accuracy | Vertical 0.8cm + 1ppm; Elevation 1.5cm+1ppmPositioning accuracy (1ρ). |
|---|
| Gyroscope bias repeatability | 0.5 °/sGyroscope. |
|---|
| Gyroscope bias instability | 1.8 °/s (XY); 1.5 °/s (Z)Gyroscope; XY and Z axes respectively. |
|---|
| Gyroscope angle random walk | 0.09 °/√h (XY); 0.10 °/√h (Z)Gyroscope; XY and Z axes respectively. |
|---|
| Accelerometer bias repeatability | 20 mgAccelerometer. |
|---|
| Accelerometer bias instability | 15 μgAccelerometer. |
|---|
| Accelerometer angle random walk | 0.035 m/s/ √ hAccelerometer. |
|---|
| Additional GNSS bands | BDS: B1I, B1C, B2I, B2a, B2b*; Lband* |
|---|
| Single-point positioning accuracy | Vertical 1.5m; Elevation 2.5mPositioning accuracy (1ρ); single-point positioning. |
|---|
| Velocity and directional accuracy | Velocity: 0.03m/s; directional: 0.1°/m baselineVelocity and directional accuracy (1ρ); directional accuracy per metre of baseline. |
|---|
| Timing accuracy | PPS ≤10ns; GPTP ≤1us; NTP ≤10msTiming accuracy by synchronization method. |
|---|
| Startup time | 30sCold start. |
|---|
| Output frequencies | - Dual-antenna GNSS observations: 10Hz (Max 20Hz);
- dual-antenna GNSS position and heading: 10Hz (Max 20Hz);
- INS raw observations: 200Hz (Max 1000Hz);
- INS fusion position: 200Hz (Max 1000Hz)
Dual-antenna GNSS observations and position/heading outputs; INS raw observations and fusion position outputs. |
|---|
| Dead reckoning accuracy | 0.2% (1km@3min)1km@3min. |
|---|
| Combined navigation modes | Single antenna, dual antenna, single point, floating, fixed, satellite base* |
|---|
| IMU measurement ranges | Gyroscope: ±300 °/s; accelerometer: ±6gGyroscope and accelerometer respectively. |
|---|
| Communications interfaces | - RS232: 3;
- RS422: 1;
- CAN: 2;
- Ethernet: 1;
- 1PPS: 1
|
|---|
| Dimensions and weight | 71L × 45W × 10H mm; 24g |
|---|
| Environmental specifications | - Operating temperature: -40°C to +85°C;
- storage temperature: -55°C to +95°C;
- humidity: 95% non-condensing;
- operational shock: EP455 Section5.14.1;
- random vibration: EP455 Section5.15.1
Humidity: non-condensing; shock: operational; vibration: random. |
|---|