ChinaDroneRequest a quote →
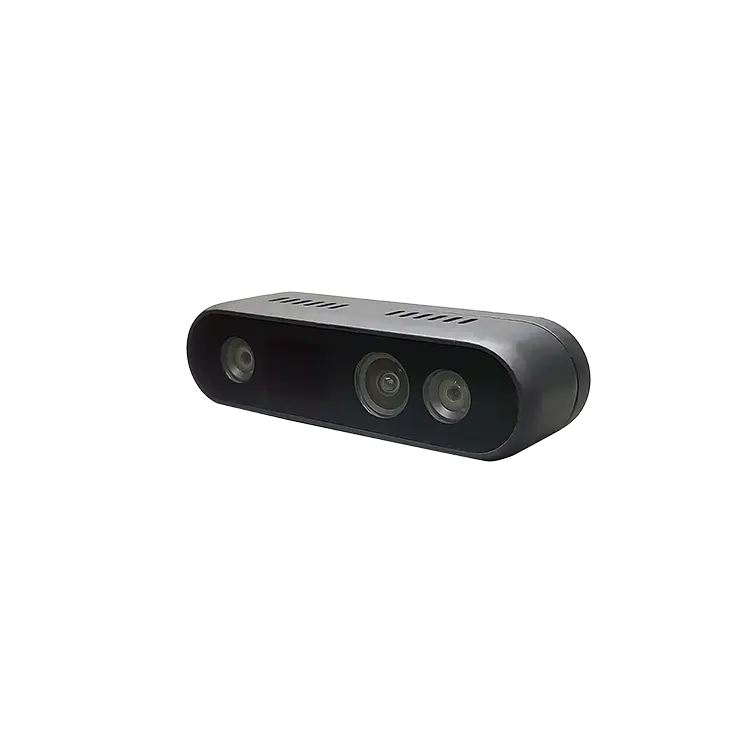
Archimedes Innovation ACA302 Stereo Depth Camera module in a black housingArchimedes Innovation ACA302 Stereo Depth Camera module in a black housing

ACA302 Stereo Depth Camera

The Archimedes Innovation ACA302 Stereo Depth Camera is an active stereo structured-light camera module for 3D imaging, obstacle avoidance and navigation. It integrates infrared and RGB sensors, an infrared speckle projector and a six-axis IMU, with USB 3.0 Type-C connectivity and hardware frame synchronization.

Applications
Obstacle avoidance and navigation for robots, AGVs, AMRs and drones
Dimensions
90.75 mm X 25 mm X 30 mm

Get a free quote

Product overview

The Archimedes Innovation ACA302 Stereo Depth Camera uses active stereo structured light to produce 3D images for obstacle avoidance and navigation in robots, AGVs, AMRs and drones. Its integrated assembly combines two infrared image sensors, one RGB image sensor, an infrared speckle projector and an IMU. Passive stereo operation is also supported. A 54.5mm baseline accompanies a recommended working distance of 0.25m–5m, a 0.25m blind zone and a maximum working distance of 25m with depth calculation. Accuracy is ≤2% at 2m.

The ACA302 delivers image data at up to 1280×800 at 30fps. Both infrared and RGB imaging use global shutters, while the 850nm speckle projector supports its structured-light imaging. The six-axis IMU combines a three-axis accelerometer and three-axis gyroscope and supports 3D positioning data. Hardware frame synchronization and a USB 3.0 Type-C interface support integration. Measuring 90.75mm × 25mm × 30mm, the camera has an IP54 protection rating and operates from -20°C to 50°C. Average power consumption is below 3.2W at 640x400p30.
Cameras & sensors

Specifications

ACA302 Stereo Depth Camera specifications
SpecificationValue & conditions
ProductArchimedes Innovation ACA302 Stereo Depth Camera
Imaging technologyDepth camera module using active stereo structured light for 3D imaging
Integrated componentsTwo IR image sensors, one RGB image sensor, one infrared speckle projector and one IMU
ApplicationsObstacle avoidance and navigation for robots, AGVs, AMRs and drones
Stereo modesActive Stereo; also supports Passive Stereo
Baseline54.5mm
Recommended working distance0.25m-5m
Maximum working distance25mSupports depth calculation.
Blind zone0.25m
Accuracy≤2%At 2m.
Field of viewH84° X V59°±3°Depth image.
Resolution and frame rate1280x800p15/30;1280x720p15/30;640x480p15/30;640x400p15/30;320x200p15/30Depth image.
Field of viewH84° X V59° ±3°IR image.
ShutterGlobal ShutterIR image.
Field of viewH94° X V66° ±3°RGB image.
ShutterGlobal ShutterRGB image.
Wavelength and pattern850nm speckleIR pattern projector.
IMU3-axis accelerometer and 3-axis gyroscope
IMU positioning support6-axis IMU supports 3D positioning data
SynchronizationHardware frame synchronization supported
Hardware interfaceUSB3.0 Type-C
Dimensions90.75mm X 25mm X 30mm
Average power consumptionLess than 3.2WAt 640x400p30.
Operating temperature-20–50°C
Storage temperature-30–70°C
Protection ratingIP54
Data formats
  • Depth: Z(16bit);
  • IR: Y(8bit);
  • RGB: NV12;
  • IMU: X[16 bits], Y[16 bits], Z[16 bits]
Maximum image output1280×800@30fps

Related guides