Product overview
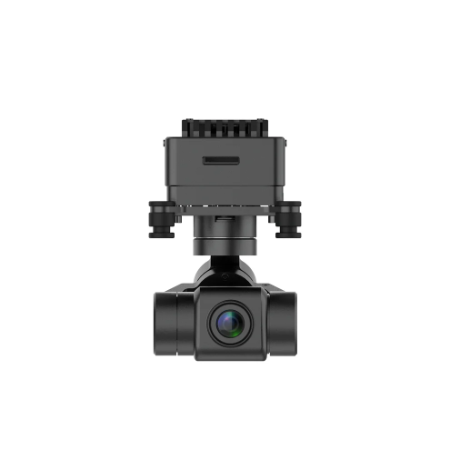
The ALLXF C-200T provides pitch, roll and yaw movement around a camera payload, with a maximum load of 200g. Camera integration requires a compact bracket assembly tightly connected to the pitch motor. Its exposed pitch-motor wiring leaves access for routing camera cables. Mechanical balancing uses the payload mounting position, counterweights and movable extension plates; after pitch balancing, four M2 countersunk screws secure the payload. The roll extension plate position changes according to whether the payload is lighter or heavier.
Balancing is mandatory at first use, after replacing the payload and whenever counterweights are added or removed. A balanced payload must hold its position without drooping or drifting, and the complete assembly needs a final balance check across all three axes. Factory parameters are calibrated with a payload installed and its center of gravity balanced. Unloaded shaking can occur because low rotational inertia promotes high-frequency oscillation; prolonged powered operation without a payload can burn out the pitch motor.
Specifications
| Specification | Value & conditions |
|---|---|
| Maximum payload | 200g |
| Required balancing | Balance the gimbal before use under these conditions.First use, payload replacement, or addition or removal of counterweights. |
| Camera mounting structure | The camera bracket must form a compact assembly with a tight connection to the pitch motor.Before balancing. |
| Payload fastening | Secure the payload with four M2 countersunk screws.After balancing the pitch axis. |
| Pitch adjustment and balance criterion | Adjust the payload mounting position or add or remove counterweights until the payload remains stationary at any position without drooping.During pitch-axis balancing. |
| Roll adjustment | Move the extension plate to increase balancing travel. For lighter payloads, place the section farther from the pitch axis in the slot; for heavier payloads, use the section nearer the pitch axis.During roll-axis balancing. |
| Roll balance criterion | The payload should remain stable at any angle without rotating or drifting by itself.After rotating the roll axis. |
| Yaw adjustment and balance criterion | Orient the power and communication interfaces upward and move the extension plate. After yaw rotation, the complete gimbal should remain stationary without spontaneous rotation or displacement.During yaw-axis balancing. |
| Final balance check | Check the overall balance again.After balancing all three axes. |
| Factory calibration configuration | Factory parameters are calibrated with a balanced payload.With a payload installed and its center of gravity balanced. |
| Unloaded-operation limitation | Unloaded shaking is normal; low rotational inertia can cause high-frequency oscillation. Prolonged powered operation without a payload can burn out the pitch motor.Powered operation without a payload. |
| Camera cable routing | Exposed pitch-motor wiring facilitates routing camera cables. |
| Imbalance effects | An unbalanced payload can cause image shake and abnormal noise.With an unbalanced payload. |
Request a quote for ALLXF C-200T
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.