Product overview
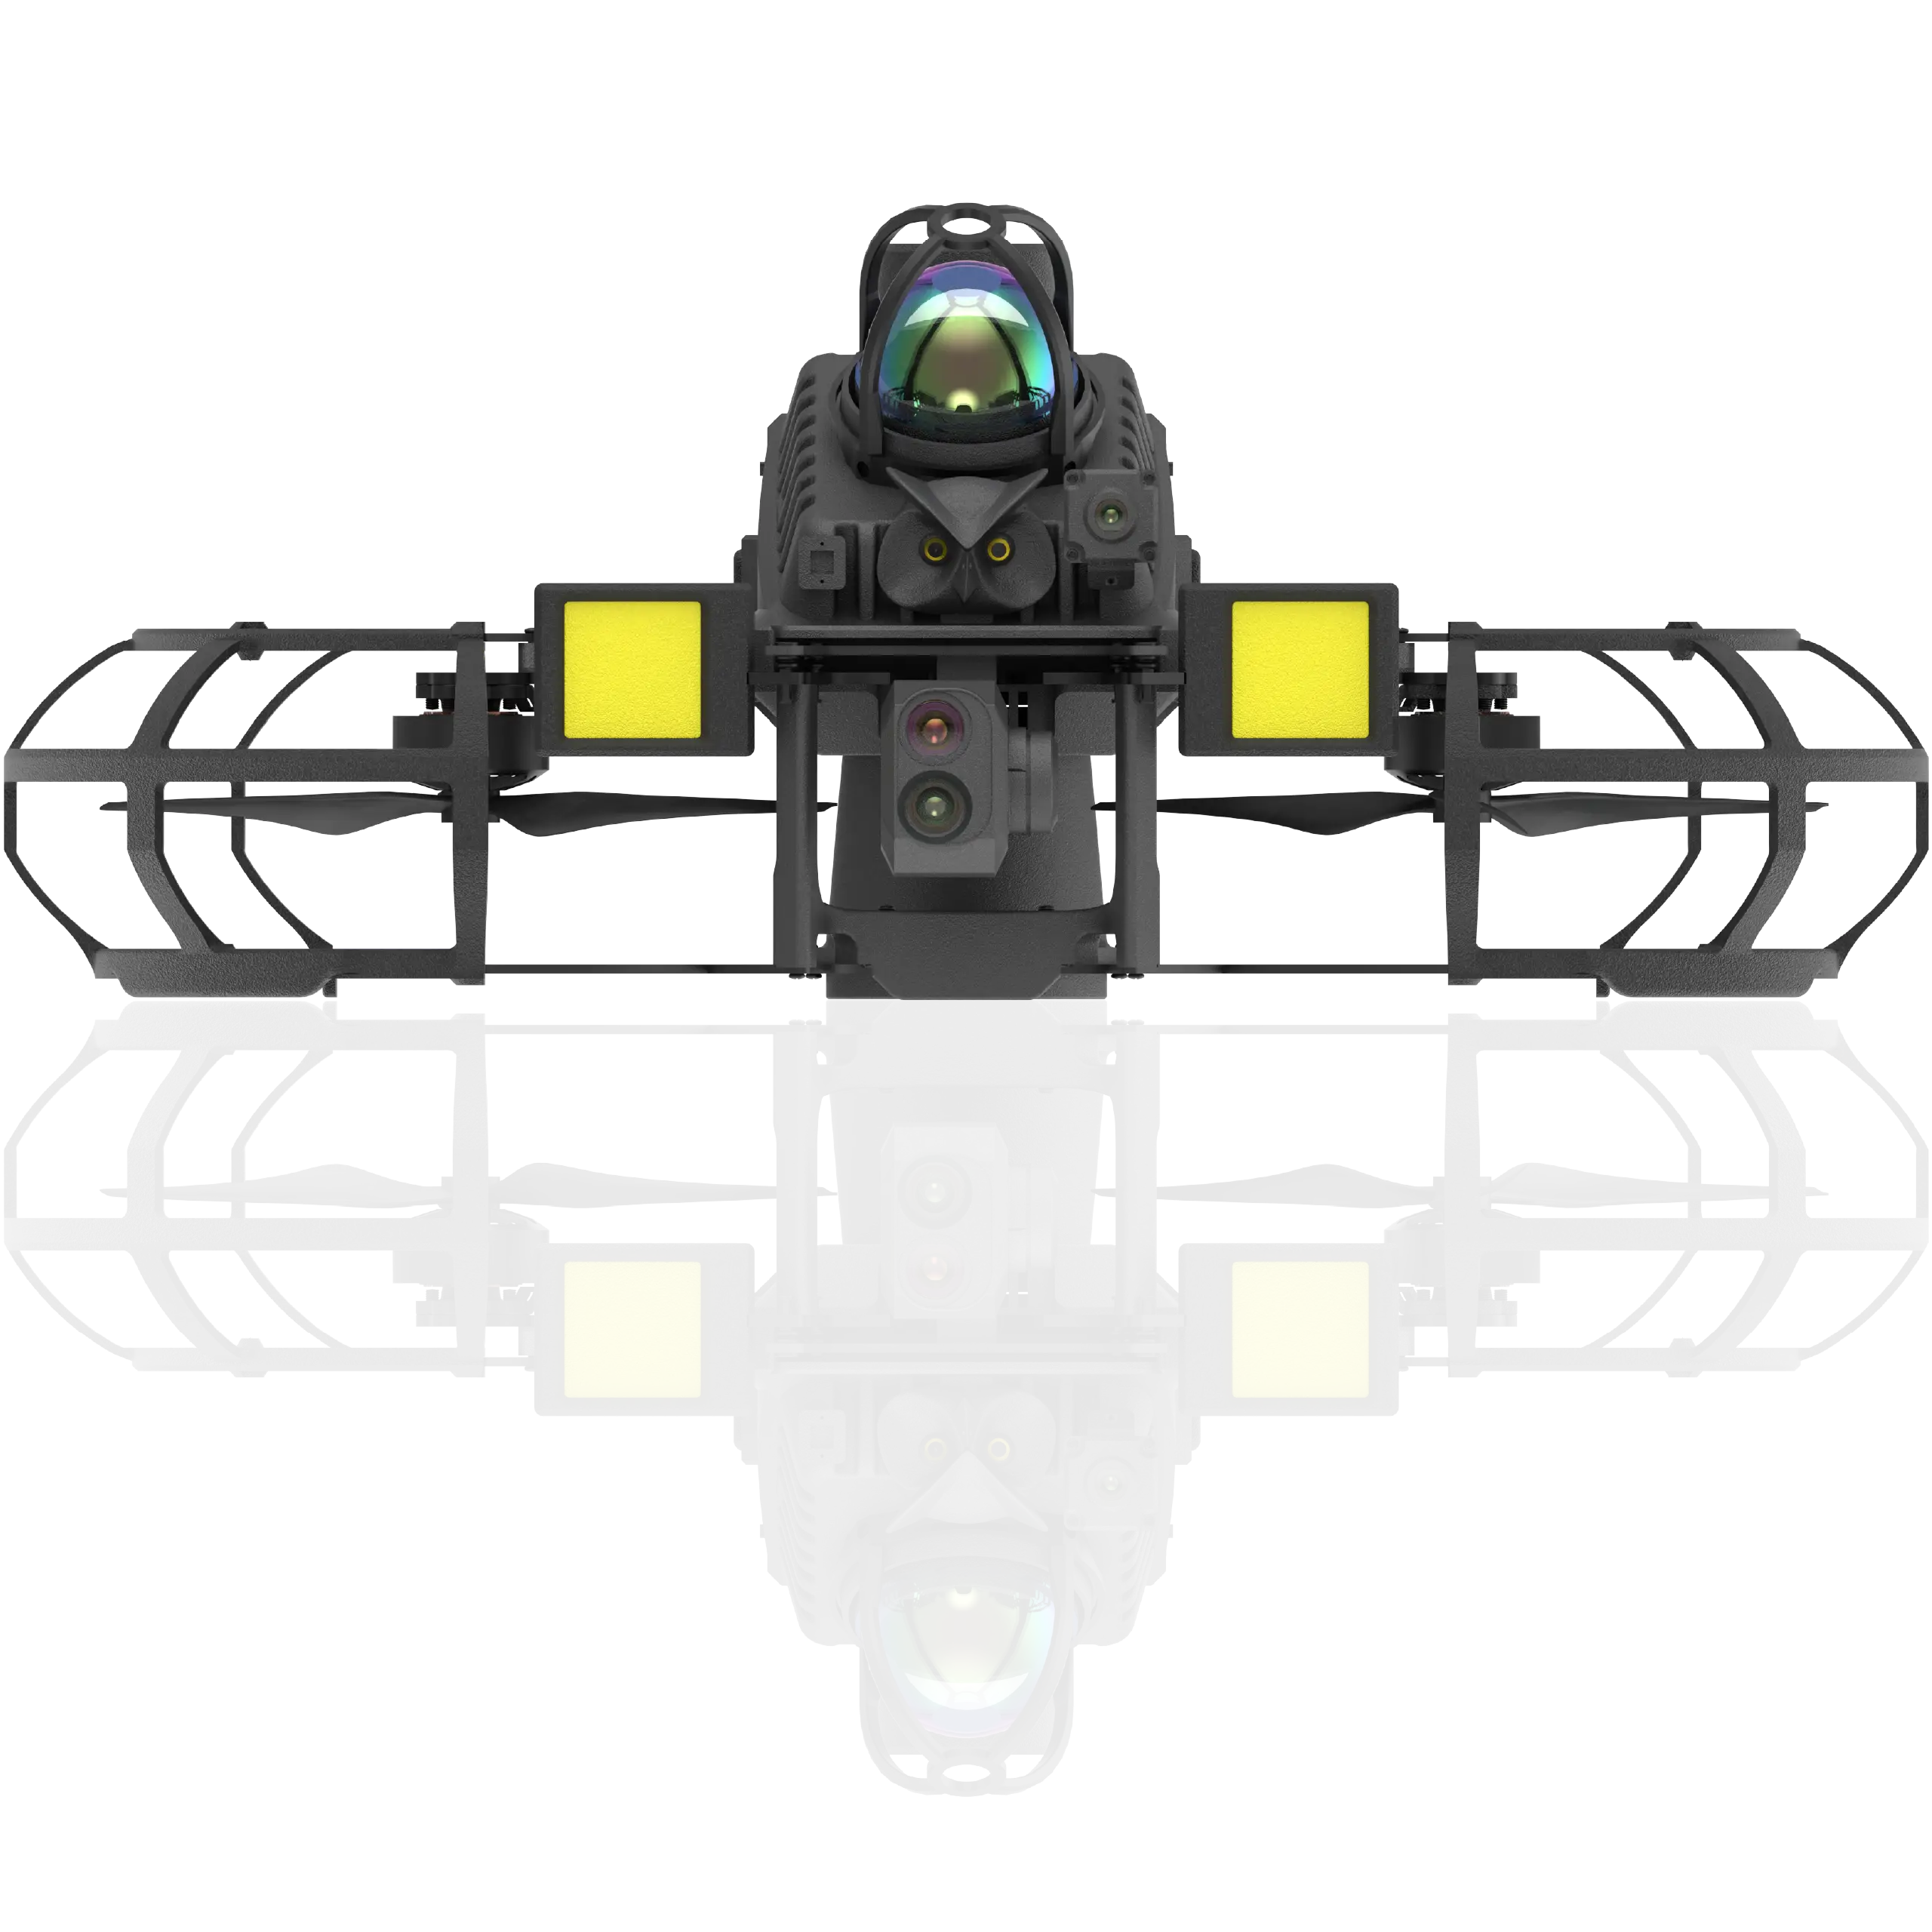
Beijing VISBOT Technology Co., Ltd. positions Tyto alba for inspection in enclosed, complex spaces, including narrow passages and dense steel structures. Its compact, lightweight body provides full protection, while multiple sensing modalities support operation where positioning, communications or illumination are absent. Omnidirectional lidar and a forward global camera form a tightly coupled LIVO positioning system. An additional system fuses iToF array lidar with the downward camera, providing primary and backup positioning with seamless switching and centimeter-level positioning accuracy.
The equipped platform combines a two-axis, dual-spectrum stabilized gimbal with visible-light and infrared cameras, plus multi-angle supplemental lighting for inspection imaging. Ultrasonic sensing addresses water and glass misidentification, with an approximately 4 m detection range. The accompanying configuration includes an autonomous charging dock, ground station terminal and remote controller. Operators can use autonomous exploration, point-directed operation or remote control. An open SDK exposes images, point clouds and pose data for development; image transmission is specified at 3.5 km with a maximum bandwidth of 14 Mbps.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity | Beijing VISBOT Technology Co., Ltd. Tyto alba |
| Body architecture | Compact, lightweight, fully protected body |
| Multimodal sensing | Multimodal sensor fusion supports stable operationIn enclosed, complex spaces without positioning, communication or light; with a single sensor failure. |
| Omnidirectional lidar output | Point cloud |
| Forward global camera resolution | 1280 × 1024 |
| Forward global camera output | Grayscale images |
| iToF array lidar resolution | 640 × 480 |
| iToF array lidar output | Depth images |
| Downward camera resolution | 1280 × 1024 |
| Downward camera output | RGB / grayscale images |
| LIVO positioning | Tightly coupled LIVO positioning through sensor fusionUsing omnidirectional lidar and the forward global camera. |
| Positioning redundancy | Primary and backup positioning systems with seamless switchingUsing iToF array lidar and the downward camera alongside LIVO. |
| Ultrasonic detection range | Approximately 4 m |
| Ultrasonic sensing role | Addresses water-surface and glass misidentificationFor water surfaces and glass that vision and lidar can misidentify. |
| Inspection gimbal | Two-axis, dual-spectrum stabilized gimbal |
| Visible-light camera acquisition | 3840 × 2160 @ 30 fps |
| Infrared camera acquisition | 256 × 192 @ 25 fps |
| Supplemental lighting | Multi-angle, high-brightness supplemental lights |
| Charging equipment | Accompanying autonomous charging dock |
| Positioning accuracy | Centimeter-level |
| Image transmission distance | 3.5 km |
| Maximum image transmission bandwidth | 14 Mbps |
| Control modes | Autonomous exploration, point-directed operation and remote control |
| Operator equipment | High-performance ground station terminal and remote controller |
| Developer interface | Open SDK providing access to images, point clouds and pose data |