Product overview
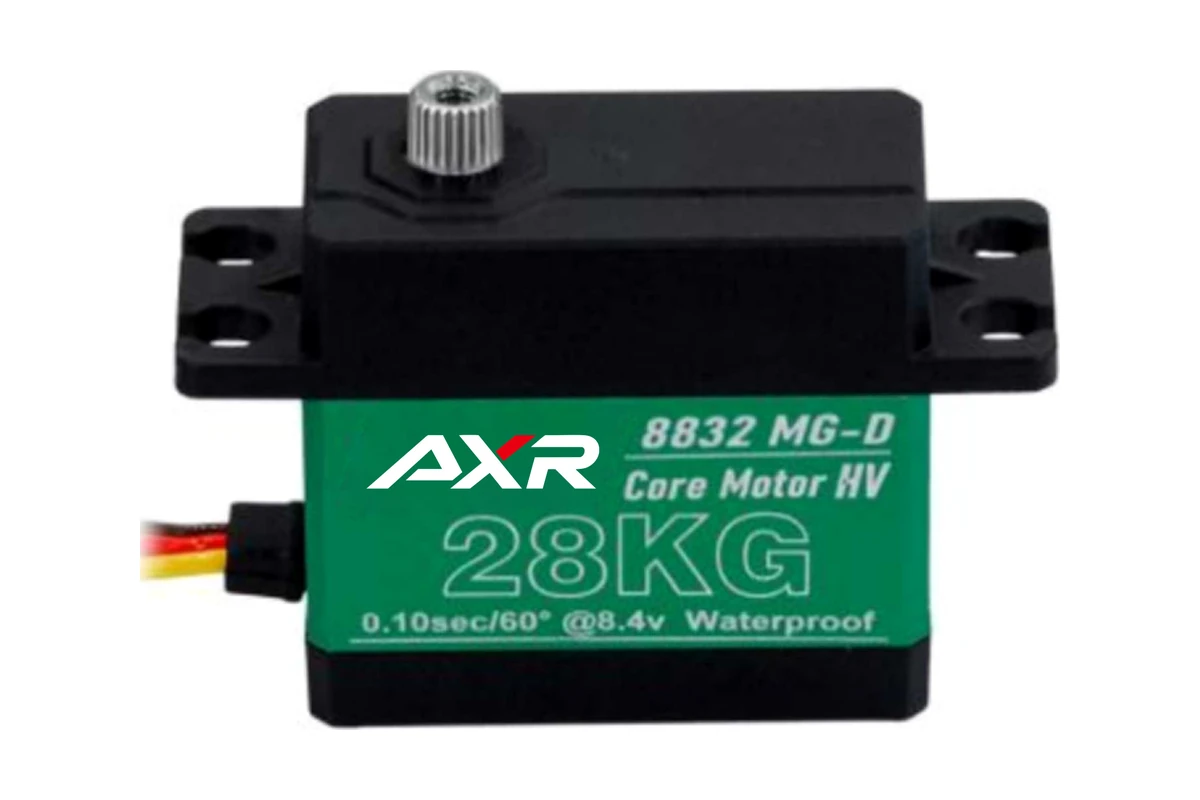
The Zhuhai SV Tech Co., Ltd. AXR 8832 MG-D is a standard servo for model steering, control-surface movement and mechanical actuation. Its configuration combines an iron-core motor, stainless steel gears and two bearings in a 40 × 20 × 36.6 mm body weighing 60 g. A 300 mm cable provides connection reach within the installation. Integration requires matching the supply, PWM signal, mounting-hole positions and servo-arm connection, with the final mounting drawing and interface version checked before mounting parts are fabricated.
The servo accepts 4.8–8.4 V and uses PWM control at 333 Hz. At 8.4 V, stall torque is 28 kg·cm, no-load speed is 0.101 s/60°, and rated torque is 8 kg·cm; stall torque must not be used as a continuous-load rating. The 1520 µs reference pulse differs from the stated 1500 µs position midpoint, so neutral and usable travel depend on the controller and delivered version. Initial setup calls for removed or limited load, while the power supply needs headroom for transient current.
Specifications
| Specification | Value & conditions |
|---|---|
| Product | AXR 8832 MG-D standard servo for model steering, control surfaces and mechanical actuation |
| Operating voltage | 4.8–8.4 V |
| Performance at 6 V |
|
| Performance at 7.4 V |
|
| Performance at 8.4 V |
|
| Rated torque | 8 kg·cm @ 8.4 V8.4 V. |
| Overall dimensions | 40 × 20 × 36.6 mm |
| Weight | 60 g |
| Motor type | Iron-core motor |
| Gear material | Stainless steel gears |
| Bearing count | 2 |
| Cable length | 300 mm |
| Control signal | PWM |
| Operating frequency | 333 Hz |
| Reference pulse width | 1520 µs |
| Pulse width and corresponding angle | 500 / 1500 / 2500 µs → -90 / 0 / 90° |
| Continuous-load limitation | Stall torque cannot be treated as a continuous-load rating; continuous-duty selection must also account for rated torque and duty cycle. |
| Supply-range qualification | The voltage range defines the permitted supply range. |
| Neutral position and travel qualification | The reference pulse is 1520 µs while the position midpoint is 1500 µs; neutral position and usable travel require confirmation with the controller and delivered version.Controller and delivered servo version. |
| Mounting qualification | Drawings and tabulated dimensions may use different reference points; confirm the final mounting drawing and interface version before fabricating mounting parts.Final mounting drawing and interface version. |
| Integration requirements | Check power, signal pulse width, mounting holes and servo-arm connection. Establish neutral position, movement direction and mechanical travel before progressively applying the working load.Initial setup with the load removed or limited. |
| Power and mechanical precautions | Provide supply headroom for transient current and avoid cable voltage drop, reversed connections and sustained loading against mechanical stops. |