Product overview
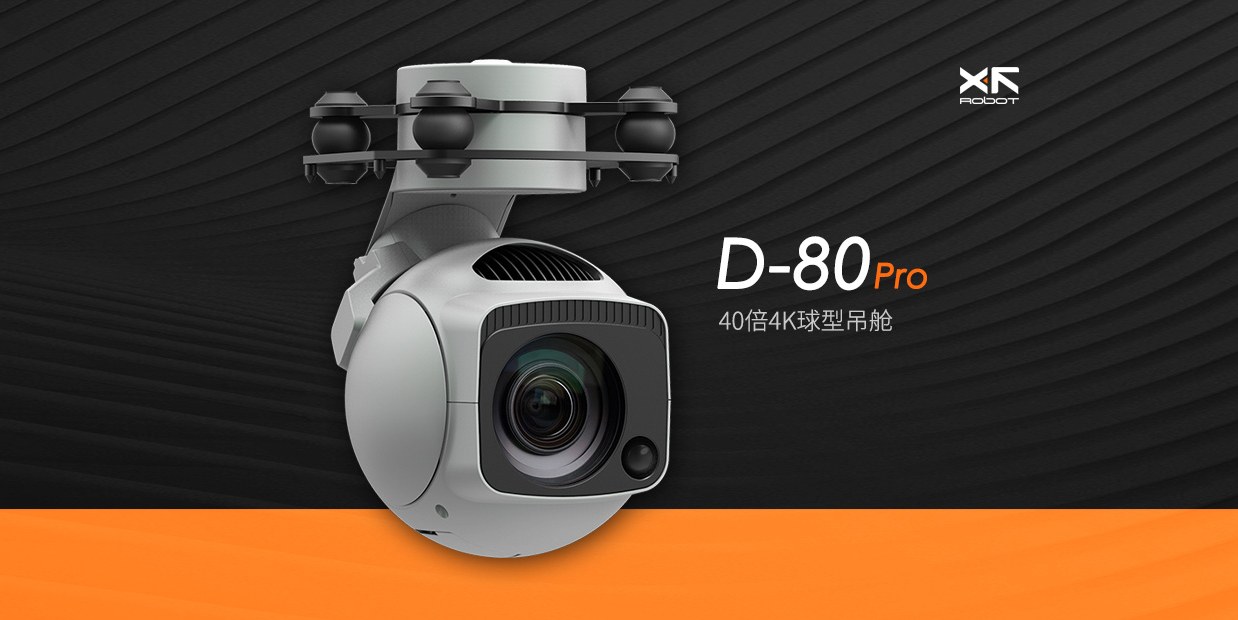
The ALLXF D-80Pro combines an 8.29-megapixel camera with 40× hybrid zoom, 4K recording at 30 fps and 3840 × 2160 still photography. Its intended work includes broad-area searching and closer examination of distant details, such as instrument readings during industrial inspections. A built-in laser illumination module supplies camera lighting in dark or completely unlit spaces. The hardware is a carrier-mounted imaging payload: its compact spherical body measures 80 mm in diameter, and the complete gimbal weighs 405 g.
The non-orthogonal three-axis mechanism uses dual-IMU processing, IMU temperature control and carrier inertial-navigation data fusion, with stabilization accuracy of ±0.01°. Continuous yaw rotation supports repeated full turns, while upright and inverted mounting provide installation flexibility. Detection covers pedestrians and vehicles, with tracking of image-selected targets. Control options include network, serial and S.BUS, alongside proprietary and MAVLink protocols. The GCU and Dragonfly software workflow provides live viewing, split-screen display and recording, with up to 16 devices managed from one terminal; these functions are described for that combined configuration.
Specifications
| Specification | Value & conditions |
|---|---|
| Manufacturer and model | ALLXF D-80Pro spherical electro-optical gimbal payload |
| Intended applications | Visual sensing for multirotor UAV security patrol, emergency rescue and industrial inspection |
| Camera pixel count | 8.29 megapixels |
| Camera zoom | 40× hybrid zoom |
| Video recording | 4K/30 fps |
| Still-image resolution | 3840 × 2160 |
| Integrated illumination | Built-in laser illumination moduleFor camera illumination in low-light or completely unlit environments. |
| Housing architecture | Compact, fully spherical housing |
| Sphere diameter | 80 mm |
| Weight | 405 gComplete gimbal unit. |
| Mounting orientations | Upright and inverted |
| Deployment and carrier types | Deployment without additional tools to carrier types including UAVs, RC vehicles and robotic dogs |
| Mechanical stabilization | Non-orthogonal three-axis mechanically stabilized architecture |
| Stabilization processing | Dual-IMU complementary algorithm, IMU temperature control and fusion of carrier inertial-navigation data |
| Image stabilization accuracy | ±0.01° |
| Continuous rotation | 360° × N continuous rotationYaw axis. |
| Automatic target detection | Pedestrian and vehicle recognition and detection |
| Automatic target tracking | Continuous target lock and trackingTarget selected by drawing a box in the captured image. |
| Display and control functions | Real-time image display, matrix split-screen viewing, gimbal control, photography and video recording without protocol integrationUsed with a GCU and ALLXF Dragonfly display and control software. |
| Device management capacity | Up to 16 devices per terminalOne terminal using the GCU and Dragonfly software workflow. |
| Control interfaces | Network, serial and S.BUS control |
| Control protocols | Proprietary protocol and MAVLink |
| Flight-controller integration | Supports integration with PX4 and ArduPilot open-source flight-control systems |
| Command-platform integration protocols | ONVIF and GB/T28181 for command and dispatch platform integration |
Request a quote for ALLXF D-80Pro
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.