Product overview
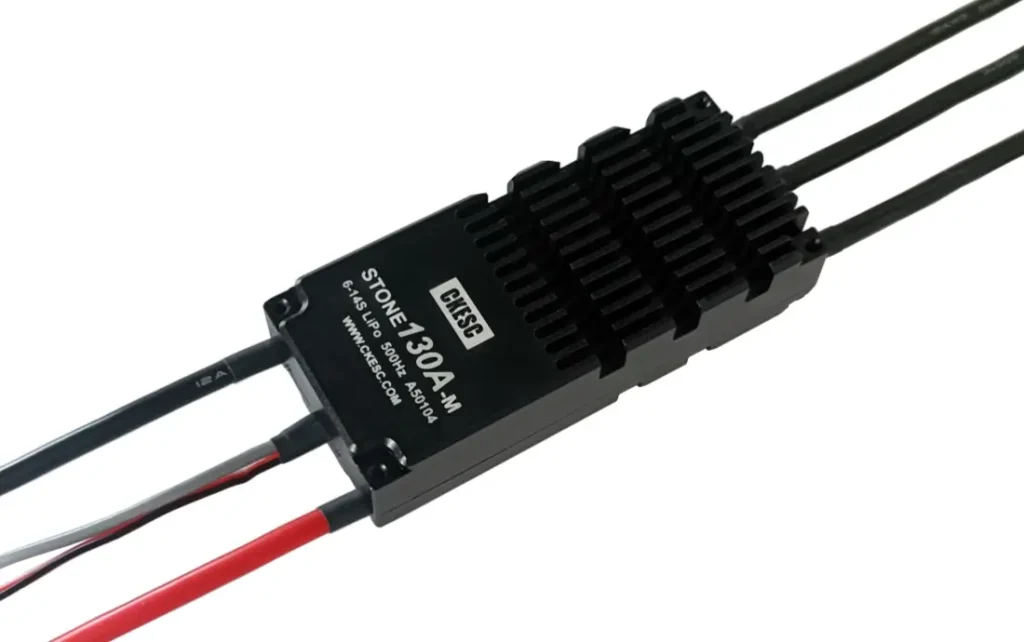
The CKESC STONE 130A-M from Nanchang Changkong Technology is a brushless electronic speed controller for UAV propulsion. Its wired assembly measures 92 × 40.4 × 20.9mm and weighs 155g including wiring, with separate power, three-phase motor, signal and feedback leads for integration. PWM control accepts 3.3~5V input signals, while serial output supplies real-time voltage, motor speed, current, ESC temperature and debugging data. Motor rotation direction can be set through software. Shielded signal wiring and optically isolated signal input and output interfaces reduce interference.
The 6~14S controller supports 80A continuous operation with specified cooling and 130A maximum operation for 3 seconds. It has no BEC. Standard protection is IP54, with IP67 available by customization. Timing-adjustment firmware is standard; a fixed version is optional, and maximum-power mode can be enabled. Low-voltage protection is disabled by default but can be enabled by customization. High-voltage protection inhibits startup when supply voltage exceeds the permitted value. Failed starts trigger current limiting and automatic retries, while excessive motor load limits maximum throttle.
Above 125°C, maximum output power gradually decreases, potentially reaching 40% of full-throttle power; original power returns after cooling. Signal loss lasting 200ms initiates output reduction: throttle falls below 50% within 1~2 seconds, then decreases slowly until shutdown. During a motor stall in normal operation, the controller attempts a restart, although a stall at high throttle may damage the ESC. Throttle integration uses a 1000~2000us pulse range, a 300ms response time and a 50~500Hz refresh rate, with 100~400Hz recommended.
Specifications
| Specification | Value & conditions |
|---|---|
| Model | CKESC STONE 130A-M |
| Specification designation | 130A 6~14S |
| Supply voltage | 6~14S |
| Dimensions | 92 × 40.4 × 20.9mm |
| Weight | 155gIncluding wiring. |
| Continuous operating current | 80AWith specified cooling. |
| Maximum operating current | 130AFor 3 seconds. |
| Standby consumption | ≤10mAAt 60V. |
| Throttle pulse range | 1000~2000us |
| Throttle response time | 300ms |
| Ingress protection | IP54IP67 available by customization. |
| Power leads | Silicone wire; red/black; 12AWG; 150mm |
| Three-phase leads | Silicone wire; black; 12AWG; 100mm |
| Signal cable | UL1533; 24AWG; gray; 550mm |
| Throttle refresh rate | 50~500HzRecommended refresh rate: 100~400Hz. |
| Data feedback cable | PVC ribbon cable; 30-core; black/red/white; 80mm |
| BEC | None |
| Input signal level | 3.3~5V |
| Temperature protection point | 125°C |
| Control communication | PWM |
| Overtemperature protection | Maximum output power gradually decreases, potentially to 40% of full-throttle power.Temperature exceeds 125°C; original power is restored after cooling. |
| Signal-loss protection | Output power decreases; throttle drops below 50% within 1~2 seconds, then decreases slowly until shutdown.After signal loss lasting 200ms. |
| Low-voltage protection | Disabled by defaultCan be enabled by customization. |
| High-voltage protection | Motor startup is inhibited.Supply voltage exceeds the permitted value. |
| Startup protection | Limits startup current and automatically retries startup.Motor startup fails. |
| Stall protection | Attempts to restart the motor.A stall occurs during normal operation; a stall at high throttle may damage the ESC. |
| Overcurrent protection | Limits peak current to prevent it exceeding the limit. |
| Overload protection | Limits maximum throttle to protect the propulsion system.Excessive motor load is detected. |
| Real-time telemetry | Supply voltage, motor speed, current, ESC temperature and debugging dataVia serial output. |
| Firmware configuration | Timing-adjustment firmware is standard; a fixed version is optional, and maximum-power mode can be enabled. |