Product overview
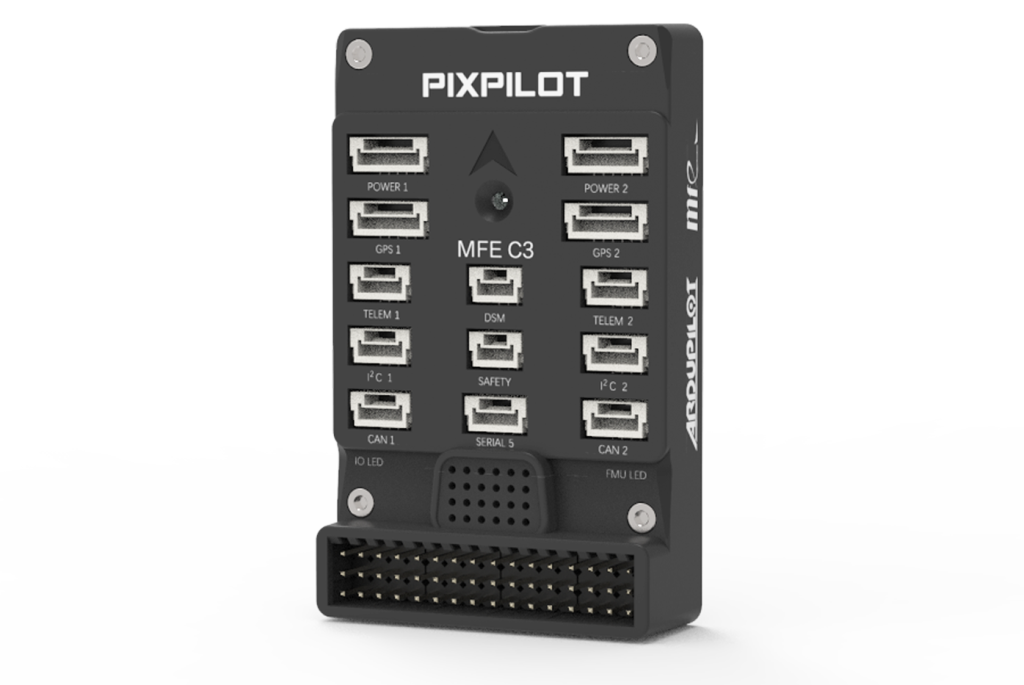
The makeflyeasy PixPilot C3 provides autopilot hardware for small fixed-wing aircraft, VTOL fixed-wing aircraft and multirotors. The controller measures 76 × 45 × 16 mm and weighs 37 g, with an engineering-plastic shell. Its internal architecture combines an STM32F427 main processor with an STM32F103 coprocessor, two ICM-42688-P acceleration and gyroscope sensors, and two BMP388 barometers. Pin rows and connectors use a three-dimensional arrangement, while the USB connection and memory-card access sit on top for installation access.
Integration connections comprise five UART, two I2C, two CAN, 8+6 PWM, one PPM/SBUS input, one SBUS output, two power connections, one USB Type-C and one TF-card slot. The controller supports paired PMU, GPS, compass, airspeed and digital transmission peripherals for redundant installations. MFE stable firmware is recommended for MFE aircraft and incorporates model defaults and PID parameters; accelerometer, compass, remote-control, battery-monitor and ESC calibration precede flight testing. Other aircraft require official ArduPilot firmware for the time being. Operating temperature is -10 °C to 55 °C.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity | Makeflyeasy PixPilot C3 flight control system |
| Intended aircraft types | Small fixed-wing, vertical take-off and landing fixed-wing, and multirotor autopilot systems |
| Processor architecture | Dual processors for flight-control safety redundancy and peripheral expansion |
| Impact resistance | Impact-resistant design intended to accommodate high landing loadsParachute-recovered fixed-wing aircraft with high landing loads. |
| Signal voltage switching | Signal voltage switching to improve rudder and ESC signal interference resistanceComplex electromagnetic environments. |
| Interface arrangement | Three-dimensional pin-row and connector arrangement, with USB and memory-card access on top |
| Peripheral redundancy support | Supports dual sets of PMU, GPS, compass, airspeed meter and digital transmission peripherals for a dual-redundant autopilot systemUsing two sets of the listed peripherals. |
| MFE firmware configuration | Recommended MFE stable firmware incorporates PID parameters and default configurations for MFE aircraftMFE aircraft using MFE stable firmware. |
| Required calibration | Calibrate the accelerometer, compass, remote control, battery monitor and ESC before flight testingMFE aircraft using MFE stable firmware, before flight testing. |
| Other-aircraft firmware guidance | Use official ArduPilot firmware for the time beingAircraft other than MFE models. |
| Main processor | STM32F427 (32 Bit Arm Cortex-M4, 180Mhz, 2M Flash, 256K RAM) |
| Coprocessor | STM32F103 (32 Bit Arm Cortex-M3, 72Mhz, 64K Flash, 20K RAM) |
| Acceleration and gyroscope sensors | ICM-42688-P × 2 |
| Barometers | BMP388 × 2 |
| UART | 5 |
| I2C | 2 |
| CAN | 2 |
| PWM | 8+6 |
| PPM/SBUS input | 1 |
| SBUS output | 1 |
| Power connections | 2 |
| USB Type-C | 1 |
| TF-card slot | 1 |
| Shell material | Engineering plastics |
| Temperature range | -10 °C to 55 °COperating temperature. |
| Dimensions | 76 × 45 × 16 mm |
| Weight | 37 g |
Request a quote for PixPilot C3
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.