Product overview
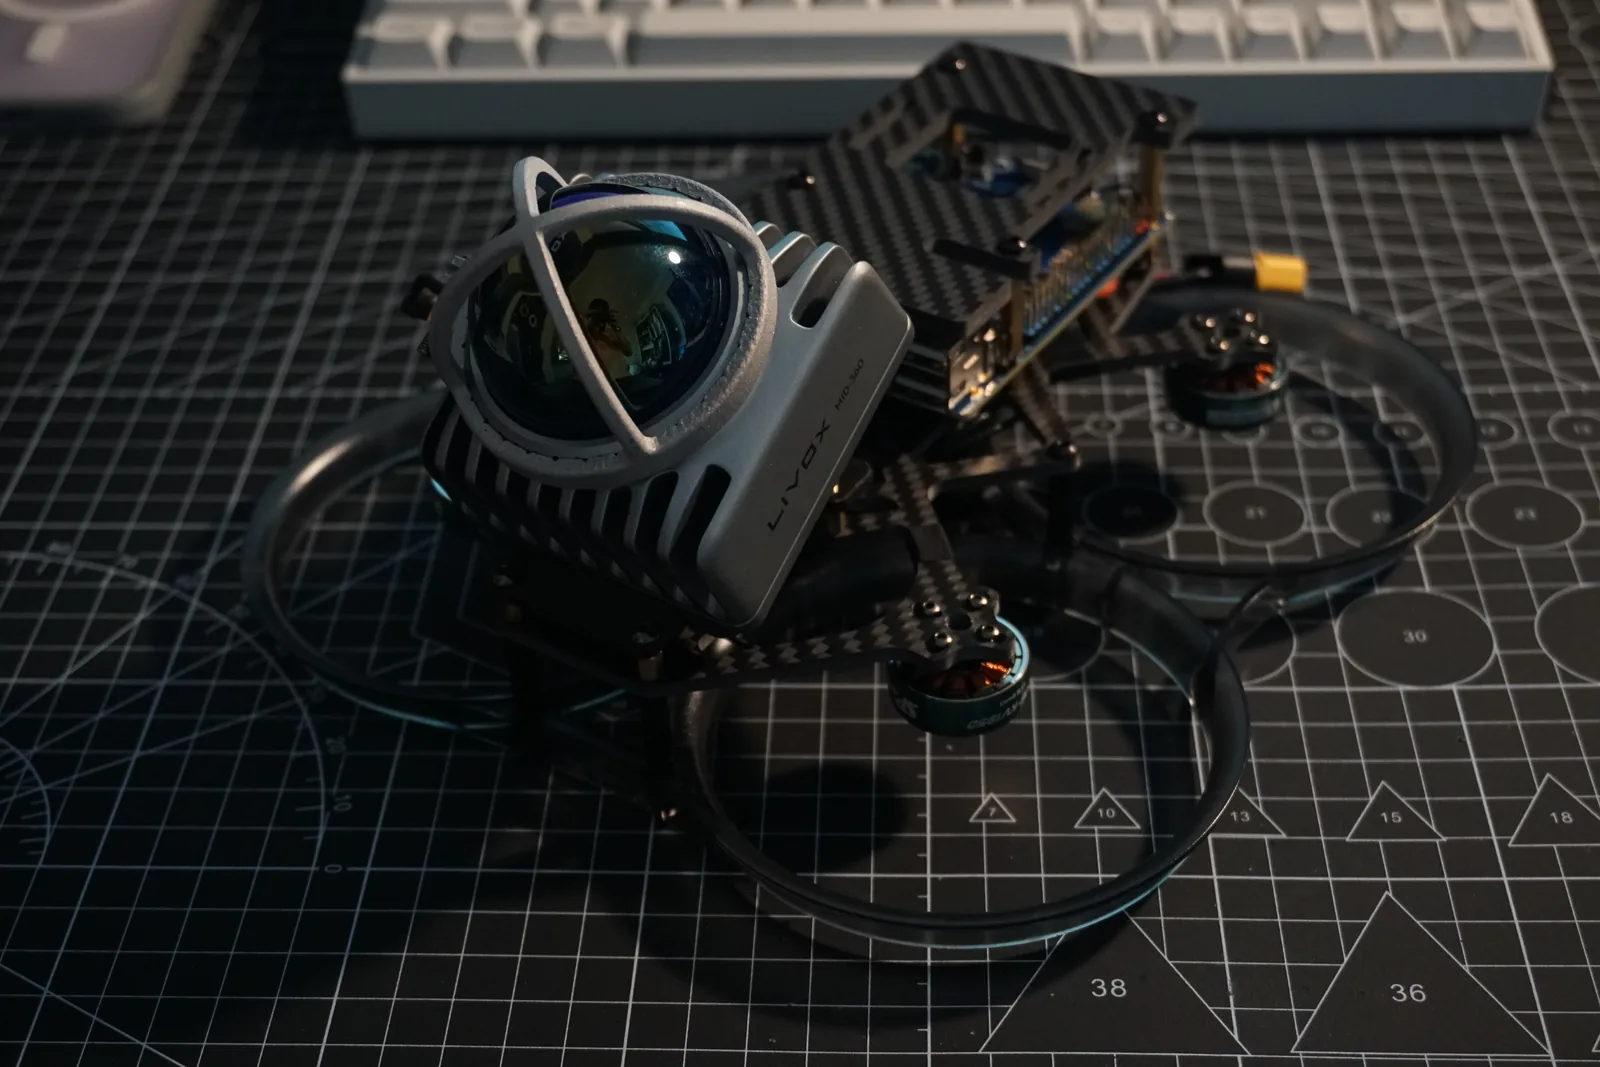
The FUNSKII Odysseus combines a 3.5-inch ducted quadcopter body with a front-mounted Livox Mid-360 LiDAR for autonomous navigation, mapping and perception research. Four circular ducts enclose the propellers around a 150 mm wheelbase. Its assembly comprises the frame and ducts, bottom plate, propulsion system, flight controller, onboard computer, cover plate, LiDAR bracket and wiring harness. Aircraft weight is 631 g without a battery, with a take-off weight of 1080 g including a battery and a recommended payload of up to 300 g.
A MOONPILOT H743/45A flight controller with an ICM42688P IMU runs PX4. The onboard computer is selected from Orange Pi 5 Pro, Jetson Orin Nano or Jetson Orin NX, with Ubuntu 20.04, ROS 1 Noetic and LiDAR localization and mapping software preinstalled. LiDAR-inertial odometry supports horizontal and vertical hover accuracy of ±0.03 m without GPS. UAV Stack ground-station software comes with source code and provides connection, mapping, flight control, waypoint missions and YOLO recognition.
Hover endurance is 12 minutes with the recommended 21700 6S1P battery pack. The battery, charger, remote controller, video transmission module and GPS are not included as standard. No camera is fitted; a camera can be added for individual projects.