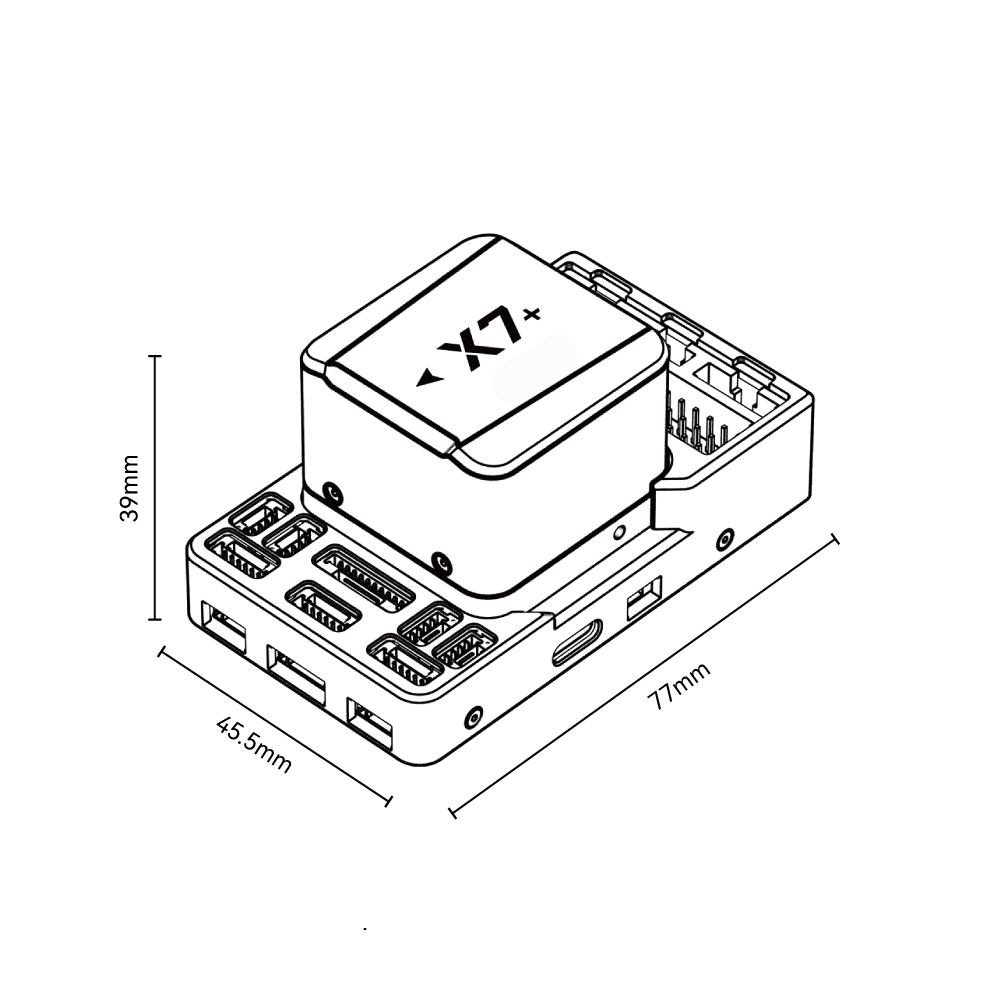
Product overview
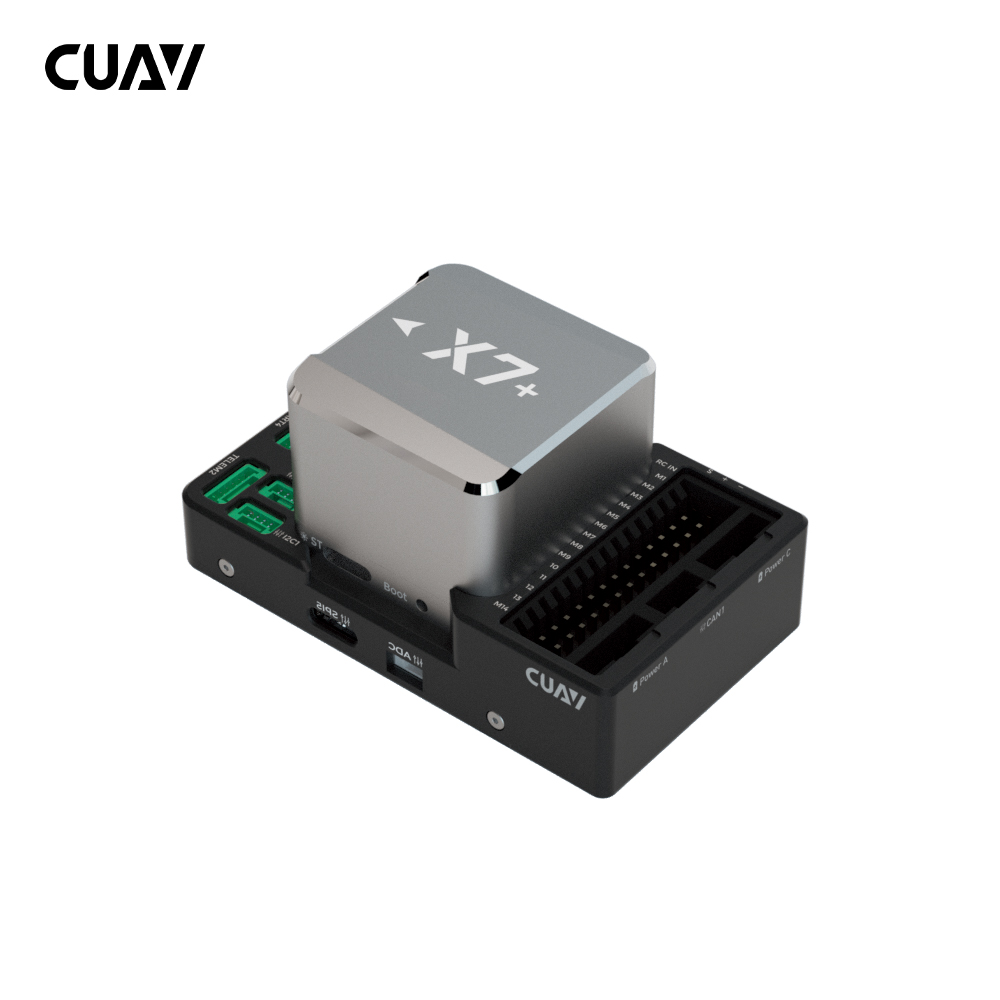
The CUAV X7+ Flight Controller is designed for academic research and commercial systems integration. Derived from the X7, it features revised sensors and optimized internal shock absorption, with a modular design that supports a custom carrier board. Its STM32H743 processor is paired with three IMU sensor sets: one ICM-42688-P and two ICM-20689 units. An RM3100 magnetometer and two MS5611 barometers complete the onboard sensor configuration. The controller supports IMU heating and temperature compensation, weighs 101 g and has an operating temperature range of -20 to 85 °C.
Peripheral connections include 14 PWM outputs, 12 of which support Dshot, plus RC inputs and analogue/PWM RSSI input. Two GPS connections use the GPS and UART4 ports. Six I2C buses comprise four independent interfaces and two integrated into the GPS and UART4 interfaces, alongside two CAN ports, one ADC input and one USB port. Firmware compatibility covers ArduPilot 4.1.0 or later and PX4 v1.12.3 or later. Ordinary GPS modules from other manufacturers may not be fully compatible; operation without GPS requires a safety switch connected directly to GPS1 to arm and fly.
Controller power must enter through POWERA or POWERC at 4.5–5.4 V, or USB at 4.75–5.25 V. Triple-redundant power is possible when all three sources are supplied. The 0–10 V PWM output rails neither power the controller nor receive power from it, so servos require a separate supply. RCIN is reserved for receiver power and must not connect to another power source or load. The included CAN PMU SE module supports 3–14S lithium batteries and connects to Power C.
Specifications
| Specification | Value & conditions |
|---|---|
| Product identity and purpose | CUAV X7+ Flight Controller |
| Intended integration applications | Academic research and commercial systems integration |
| Main FMU processor | STM32H743 |
| Accelerometer/gyroscope, first listed set | ICM-42688-P (X7: BMI088)The parenthetical BMI088 identifies the X7 comparison sensor, rather than the X7+ sensor. |
| Accelerometer/gyroscope, second listed set | ICM-20689 |
| Accelerometer/gyroscope, third listed set | ICM-20689 (X7: ICM-20649)The parenthetical ICM-20649 identifies the X7 comparison sensor, rather than the X7+ sensor. |
| Magnetometer | RM3100 |
| Barometers | MS5611 × 2 |
| Controller power input | 4.5–5.4 VThe normal-operation section applies this range to POWERA and POWERC inputs. |
| USB input voltage | 4.75–5.25 VApplies to the USB power input. |
| Servo rail input | 0–10 VPWM OUT rails neither power the controller nor receive power from it. |
| Weight | 101 g |
| Operating temperature | -20 to 85 °C |
| PWM outputs | 14 PWM outputs; 12 support DshotDshot support applies to 12 of the 14 PWM outputs. |
| RC inputs | SBUs/CPPM/DSM |
| RSSI input | Analogue/PWM RSSI input |
| GPS ports | 2The two connections are identified as the GPS and UART4 ports. |
| I2C buses | 6 busesFour interfaces are independent; two are integrated into the GPS and UART4 interfaces. |
| CAN ports | 2 |
| Power ports | 2Power A uses the common ADC interface; Power C uses the UAVCAN battery interface. |
| ADC input | 1 |
| USB ports | 1 |
| Physical architecture | Modular design with internal shock absorption and provision for a custom carrier board |
| IMU arrangement and heating | Three IMU sensor sets; IMU heating support |
| Temperature compensation | Temperature compensation supported |
| Firmware | ArduPilot 4.1.0 or later; PX4 v1.12.3 or laterCompatibility is stated for ArduPilot 4.1.0 and PX4 v1.12.3 or later; the manufacturer recommends ArduPilot. |
| Power redundancy | Conditional triple-redundant power supplyTriple redundancy requires three supplied power sources connected through POWERA, POWERC and USB. |
| RCIN restriction | Receiver-power-only RCIN portRCIN is restricted to receiver power and must not be connected to another power source or load. |
| Controller and output-rail power separation | Separate controller supply requiredThe board requires power through POWERA, POWERC or USB, independently of the PWM output rails. |
| Debug connection and listed cable | DSU7 serial console and SWD interface; CUAV FTDI cable listedThe CUAV FTDI cable in the product list; confirm the selected supplied configuration. |
| Power module battery support | 3~14s lithium batteryFor the supplied CAN PMU SE connected to the flight controller's Power C interface. |
| GPS compatibility limitation | Ordinary GPS modules from other manufacturers may not be fully compatible.Applies to X7+. |
| Servo power | The controller does not supply servo power.The X7+ servo interface is isolated from the controller's internal power supply. |
| Safety switch connection | Connect the switch directly to GPS1.Required to arm and fly when operating without GPS. |
| Ethernet access | Serial-port connectionUsing PPP, a PPP-to-Ethernet adapter or a custom firmware build |
Request a quote for CUAV X7+ Flight Controller
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.