Product overview
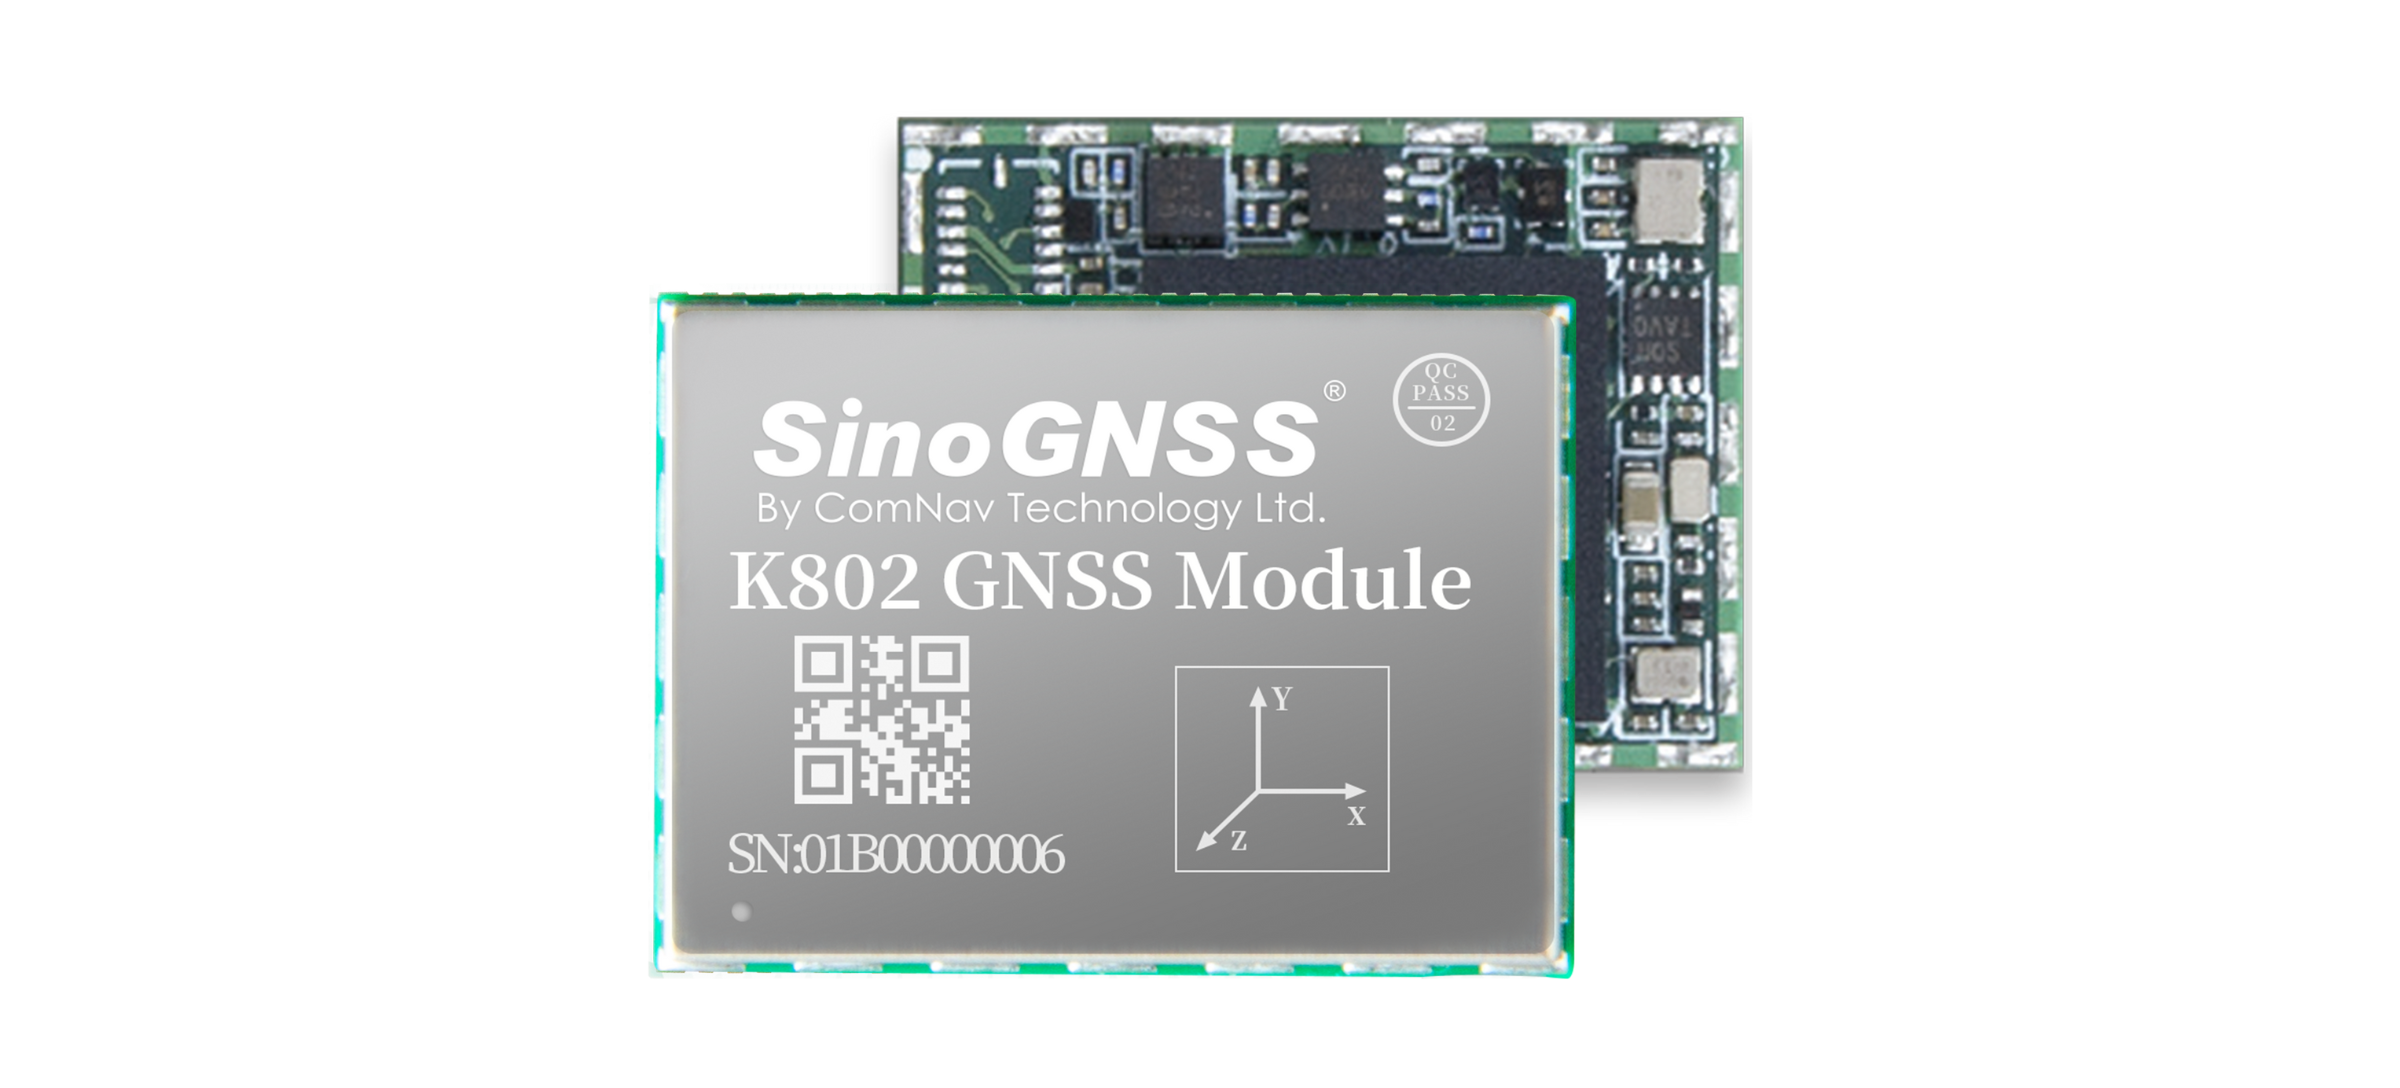
The ComNav K802 is presented as an automotive positioning component for integration into equipment with limited internal space. Its surface-mounted architecture combines multi-frequency satellite reception with a built-in IMU, supporting GNSS and inertial navigation in one module. The published package dimensions are 22mm × 17mm × 2.8mm, with a weight of 5 g.
Integration provisions include three UART ports, SPI, I2C, an event-marker input and a PPS output, alongside several position-data and correction formats. Electrical planning must account for the +3.3 V ± 5% DC supply and anti-interference setting: published consumption is 0.8W with that function off, increasing by approximately 0.2W when enabled. Accuracy figures depend on positioning mode, startup figures carry configuration conditions, and 100Hz output is optional. The claimed centimeter-level inertial continuity covers the first 3s after GNSS loss. Conflicting AEC-Q100 and AEC-Q104 statements require clarification.
Specifications
| Specification | Value & conditions |
|---|---|
| Product purpose and architecture | ComNav K802: multi-frequency GNSS module with a built-in IMU and compact surface-mounted architecture.Designed for automotive integration; a GNSS module rather than a flight platform or airframe kit. |
| Satellite signals tracked |
|
| Startup times | Cold start: less than 20s; hot start: less than 10s.Cold start requires the added Acceleration Capture Module; hot start is a typical value with RTC. |
| Reacquisition | Less than 1s. |
| RTK initialization time | Less than 5s.Baseline less than 10km. |
| Initialization reliability | Greater than 99.9%. |
| Velocity accuracy | ≤ 0.02 m/s.PDOP ≤ 4. |
| Acceleration | 4 g. |
| Time accuracy | 20ns. |
| Overload | 15g. |
| Single-baseline RTK accuracy | Horizontal: 8 mm + 1 ppm; vertical: 15 mm + 1 ppm.Single-baseline RTK mode. |
| Post-processing accuracy | Horizontal: 2.5 mm + 1 ppm; vertical: 5 mm + 1 ppm.Post-processing mode. |
| DGPS accuracy | Less than 0.4 m RMS.DGPS mode; RMS measurement. |
| SBAS accuracy | 1 m 3D RMS.SBAS mode; 3D RMS measurement. |
| Standalone accuracy | 1.5m 3D RMS.Standalone mode; 3D RMS measurement. |
| Module dimensions | 22mm × 17mm × 2.8mm.Dimensions are expressed as length × width × height. |
| Weight | 5 g. |
| Power consumption | 0.8W with anti-interference off; approximately 0.2W additional consumption with anti-interference on.0.8W applies with anti-interference off; enabling it adds approximately 0.2W. |
| Input voltage | +3.3 V ± 5% DC.DC supply with the published ± 5% tolerance. |
| Temperature ranges | Operating: -40 °C to +85 °C; storage: -55 °C to +95 °C.Operating and storage ranges are separately specified. |
| LNA power | External: +3.3V to +5V ± 5% VDC.External LNA power; a ± 5% tolerance. |
| LNA gain | 20–40dB. |
| Impedance matching | 50 Ohm. |
| Communication and timing interfaces | 3 UART ports; 1 SPI; 1 event-marker input; 1 pulse-per-second output; 1 I2C. |
| Position data formats | ASCII NMEA-0183: GGA, GSA, GSV, RMC, HDT, ZDA, VTG, GST, GLL; PTNL, PJK; PTNL, AVR; PTNL, GGK. ComNav Binary. BINEX: 0x00, 0x01-01, 0x01-02, 0x01-05, 0x7d-00, 0x7e-00, 0x7f-05. |
| Position data output rates | 1 Hz, 2 Hz, 5 Hz, 10 Hz, 20Hz, 50Hz; optional 100Hz.100Hz is optional. |
| Correction data formats | RTCM 2.X and 3.X; CMR and CMR+ for GPS only.CMR and CMR+ apply to GPS only. |
| GNSS and inertial positioning | Combined GNSS/INS positioning; claimed centimeter-level accuracy within 3s after losing GNSS signal.Manufacturer claim applies within 3s after GNSS signal loss. |
| Positioning algorithm | ComNav Quantum RTK algorithm. |
| Automotive qualification statements | The feature list states AEC-Q100; the automotive-grade description states AEC-Q104.Conflicting certification identifiers; confirm the applicable qualification documentation. |
Request a quote for ComNav K802 GNSS Module
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.