Product overview
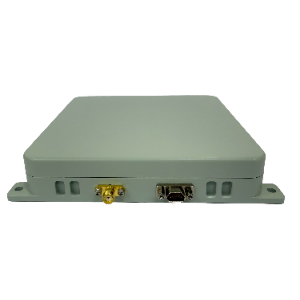
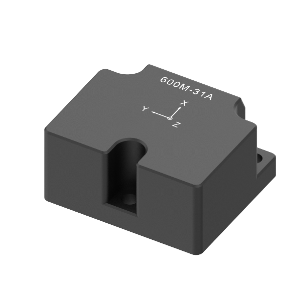
The BWSENSING IMU400C is a packaged inertial measurement unit for applications including unmanned aircraft, robotics and platform stabilization. Its sensing architecture combines gyroscope measurements with acceleration measurements on the X, Y and Z axes. The enclosure measures 60 mm long, 59 mm wide and 29 mm high, defining the space occupied by the packaged unit within a host assembly. Output interface choices are RS232, RS485 or TTL, with sampling available at up to 500 Hz.
The unit provides dynamic, orthogonality and temperature compensation, with a temperature range of -40 °C to +85 °C. Its gyroscope measures angular rates within ±400°/sec, while the accelerometer covers ±3.6 g on each axis. Bias stability depends on the stated measurement conditions: gyroscope figures distinguish room-temperature and full-temperature operation, and accelerometer figures apply at 25 °C. Both sensors have separate stability values for 100-second and 10-second intervals, so those timing qualifications matter when comparing specifications.
Specifications
| Specification | Value & conditions |
|---|---|
| Product | BWSENSING IMU400C high-performance inertial measurement unit |
| Compensation | Dynamic compensation and orthogonality compensation |
| Sampling frequency | Up to 500 Hz |
| Output interface options | RS232 / RS485 / TTLSelectable output interface. |
| Temperature range | -40 °C to +85 °CWith temperature compensation. |
| Dimensions | L60 × W59 × H29 mmPackaged product; length × width × height. |
| Gyroscope resolution | 0.01°/sec |
| Gyroscope measurement range | ±400°/sec |
| Gyroscope bias stability at 100 s | Less than 0.5 °/hRoom temperature; 100 s, 1σ. |
| Gyroscope bias stability at 10 s | Less than 10 °/hRoom temperature; 10 s, 1σ. |
| Gyroscope full-temperature bias stability | Less than 20 °/hFull temperature range; 10 s, 1σ. |
| Gyroscope angle random walk | Less than 0.1 °/√h |
| Gyroscope bias repeatability | Less than 50 °/h1σ. |
| Accelerometer measurement range | ±3.6 gX, Y and Z axes. |
| Accelerometer resolution | 0.01 mg |
| Accelerometer bias stability at 100 s | 0.001 mg25 °C; 100 s, 1σ. |
| Accelerometer bias stability at 10 s | 0.01 mg25 °C; 10 s, 1σ. |
| Application areas | Unmanned vessels, underwater robots, construction machinery, platform stabilization, automated guided vehicles, heavy trucks, autonomous driving, robotics and unmanned aircraft |
Request a quote for IMU400C
Send your application, destination country and expected quantity to the ChinaDrone team. We can discuss product selection, configuration and sourcing from China.
Submit your procurement requirements ↗No account needed. A model number is optional. Your enquiry is handled by ChinaDrone.